58
● exposure_value_enum(enum):
■ rm_define.exposure_value_large
■ rm_define.exposure_value_medium
■ rm_define.exposure_value_small
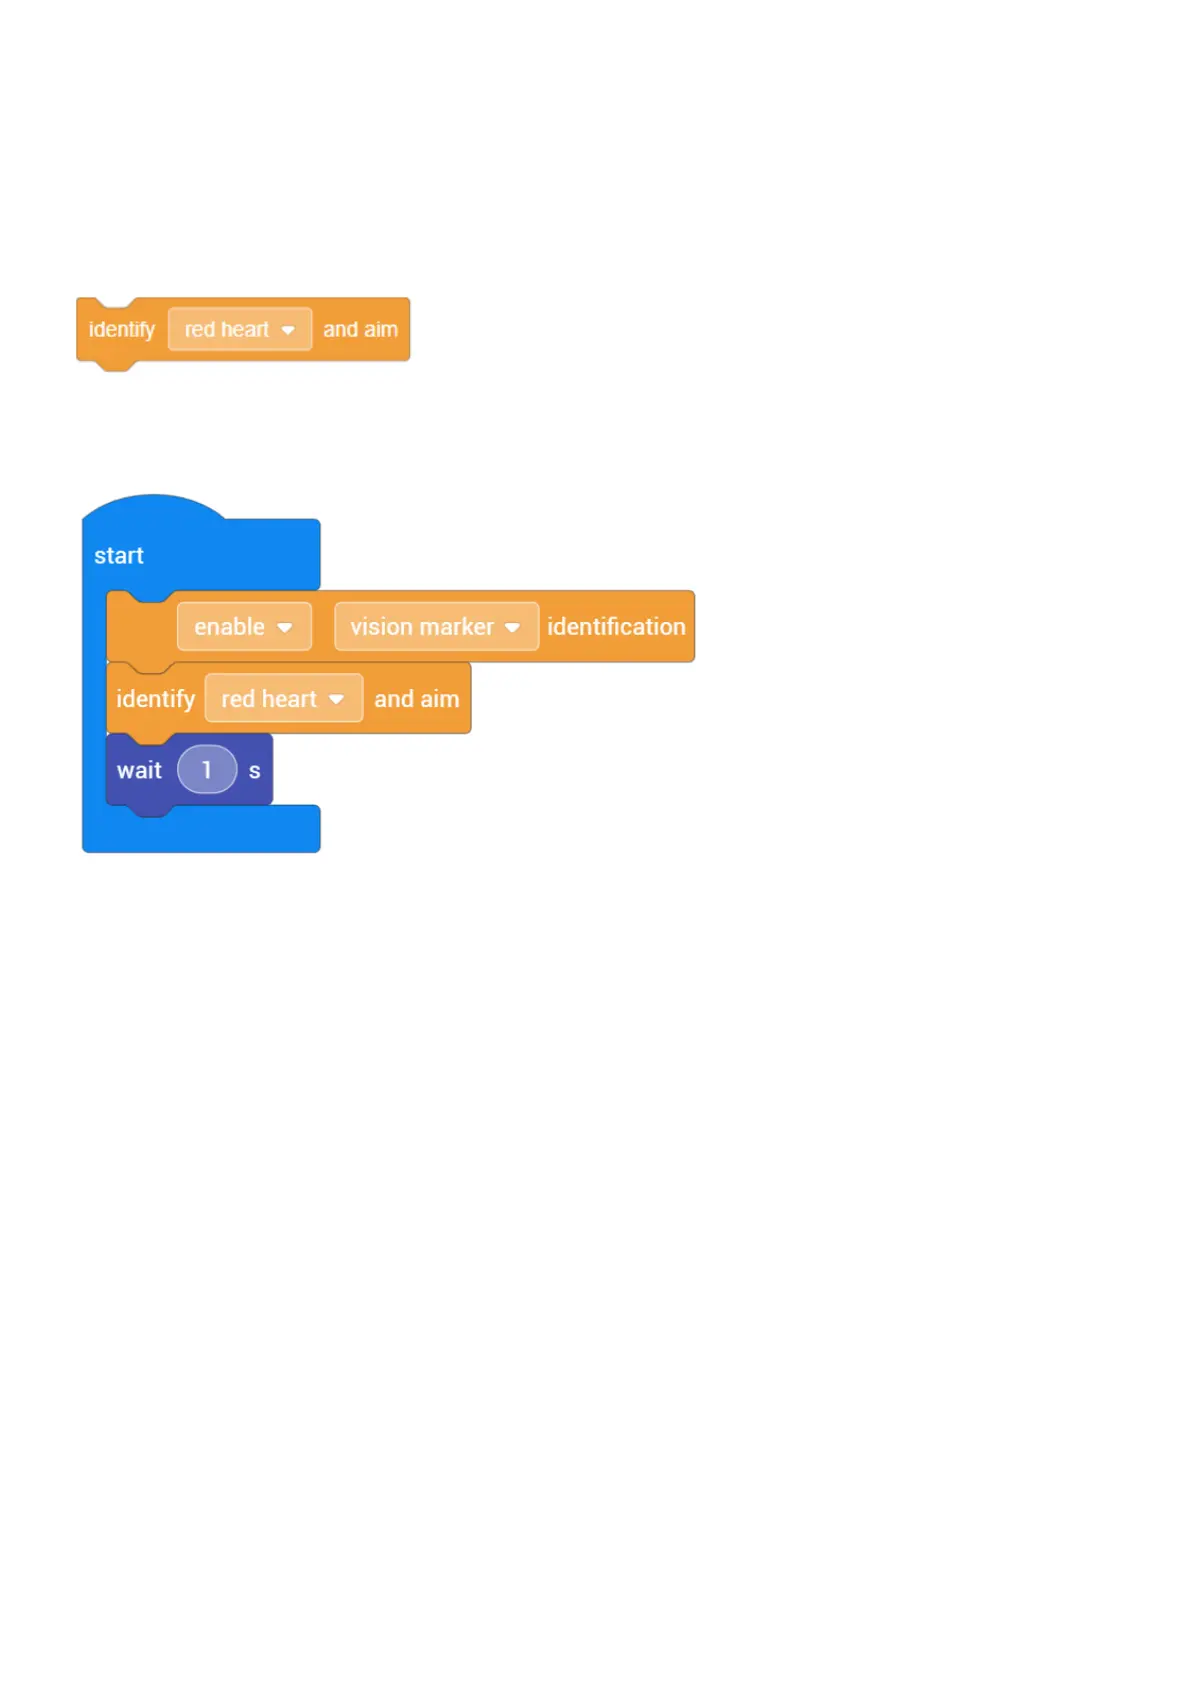
8. Identify (red heart) and aim
(1) Description: Set the robot to identify and aim at the central position of the corresponding Vision Markers
(2) Type: Execution block
(3) Example: Set robot to aim at the red heart
Notes:
1. You must enable Vision Marker identification for the robot to be able to identify Vision Markers.
2. In this block, when the robot identifies a red heart, it will automatically aim toward it; if the robot fails to identify the
red heart within 5 seconds, it will exit the program and run the next program.
Python API:
Function: vision_ctrl.detect_marker_and_aim(marker_enum)
Parameters:
● rm_define.marker_trans_red_heart
● rm_define.marker_trans_target
● rm_define.marker_trans_dice
● rm_define.marker_number_[zero,..., nine]
● rm_define.marker_letter_[A,..., Z]


 To Next Page