Hospitex Diagnostics EOS Bravo and EOS Bravo Plus Service Manual
67
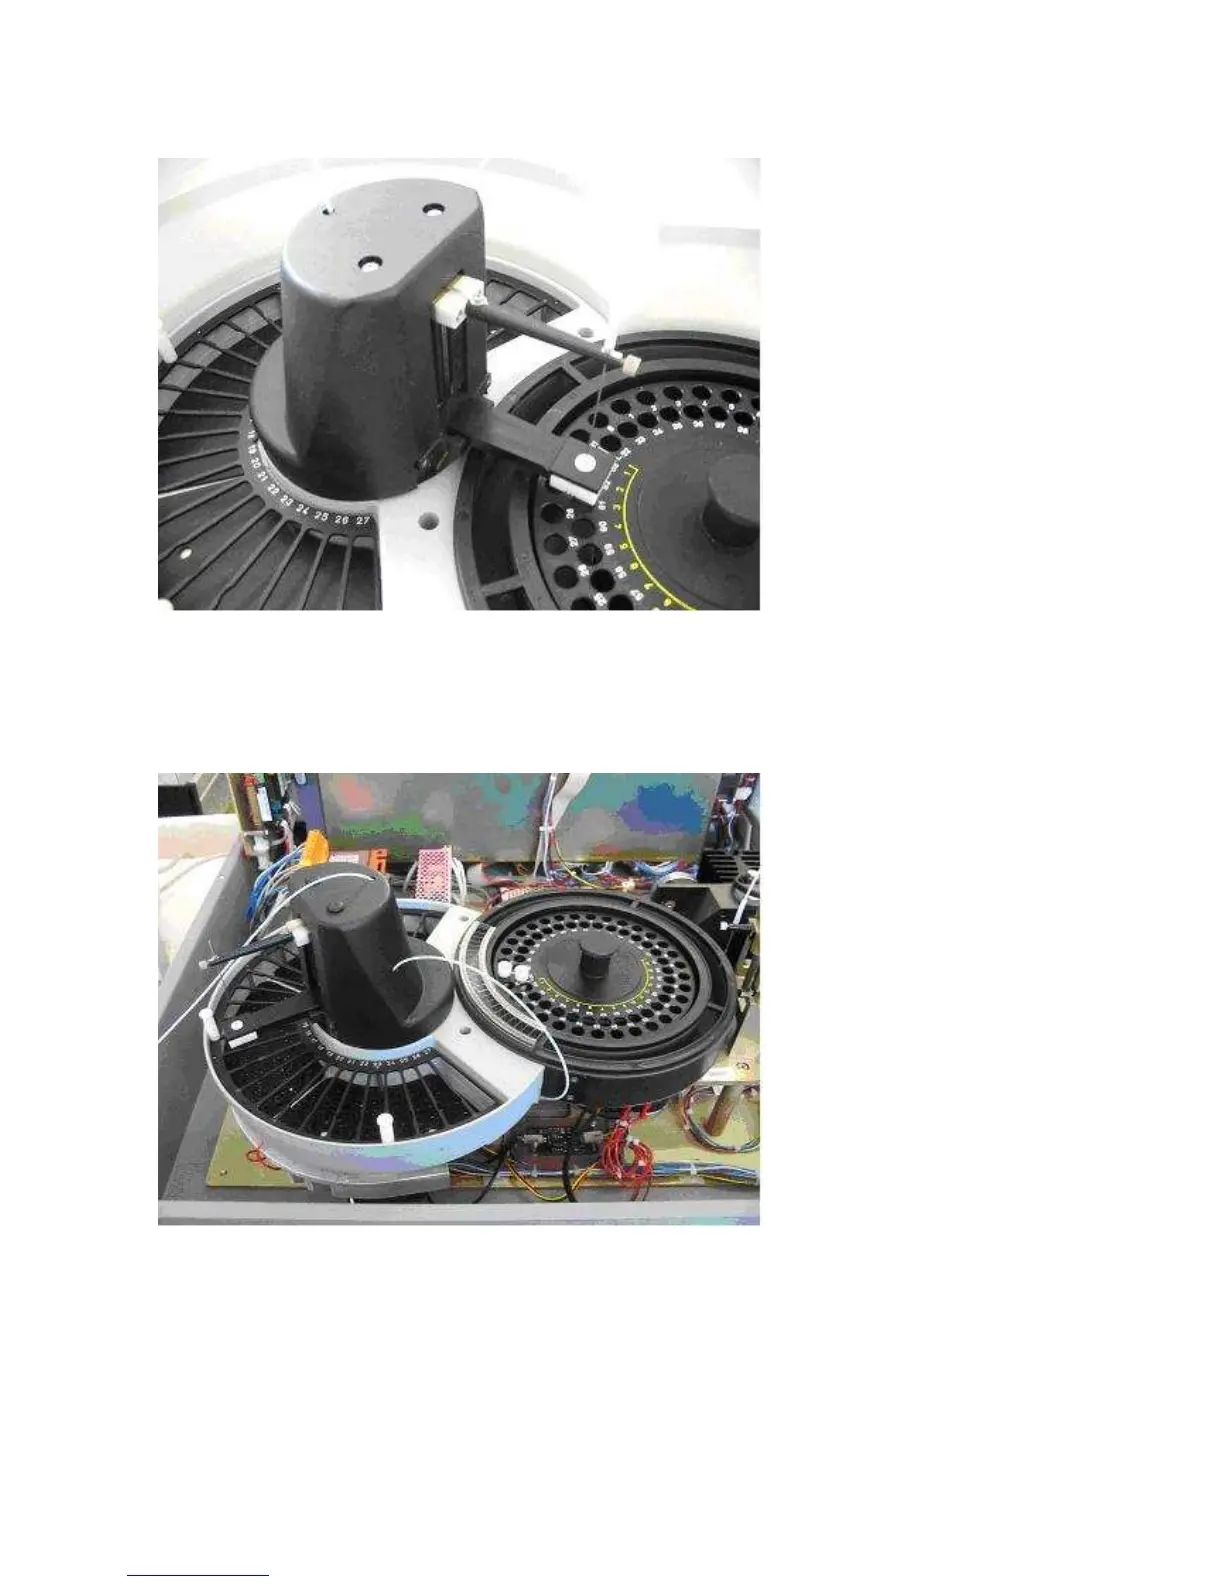
Figure 1: Sampling Needle Arm
The sampling needle arm movement and position is controlled by a stepper motor driver (U12)
located onboard to the Power board that drives the stepper motor model 103-546-5342 and an
optical sensor barrel that informs when the arm is at home position.
The movement from the motor to the arm is transferred by a mechanism driven from a belt and two
pulleys.
Figure 2: Reagent Plate Arm
The Reagent plate movement and position is controlled by a stepper motor driver (U11) located
onboard to the Power board that drives the stepper motor model 23L-C304-76W and an optical
sensor barrel that informs when the arm is at home position.
The movement from the motor to the arm is transferred by a mechanism driven from a belt and two
pulleys.



 To Next Page