Handy-Dandy
End Eectors
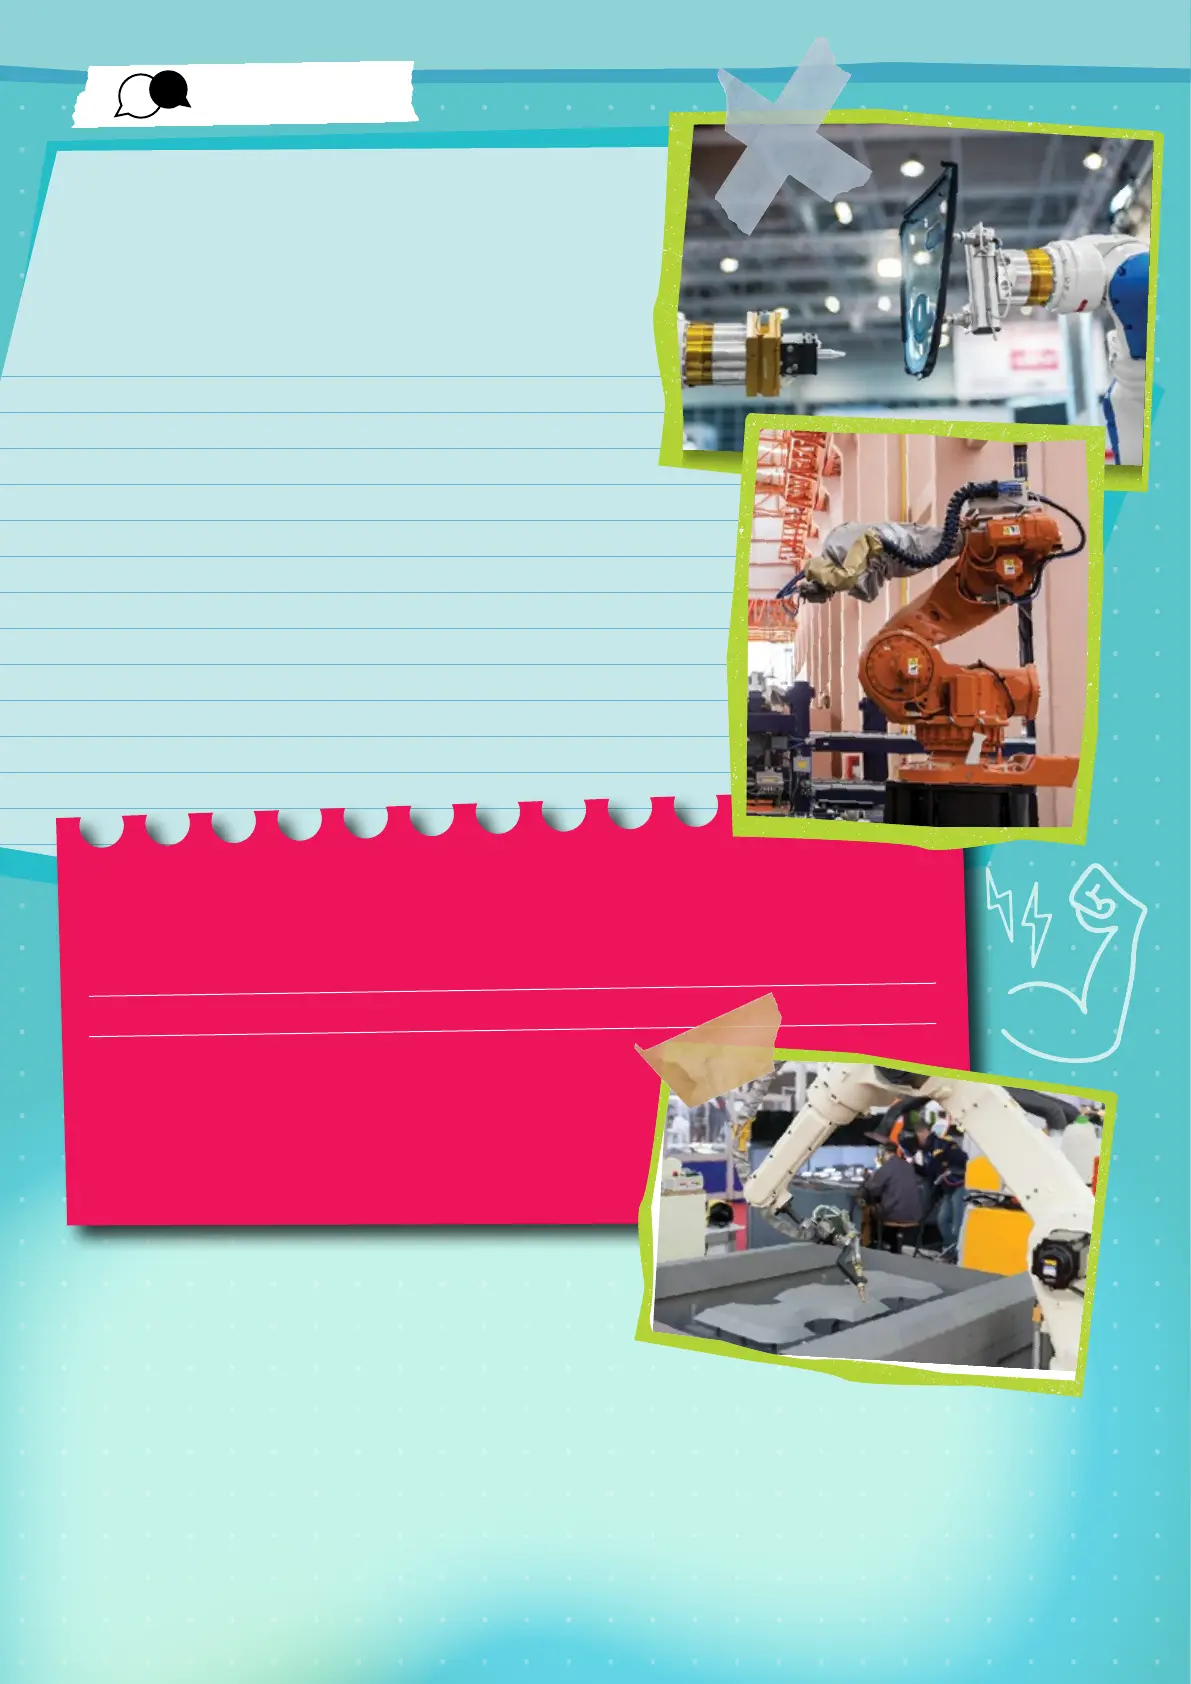
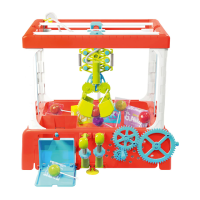
The device at the end of a robotic arm is
called the end effector. You can think of it
like a human hand, but the variety of
different end effectors and their capabilities
goes far beyond what a human hand can do
on its own. In this kit, there are three
interchangeable end effectors: scoop, three-point
gripper, and two-point gripper. They are all good
at picking up different objects. End effectors are
designed to interact with and manipulate objects
in their environments to perform
specialized tasks.
What can e effecto do?
There are two main categories of end effectors: grippers and tools.
Here are examples of each.
Grippers Tools
Mechanical (fingers) Welding torch
Suction, vacuum Spray painting
Magnetic Measuring, sensing
Adhesive Drilling, cutting
Degrees of Freedom
Unlike a human arm, a robotic arm has a lot more
freedom to move through space in different ways.
The term “degrees of freedom” is used to describe
the movement of a robotic arm through space. The position and orientation of
an object in space is described by three coordinates in the x, y, and z directions, and three
directions of rotation around those axes.
The area dened by all of the positions in space that the end of the robotic arm can reach is known
as the workspace. If the object that the robotic arm needs to pick up is not in the workspace, the
robot cannot pick it up! The workspace depends on the degrees of freedom, limitations of the
joints, lengths of the linkages, and the angles at which the object must be picked up.
16
?
!
CHECK IT OUT



 To Next Page