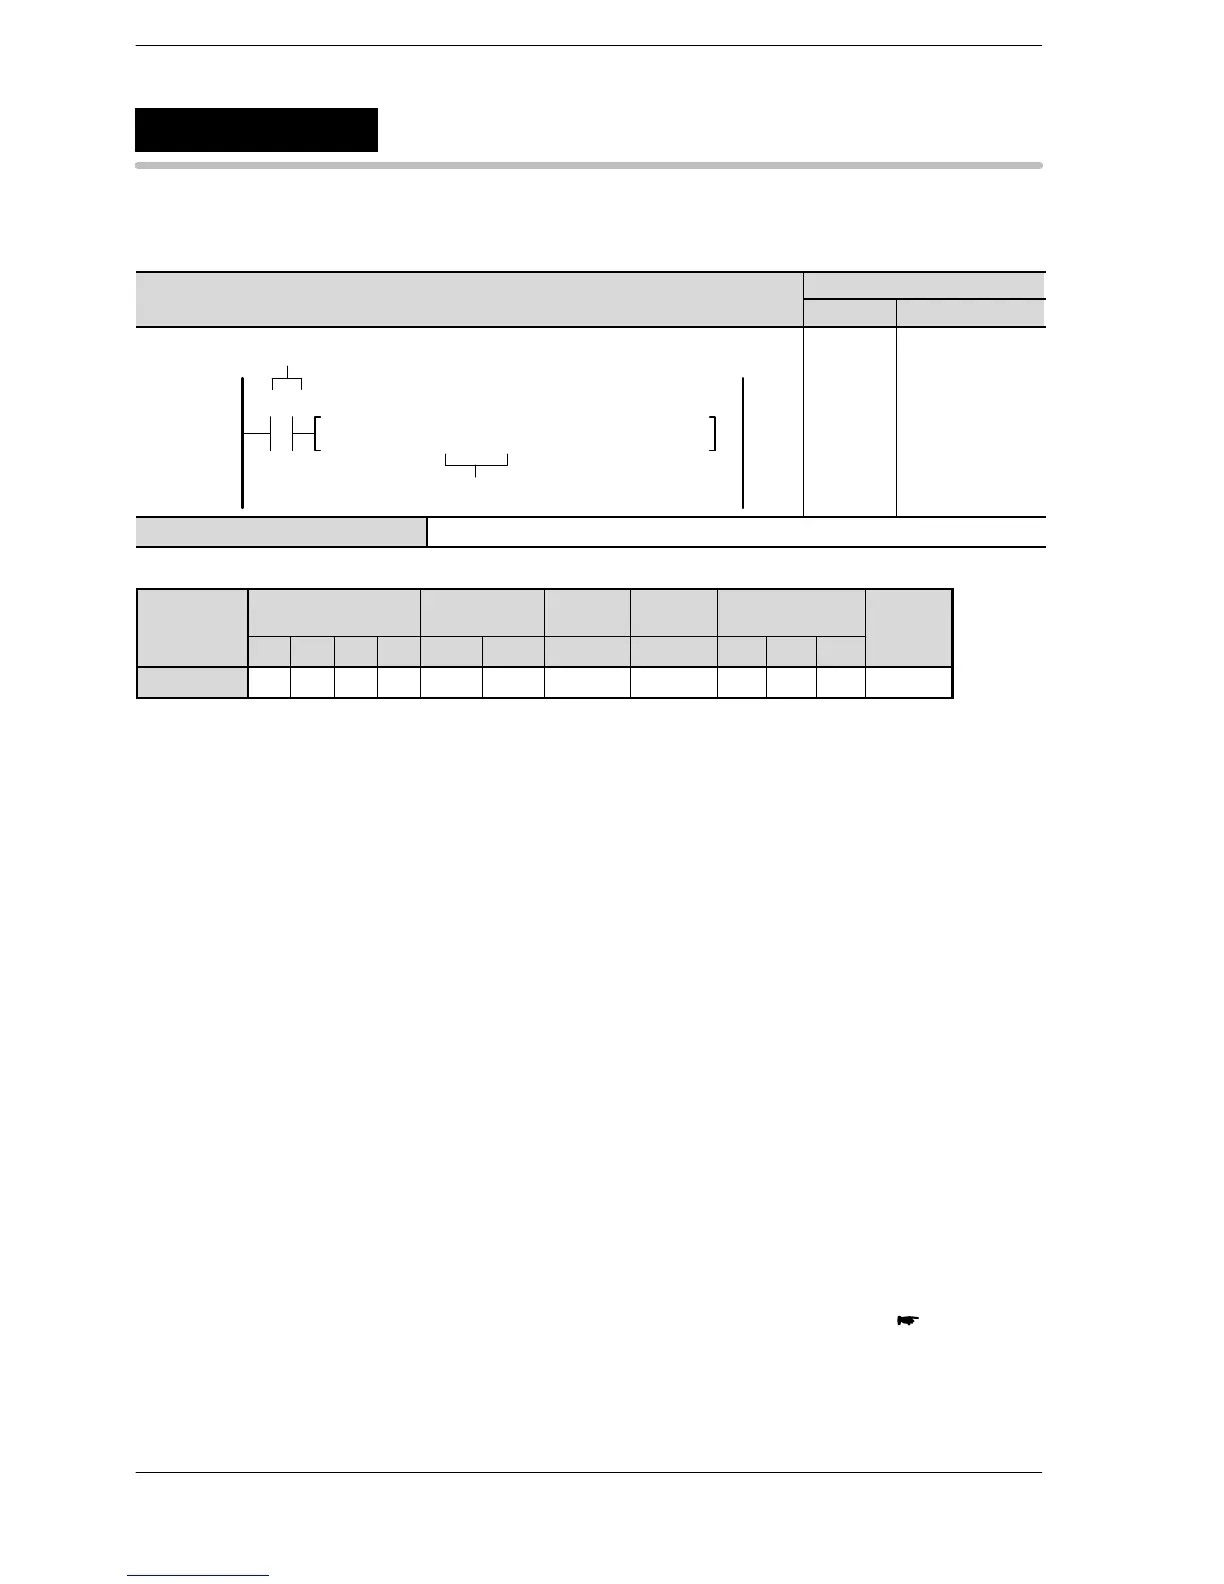
WX WY WR WL SV EV DT I K H f
modifier
S N/A N/A N/A N/A N/A N/A A N/A N/A N/A N/A N/A
Description
PID processing is performed to hold the measured value specified by S+2 at the set value S+1, and the result
is output to S+3.
Derivative control or proportional−derivative control can be selected for the PID processing mode.
Set the PID processing coefficients (proportional gain, integral time and derivative time) and the processing
mode and cycle in the parameter table. PID processing will be performed based on these settings.
Types of PID processing
Reverse operation and forward operation
When a process has been changed, the vertical direction of the output can be selected.
If the measured value drops, “Reverse operation” is specified to boost the output (heating, etc.).
If the measured value increases, “Forward operation” is specified to boost the output (cooling, etc.).
Derivative type (PI−D) / Proportional−derivative type (I−PD)
Generally, with “derivative PID control”, when a set value is changed, there is increased fluctuation in the
output, but convergence is faster.
Generally, with “proportional−derivative PID control”, when a set value is changed, there is less fluctuation in
the output, but convergence is slower.
next page
PID processing
5
F355
(PID)
A: Available
N/A: Not Available












 To Next Page