Tecomat TC600
TXV 138 08.02 80
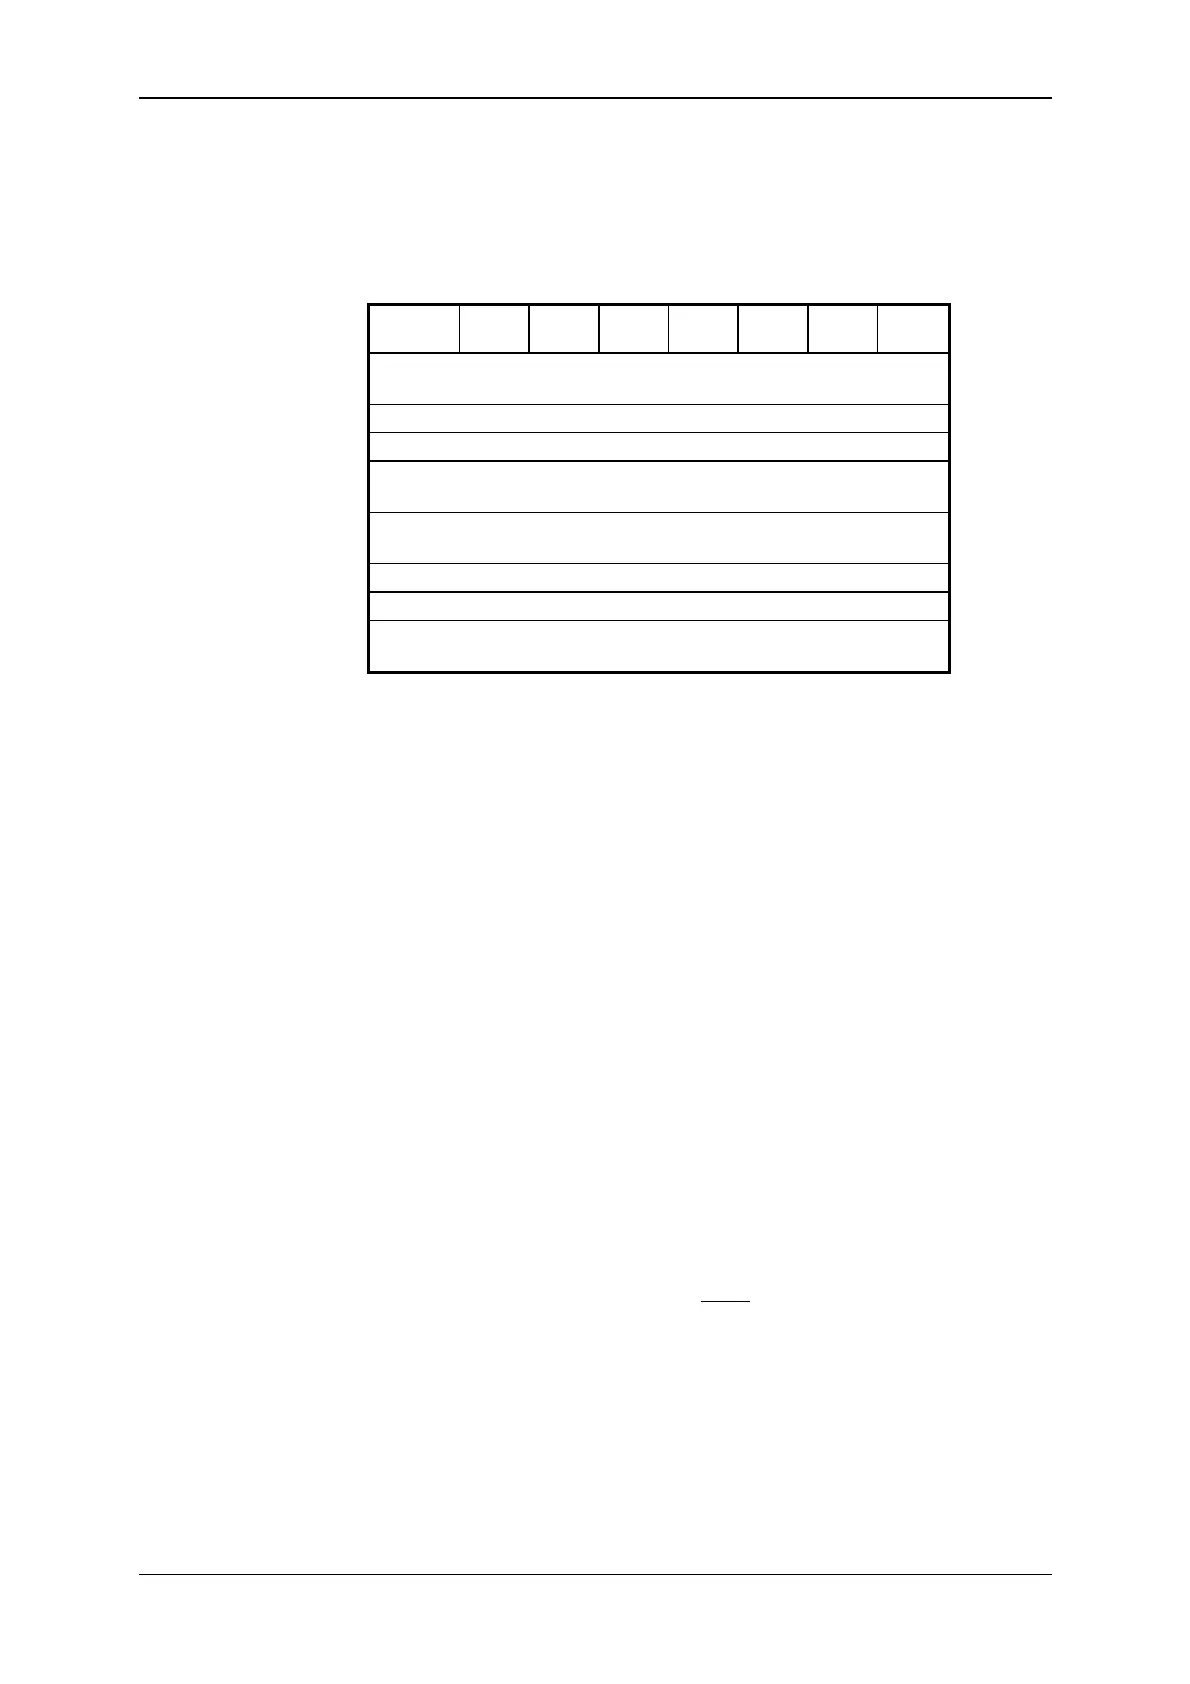
Image of outputs contains the CONT control word, pre-selection of the
admeasured value for the ascending direction, and pre-selection of the ad-
measured value for the descending direction. State of bits CONT.6 and
CONT.7 is accepted immediately after their writing to the scratchpad, state
of other bits in CONT as well as of the pre-selections is accepted in the cy-
cle loop, or upon termination of the P44 interrupt process, respectively.
CONT
.7
CONT
.6
----
CONT
.1
CONT
.0
Z_OUT
Least significant byte of pre-selection for the ascending direc-
tion
Z_OUT+1
Most significant byte of pre-selection for the ascending direc-
tion
Z_OUT+4
Least significant byte of pre-selection for the descending direc-
tion
Z_OUT+5
Most significant byte of pre-selection for the descending direc-
tion
Z_OUT+8
CONT.0 - mode of the reference point look up
Change of state of the bit from 0 to 1 evokes request for look
up of the reference point (zero pulse). Setting of the bit to
zero is done by the user. During look up of the reference
point, the STAT.5 is set. The first zero pulse after accepting
of the request, causes setting to zero of the admeasured
value and the STAT.5 bit.
CONT.1 - admeasurement reset
Change of state of the bit from 0 to 1 evokes setting to zero
of the admeasured value. During state 1, admeasurement is
not reset.
CONT.6 - allowing of interrupt from overflow or underflow of the ad-
measurement range
0 = interrupt prohibited
1 = interrupt allowed
CONT.7 - allowing of interrupt from reaching of one of the pre-selecti-
ons
0 = interrupt prohibited
1 = interrupt allowed
Pre-selections for both admeasurement directions may take arbitrary
combinations of positive as well as negative values. For determining of the
minimum difference of two pre-selection values following one after another,
the following relationship holds:
n
n - difference of two pre-selection values following one after another
f - frequency of the incremental encoder signal (given by division of
incremental encoder and the movement speed)
In servicing in the P44 process, it holds that the time of the interrupt pro-
cess must not exceed 5 ms. It is also necessary to keep in mind that evok-
ing of interrupt processes causes prolongation of the program cycle time,
which may even lead to exceeding of the maximum allowed cycle time.
Image of outputs
The control word
Pre-selection of the
admeasured value
Servicing in the P44
process


 To Next Page