12EN
Name Functional Description
TrueMapping
By utilizing the principle of triangulation, which involves emitting
and receiving laser beams reected by surrounding objects,
precise distance measurement information between the DEEBOT
and nearby objects can be calculated through algorithms� When
the DEEBOT moves within a certain environment, the positions
of surrounding objects are determined to create a spatial map of
the DEEBOT's surroundings� The measurement range is 8 m�
TrueDetect 3D
Sensor
The TrueDetect 3D structured light sensor scans the object
with a line laser and collect images with a monocular camera,
and generates the three-dimensional coordinates of the object
through image algorithms to identify the size of the object� The
detection distance is 0�35 m�
Microphone
Vibrating the diaphragm through air by human voice, it can
realize Voice Recording and ask DEEBOT to complete the
assigned work by Voice Control� Effective wake of 8 m�
Anti-drop Sensor
With Infrared Ranging-detecting the distance between the
bottom of DEEBOT and ground by Infrared Sensor at the
bottom, DEEBOT will not move forward when there are stairs in
front or the identied distance exceeds the preset one, realizing
the Anti-drop� The trigger distance is 60 mm�
Carpet Detection
Sensor
The difference in energy of the ultrasonic echo signal on different
surfaces is used to identify the oor material and help DEEBOT
to adjust the cleaning strategy automatically� Drive frequency 290
kHZ�
Edge Sensor
By the principle of infrared ranging, the robot detects the
distance between itself and objects on its side� When there is
a wall or obstacle on the right side, the robot performs edge-
cleaning operations to avoid missing any spots and collisions�
Anti-collision
Sensor
When the transmitted signal is blocked by an obstacle, the signal
receiver will not be able to receive the signal� With this principle,
DEEBOT will avoid obstacles when colliding with them�
SENSORS NOTES BEFORE CLEANING
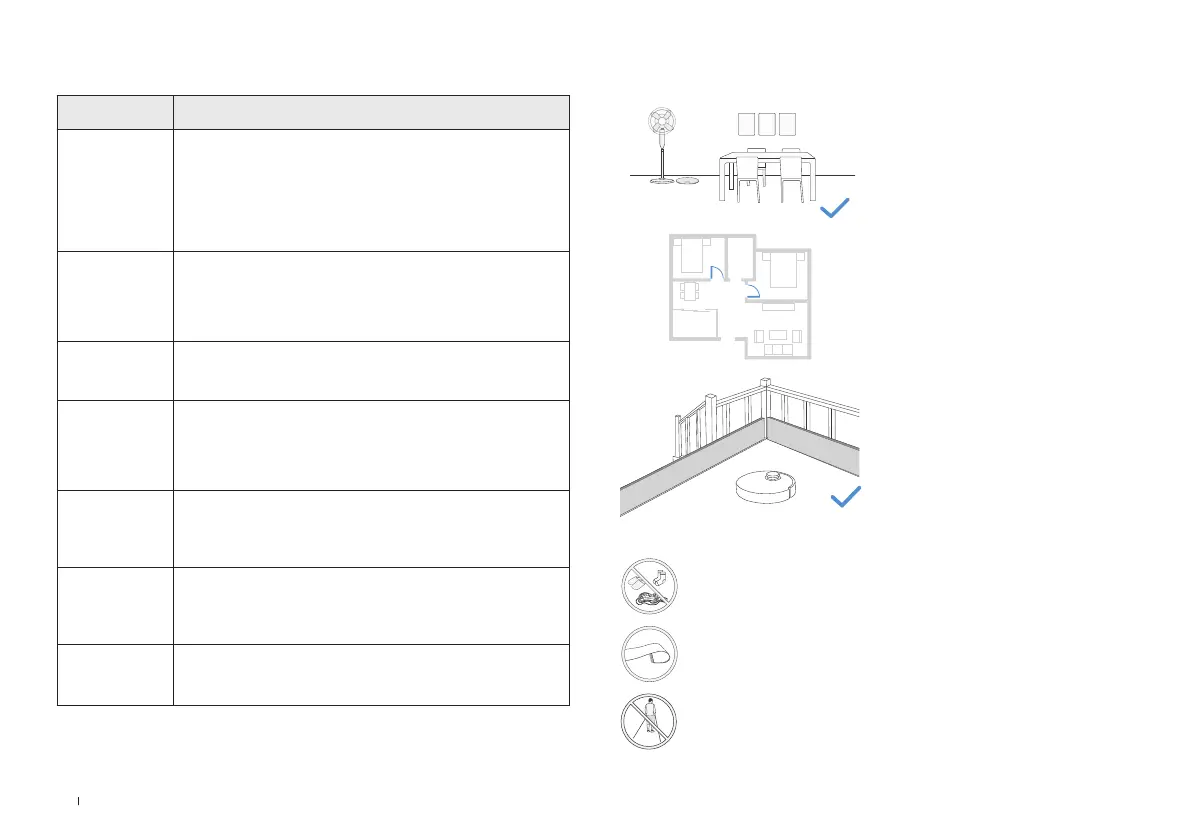
Put away objects including cables, clothes, slippers, etc� on the oor
to improve the cleaning efciency�
Before using the product on a rug with tasseled edges, please fold
the rug edges under�
Please do not stand in narrow spaces, such as hallways, and make
sure not to block the TrueMapping Distance Sensor�
Tidy up the area to be cleaned by putting
furniture, such as chairs, in their proper
place�
During the rst use, make sure each room
door is open to help DEEBOT fully explore
your house�
It may be necessary to place a physical
barrier at the edge of a drop to stop the
unit from falling over the edge�


 To Next Page