8 Chapter 1. Introduction
1.1.3 Fast servo
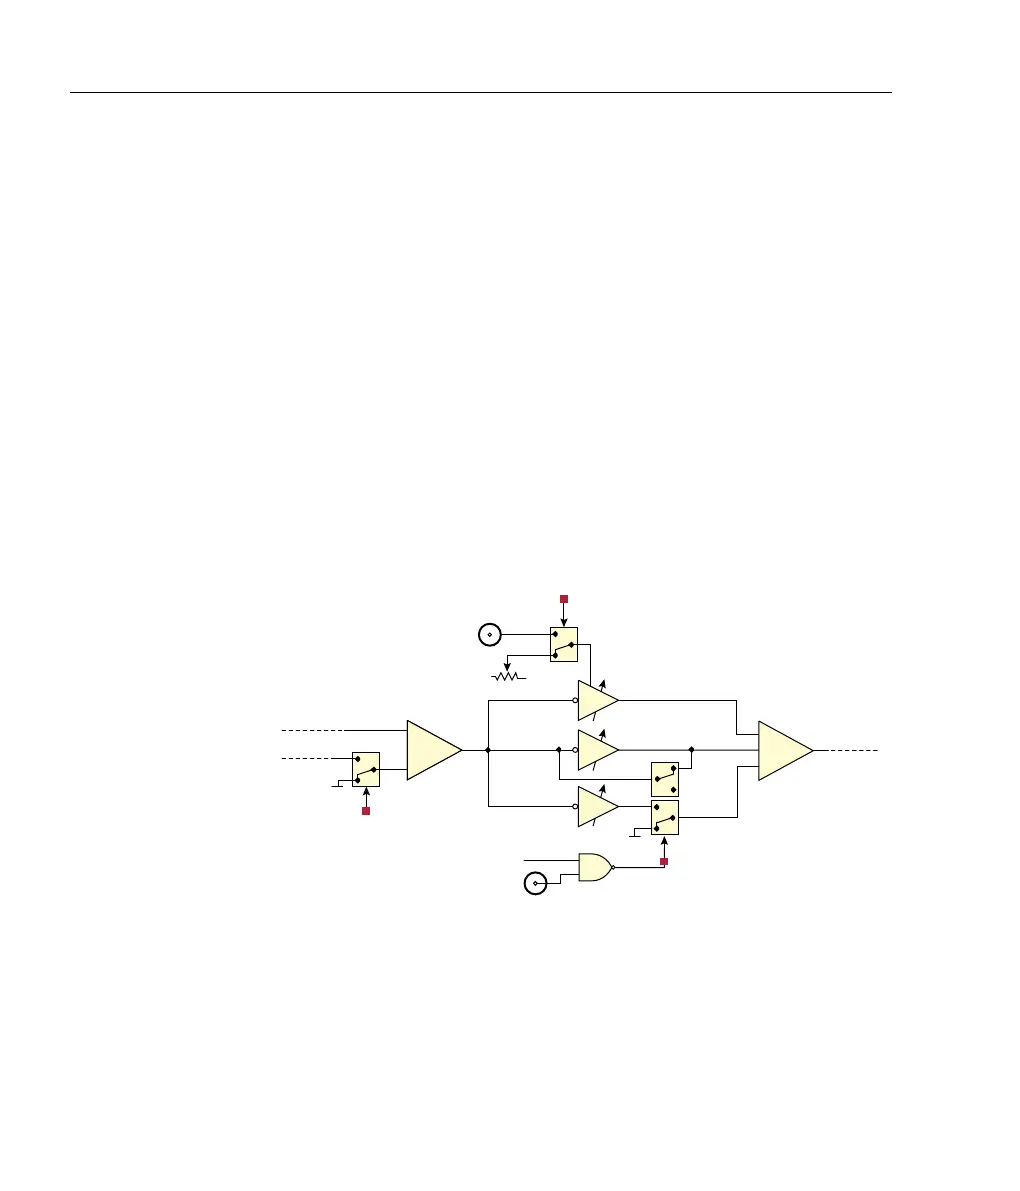
The fast feedback servo (figure 1.7) is a PID-loop with a variable
gain P-stage controlled with the front-panel FAST GAIN knob, or an
external control signal through the rear-panel GAIN IN connector.
The P, I and D components can be individually adjusted via front-
panel selector switches, and a low-frequency gain limit is applied
to prevent mode-hops caused by external perturbations.
The fast servo has three modes of operation: SCAN, SCAN+P and
LOCK. When set to SCAN, the feedback is disabled and only the bias
is applied to the fast output (if enabled). When set to SCAN+P,
the proportional feedback is applied, which allows for determination
of the fast servo sign and gain while the laser frequency is still
scanning, simplifying the locking and tuning procedure (see §3.2).
In LOCK mode, the scan is halted and full PID-controller is engaged.
External gain [1]
Fast error
FAST SERVO
FAST GAIN
P
I
D
NESTED
0v
+
Slow
control
Fast
control
GAIN IN
LOCK IN (FAST)
+
+
0v
FAST = LOCK
Figure 1.7: Schematic of fast feedback servo PID controller.
For applications that do not include a separate slow actuator, the
slow control signal (single or double integrated error) can be added
to the fast by setting the SLOW switch to “NESTED”. In this mode it
is recommended that the double-integrator in the slow channel be
disabled with DIP2 to prevent triple-integration.



 To Next Page