10EN
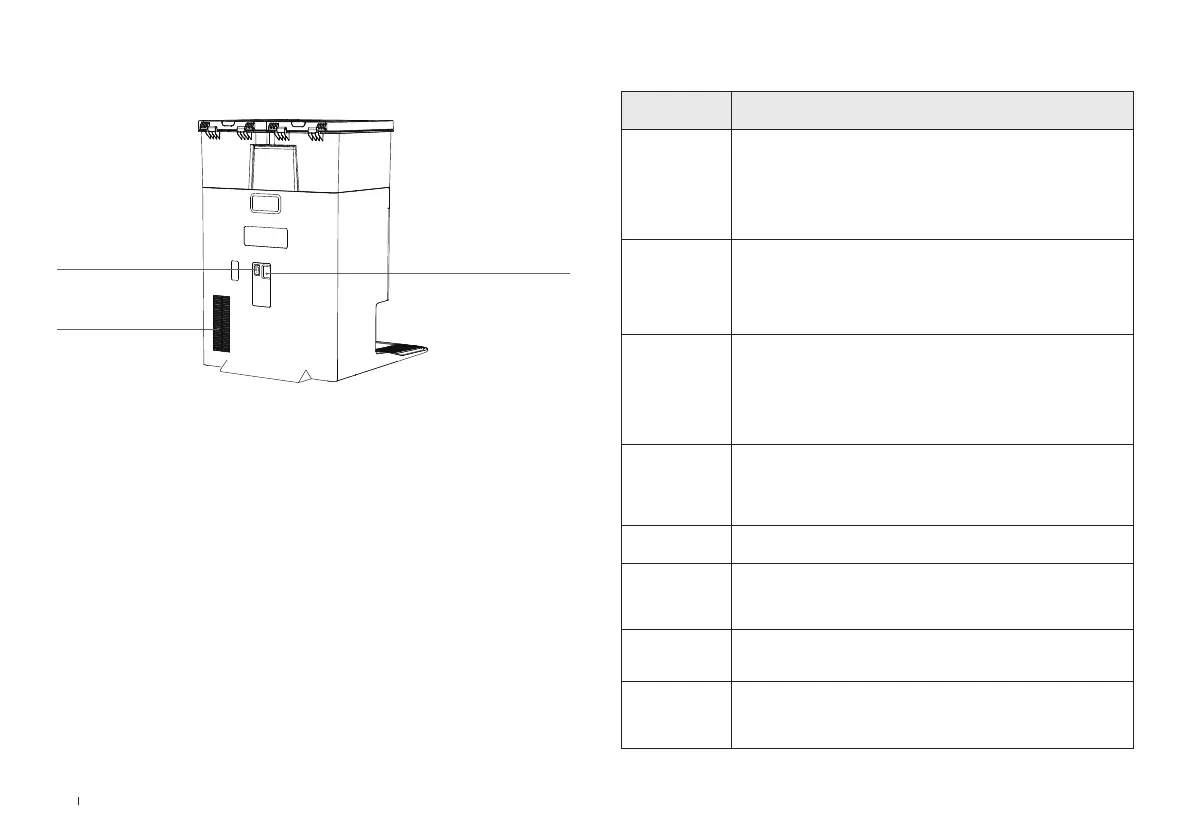
7. Station (Back)
Name Functional Description
d-ToF
LiDAR Module
Using the principle of laser ranging, the laser is emitted and reflected
by surrounding objects. d-ToF The time difference of incoming light is
used to calculate the distance between the host and surrounding objects
through an algorithm. LiDAR Module When the host walks in a certain
environment, it locates the positions of surrounding objects and draws
Output the spatial environment map of the host. The measurement range
is 10m.
TrueDetect 3D
Sensor
Using the infrared ranging principle, the sensor emits infrared rays and
receives the obstacles in front. TrueDetect 3D The reflected light is used
to calculate the distance between the obstacle and the host using similar
triangles. Power interface Structured light sensor When the sensor
detects an obstacle near the host, it automatically turns to avoid the
obstacle. Walking. The measuring range is 0.4m.
Anti-drop Sensor
Using the infrared ranging principle, the infrared sensor at the bottom
of the host monitors the host The height between the bottom and the
ground is high. When there is a downward step in front of the host (for
example: white ground Surface height greater than 55mm, black ground
height greater than 30mm) Sensor reading When the preset value is
exceeded, the host will no longer move forward, thus realizing the host
anti-fall function.
Carpet Detection
Sensor
The ultrasonic probe emits 300KHZ ultrasonic waves. When there is a
carpet, the ultrasonic Carpet Sensor The energy of the wave is absorbed
by the carpet, and the energy reflected back is less than the threshold,
and the host recognizes Identify more than 50 types of carpets on the
market in the Ecovacs Lab.
Anti-collision
Sensor
The anti-collision sensor uses the principle of optical coupling switch.
When a robot collides with an object, it will avoid the obstacle.
Edge Sensor
When there are walls or obstacles Detect the distance between the side
of the DEEBOT and the object when the right side,through the infrared
ranging principle The host performs edge motion to avoid missed scans
and collisions.
AIVI Camera
Use AI cameras to collect images of the surrounding environment and realize
video recording function. AI Camera Through interaction with MIC, remote
video call function is realized. FOV: vertical 77° Horizontal 97°.
Microphone
The human voice vibrates the diaphragm through the air, and the sound
model is collected and calculated. microphone Method to achieve sound
recording and voice control host to complete the specified work. The
awakening distance is within 5m.
8. Sensor Introduction
Air Vent
Power Socket
"I"=ON "O"=OFF
Power Switch


 To Next Page