EasyManua.ls Logo

OnRobot RG2-FT - Page 130

OnRobot RG2-FT
198 pages
Print Icon
To Next Page IconTo Next Page
To Previous Page IconTo Previous Page
Loading...
Hardware Specification
130
HEX-H QC
* Signal noise is defined as the standard deviation (1 σ) of a typical one second no-load signal.
Complex loading
During single-axis loading, the sensor can be operated up to its nominal capacity. Above the nominal
capacity the reading is inaccurate and invalid.
During complex loading (when more than one axis is loaded) the nominal capacities are reduced. The
following diagrams show the complex loading scenarios.
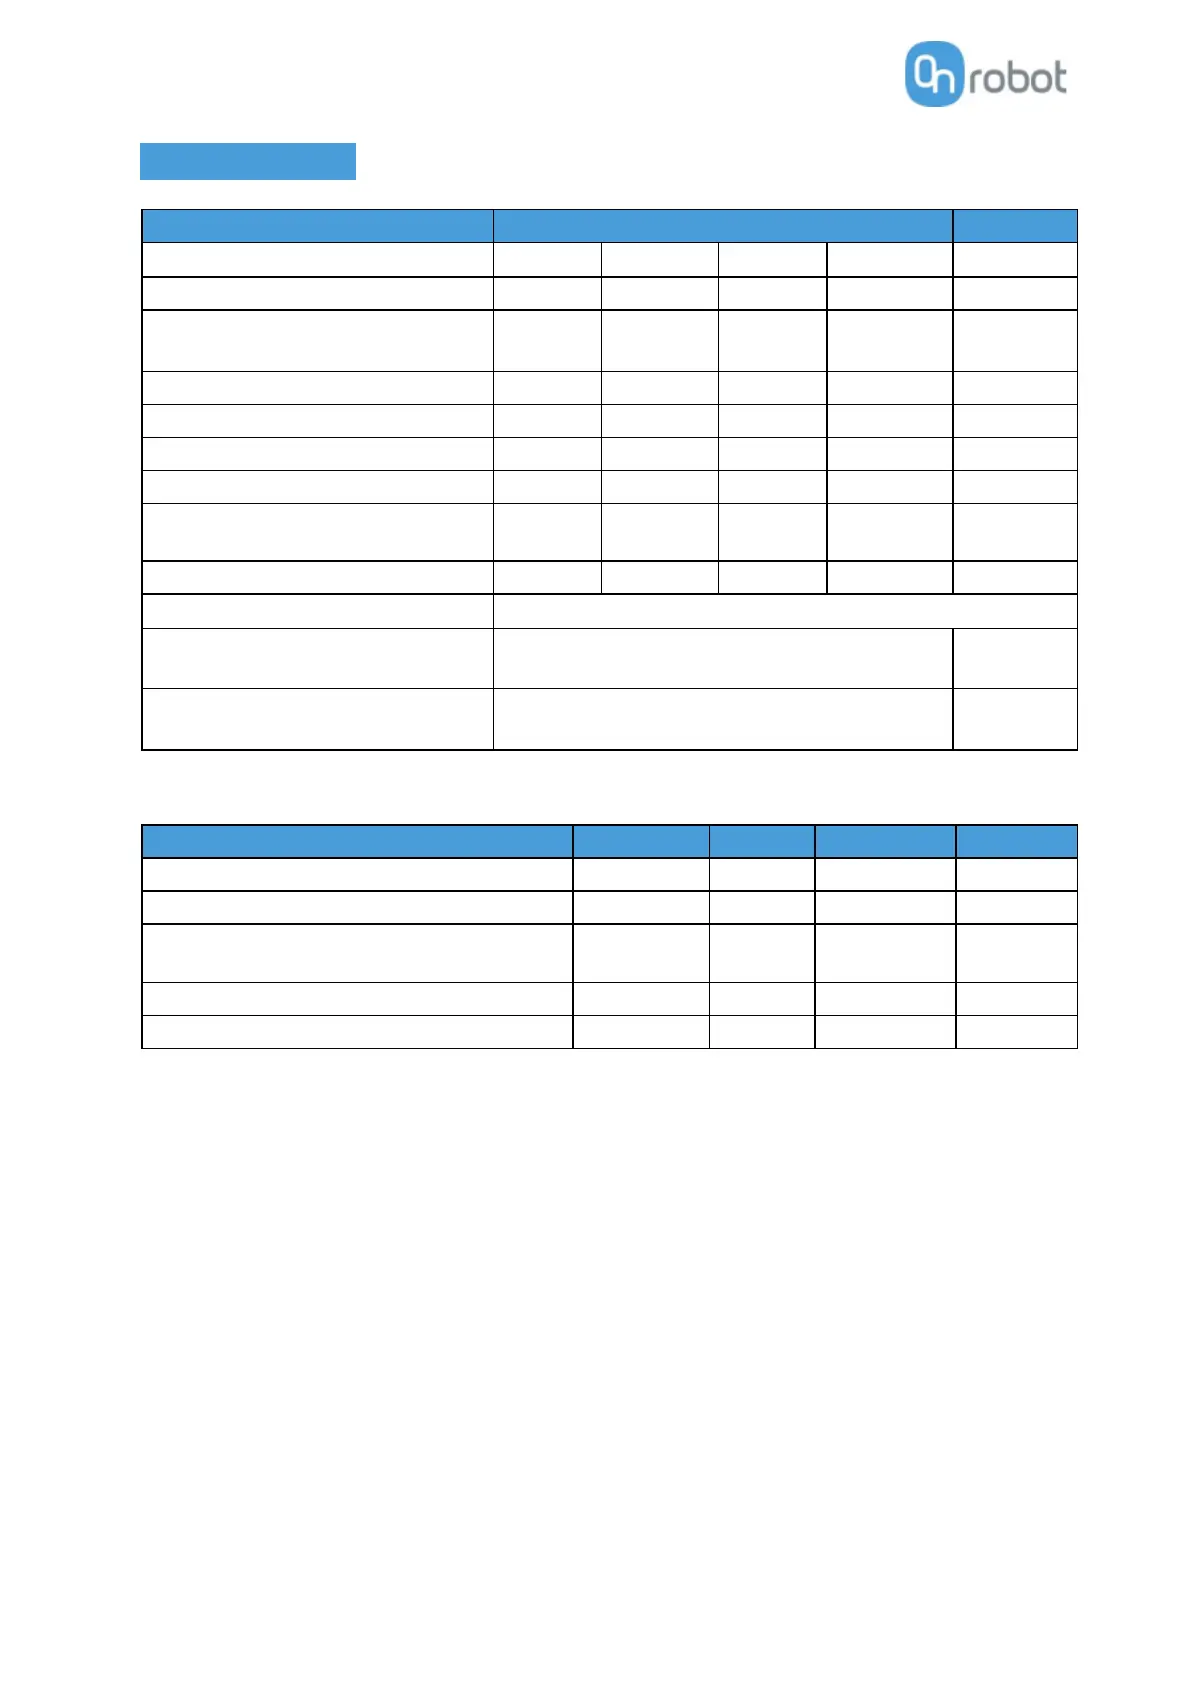
General Properties
6-Axis Force/Torque Sensor
Unit
Fxy
Fz
Txy
Tz
Nominal Capacity (N.C)
200
200
20
13
[N] [Nm]
Single axis deformation at N.C
(typical)
± 0.6
± 0.023
± 0.25
± 0.009
± 2
± 2
± 3.5
± 3.5
[mm] [°]
[inch] [°]
Single axis overload
500
400
300
300
[%]
Signal noise* (typical)
0.1
0.2
0.006
0.002
[N] [Nm]
Noise-free resolution (typical)
0.5
1
0.036
0.008
[N] [Nm]
Full scale nonlinearity
< 2
< 2
< 2
< 2
[%]
Hysteresis (measured on Fz axis ,
typical)
< 2
< 2
< 2
< 2
[%]
Crosstalk (typical)
< 5
< 5
< 5
< 5
[%]
IP Classification
67
Dimensions (H x W x L)
50 x 71 x 93
1.97 x 2.79 x 3.66
[mm]
[inch]
Weight (with built-in adapter plates)
0.35
0.77
[kg]
[lb]
Operating Conditions
Minimum
Typical
Maximum
Unit
Power supply
7
-
24
[V]
Power consumption
-
-
0.8
[W]
Operating temperature
0
32
-
-
55
131
[°C]
[°F]
Relative humidity (non-condensing)
0
-
95
[%]
Calculated MTBF (operating life)
30.000
-
-
[Hours]