EasyManua.ls Logo

OnRobot RG2-FT - Page 133

OnRobot RG2-FT
198 pages
Print Icon
To Next Page IconTo Next Page
To Previous Page IconTo Previous Page
Loading...
Hardware Specification
133
RG2-FT
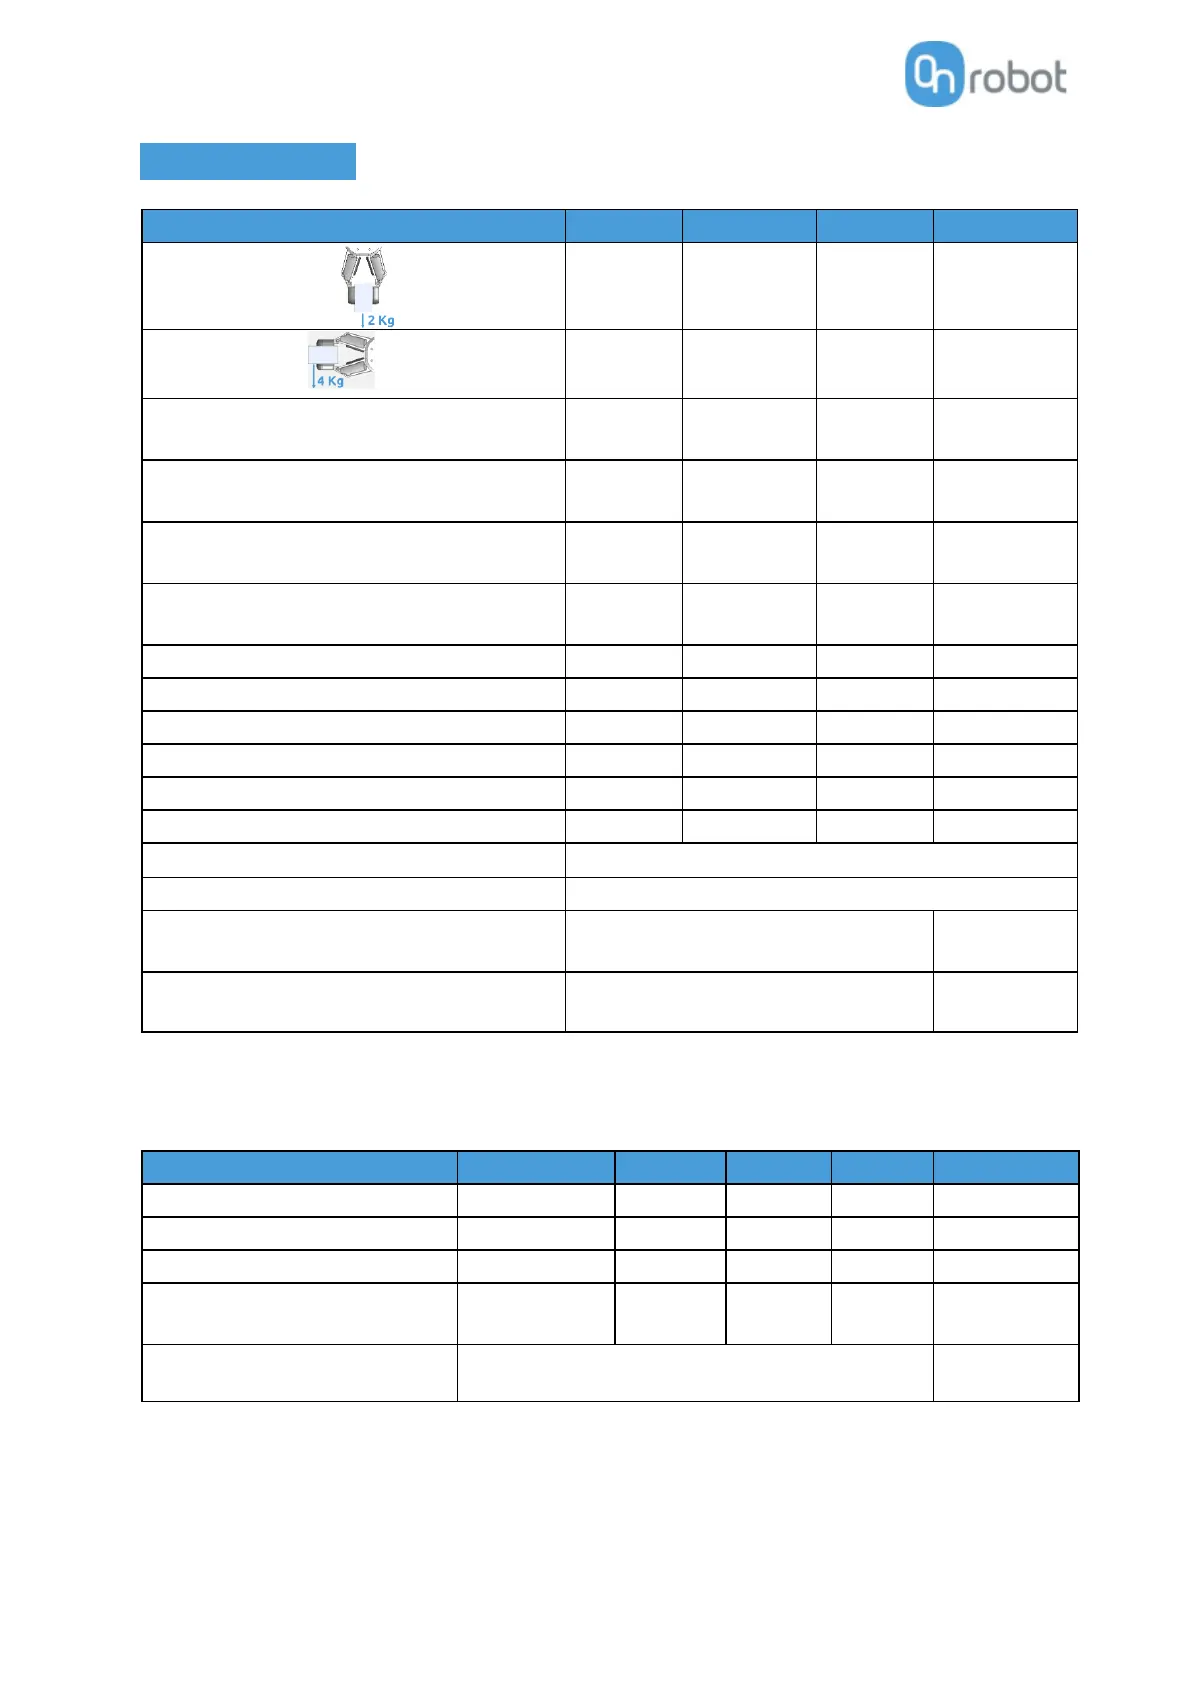
* see speed table 133
** based on 8mm total movement between fingers. The speed is linearly proportional to the force. For
more details see speed table on page 133.
Force Sensor Properties
Fxy
Fz
Txy
Tz
Units
Nominal capacity (N.C.)
20
40
0.7
0.5
[N] [Nm]
Single axis overload
200
200
200
200
[%]
Noise free resolution
0.1
0.4
0.008
0.005
[N] [Nm]
Single axis deformation at N.C.
0.4
0.015
0.1
0.04
2
5
[mm] [°]
[inch] [°]
Full scale nonlinearity
Temperature compensation
< 2
[%]
General Properties
Min
Typical
Max
Units
Payload Force Fit
-
-
-
-
2
4.4
[kg]
[lb]
Payload Form Fit
-
-
-
-
4
8.8
[Kg]
[lb]
Total stroke (adjustable)
0
0
-
-
100
3.93
[mm]
[inch]
Finger position resolution
-
-
0.1
0.004
-
-
[mm]
[inch]
Repetition accuracy
-
-
0.1
0.004
0.2
0.007
[mm]
[inch]
Reversing backlash
0.2
0.007
0.4
0.015
0.6
0.023
[mm]
[inch]
Gripping force (adjustable)
3
-
40
[N]
Gripping speed*
55
110
184
[mm/s]
Gripping time**
0.04
0.07
0.11
[s]
Adjustable bracket tilting accuracy
-
< 1
-
°
Ambient operating temperature
5
-
50
[°C]
Storage temperature
0
-
60
[°C]
Motor
Integrated, electric BLDC
IP Classification
IP54
Dimensions
219 x 149 x 49
8.6 x 5.9 x 1.9
[mm]
[inch]
Product weight
0.98
2.16
[kg]
[lb]