EasyManua.ls Logo

YAKO MS - L3P - Page 8

YAKO MS - L3P
9 pages
Print Icon
To Next Page IconTo Next Page
To Previous Page IconTo Previous Page
Loading...
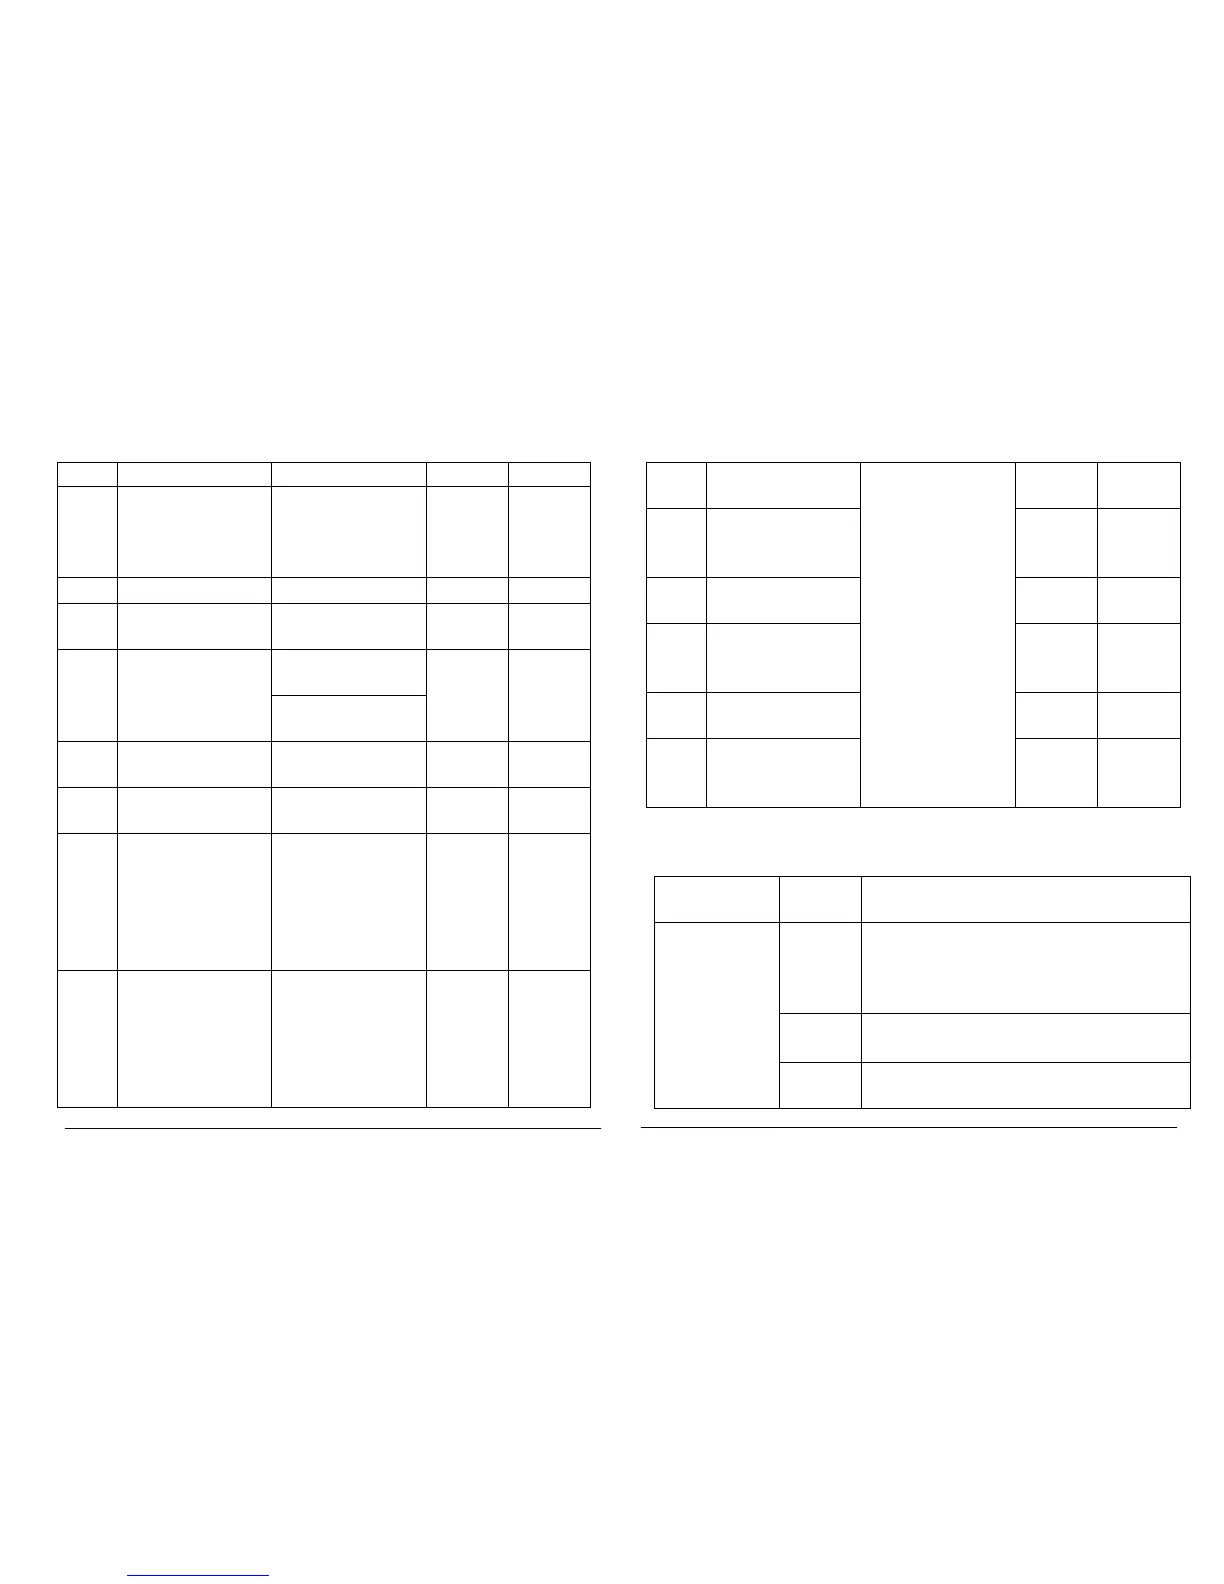
MS-LxP Series Hybrid Servo DriverVersion2.0 MS-LxP Series Hybrid Servo DriverVersion2.0
8
PA-12 Maintain time
10 0~200
PA-13
Choice of delete the
level signal of
tracing error alarm
1 0/1
PA-15 Choice of MF level
1
0/1
PA-16
alarm signal output
level
0
0/1
PA-17
Single and double
pulse choice
0 Pulse direction
mode
0 0/1
1 double pulse
mode
PA-18
Pulse effective
choice
0
0/1
PA-19
Choice of motor
rotation direction
1
0/1
PA-2
3
Position ratio
Set the proportion
of the position loop
controller gain, the
larger the value, the
bigger the stiffness.
5 0~10
PA-2
4
Feedforward
coefficient of speed
Set the position loop
feedforward gain,
the larger the value,
the bigger the
stiffness.
1000 0~1000
PA-7
1
speed section 1
In different speed
section, the
adjustments on
resonance
suppression help to
eliminate vibration.
942
0~60000
PA-7
2
resonance
suppression
coefficient 1
50
0~200
PA-7
3
speed section 2
5024
0~60000
PA-7
4
resonance
suppression
coefficient 2
50
0~200
PA-7
5
speed section 3
6280
0~60000
PA-7
6
resonance
suppression
coefficient 3
50
0~200
3) Parameter management EE-
There are 6 level 2 menus under EE as below:
Level 1 menu
Level 2
menu
Function
EE-(parameter
management)
EE-SEt
Parameter write-in, means write the
parameters of driver’s memory in EEPROM.
If users don’t do this operation, the
parameters you changed will restore.
EE-rd
Parameter read-in, means read the
parameters of EEPROM in memory.
EE-bA
Parameter backup, means write the
parameters of memory in EEPROM.

Related product manuals