N7 Autopilot User Manual (ArduPilot) v1.0
63
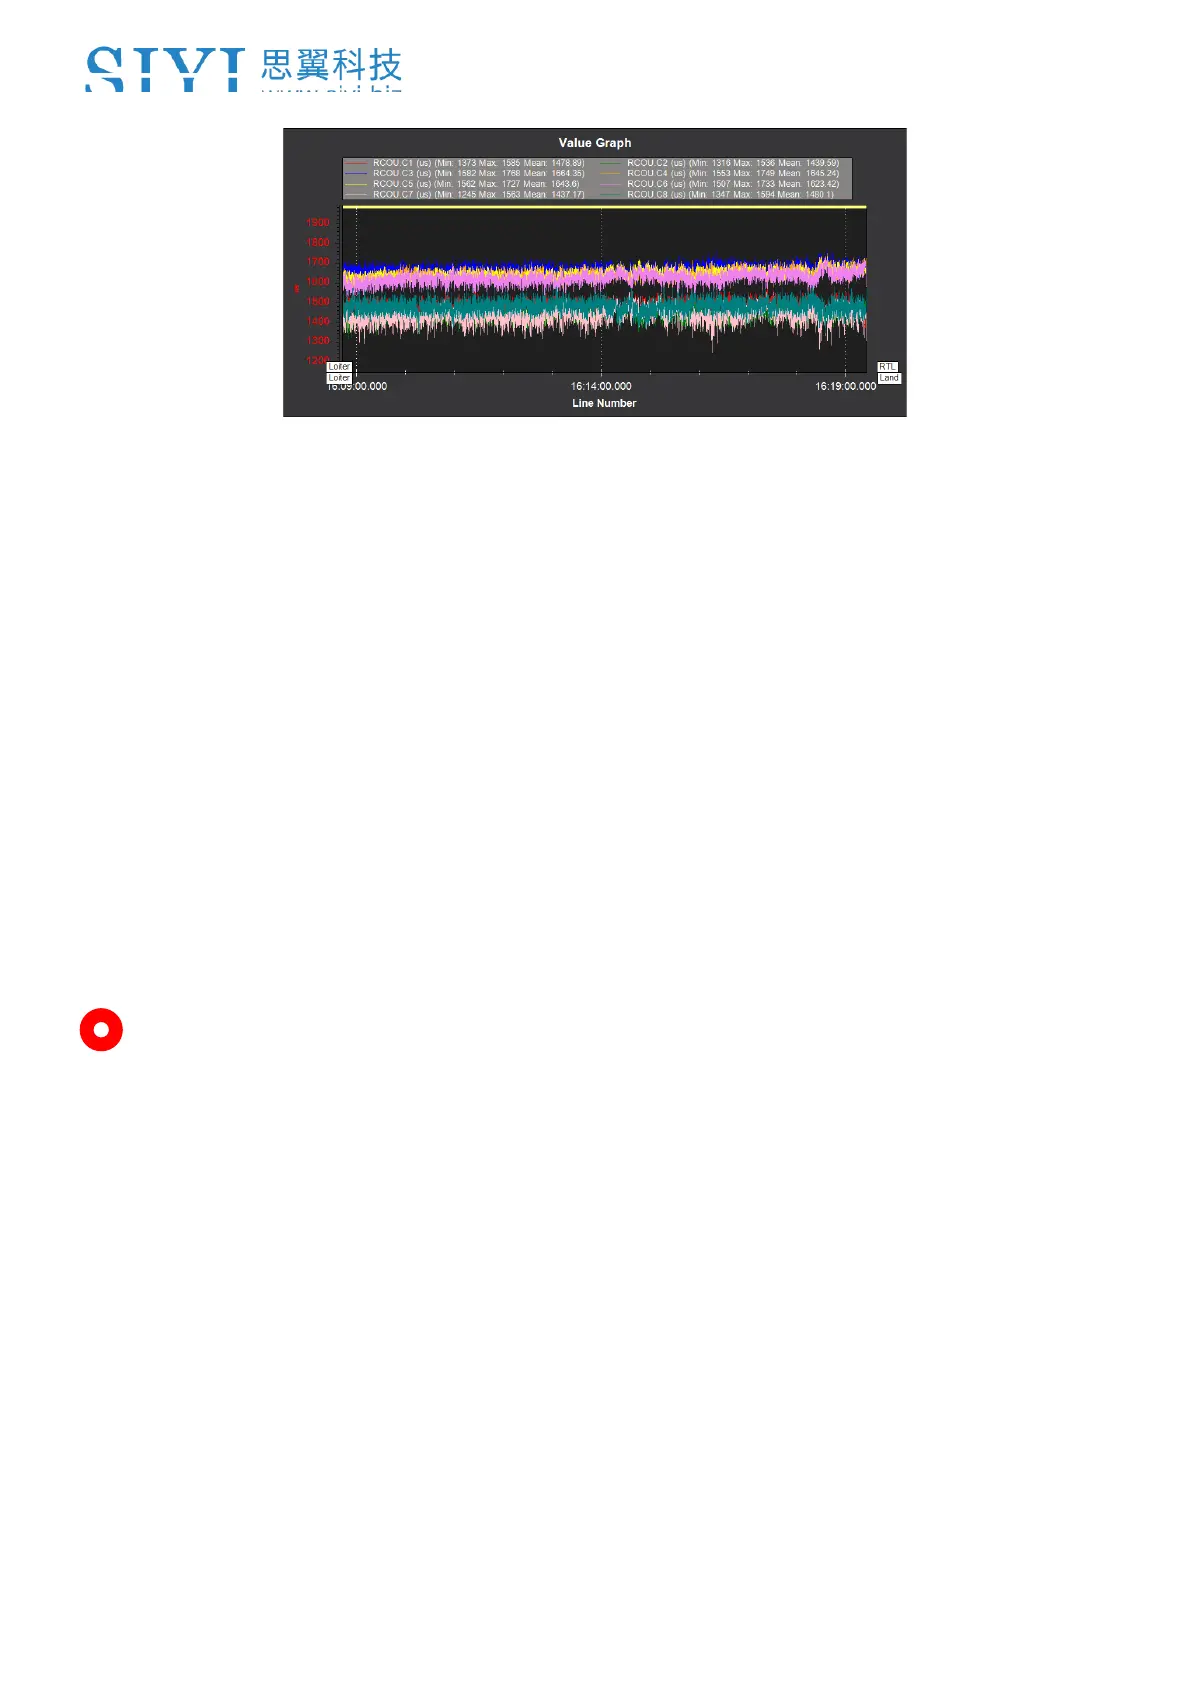
This should be fixed in hardware. The most common cause is the motors not being
vertical on a circular arm. If the imbalance persists the motors can be tilted slightly
such that the thrust angle assists the yaw for its rotation direction. Some vehicles
can be extremely sensitive to motors thrust vector.
If the warning is only seen in aggressive yaw maneuvers, the warning threshold can
be increased by raising ATC_RAT_YAW_IMAX. However, it may also be worth
revisiting the yaw tune.
Mark
Both the thrust loss and yaw imbalance warnings can be disabled with the
FLIGHT_OPTIONS parameter. This should only be done after extensive log review and
testing to verify the warnings are not picking up genuine issues.


 To Next Page