87 2023-09-22 SM-A63469-A/2
Brake Release Input
<EtherCAT and EtherNet/IP I/O Signals to be Used>
Brake Release Input (Input signal 1 - bit 13 / input data byte 1 - bit 5)
Start input (Input signal 1 - bit 8 / input data byte 1 - bit 0)
Positioning completion output (Output signal 1 - bit 9 / output data byte 1 - bit 1)
The brake is released while this signal is turned on even if the brake is applied.
If a forced stop is supplied when the brake is applied, the brake remains applied even after the
equipment is reset.
To input a start signal without setting a new program number, reset and supply a brake release
input to release the brake, then supply the first start signal.
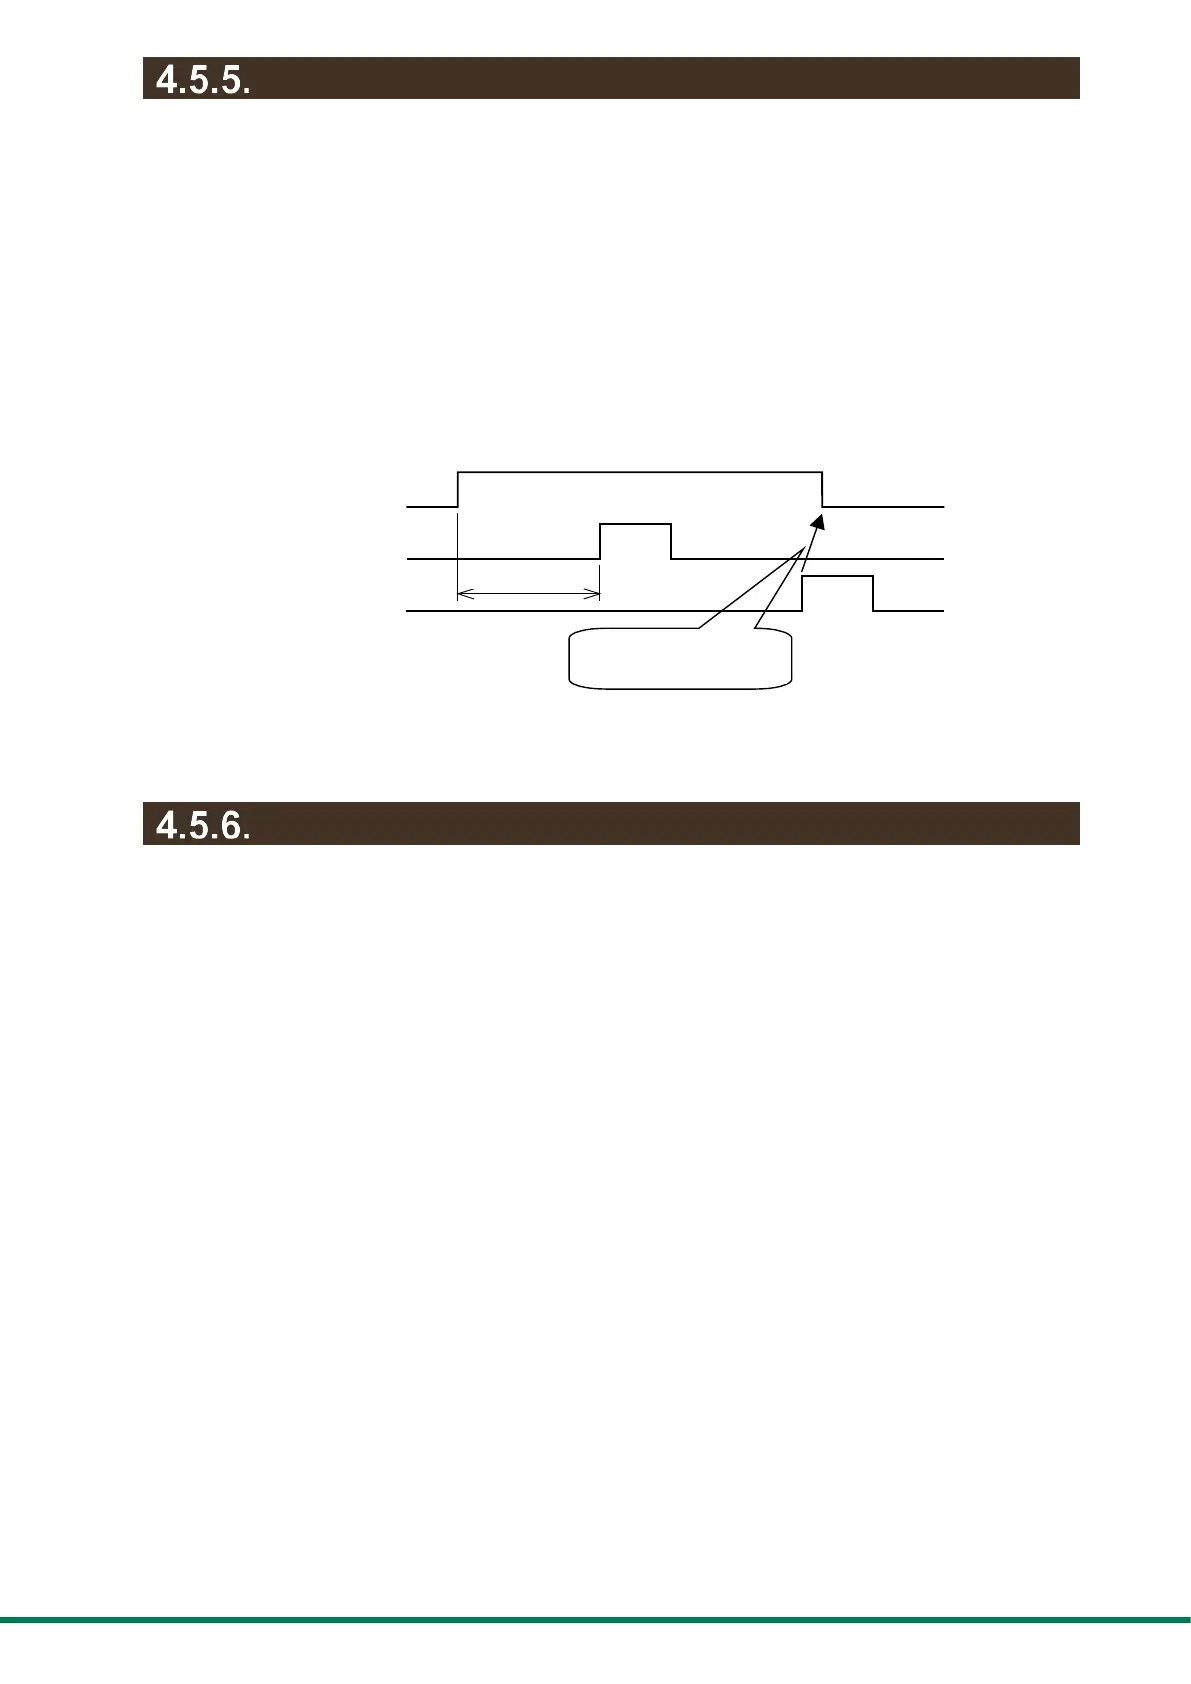
<Timing of Brake Release Input>
位置決め完了出力
ON
後、
ブレーキ解除入力を OFF する。
The above signal is necessary if M68 (apply brake) is used in the program even if models
without a brake are used.
Servo State Output
<EtherCAT and EtherNet/IP I/O Signals to be Used>
Servo state output (Output signal 1 - bit 14 / output data byte 1 - bit 6)
<PRM to be Used>
PRM57=1: Function selection for I/O output signal CN3-47 (bit 14)
The signal indicating the current servo state is issued from Output signal 1 - bit 14 / output data
byte 1 - bit 6. The signal is output in the servo-on mode.
It is not output in an alarm causing servo-off or in the servo-off (M5) mode.
In case of a forced stop, the servo state signal is turned off after a delay specified in PRM22
(forced stop servo-off delay).
The servo and the servo state signal are turned off immediately only in the M3 mode.
This function is an alternative to “output in indexing 2.”
Positioning completion output
After the positioning completion
output is turned ON, the brake
release input is turned OFF.


 To Next Page