Alignment Sensor Command Overview
To program robots and PLCs to control the vision sensor at run time and perform
requested tasks, you use the command interface of the AS200 Alignment Sensor.
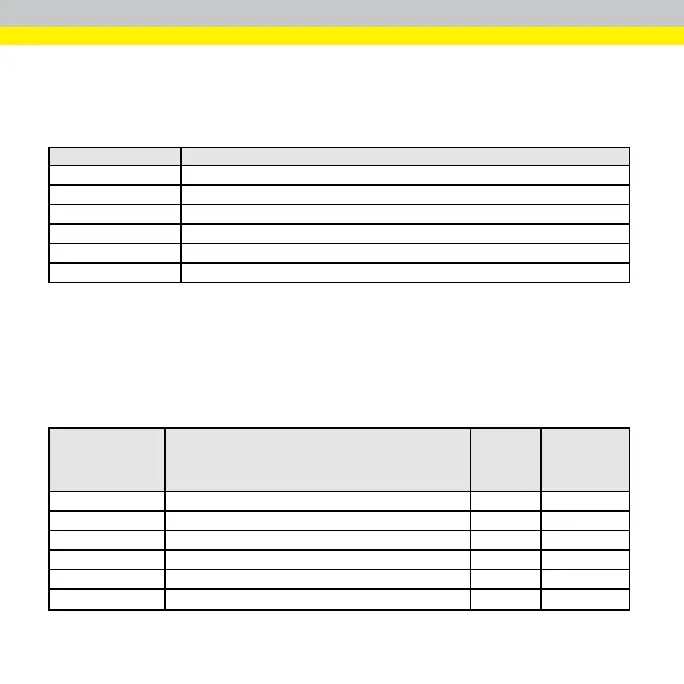
The interface contains the following degree of freedom coordinates:
Coordinate Description
X The X coordinate of the pose
Y The Y coordinate of the pose
Z The Z coordinate of the pose
A The rotation angle about the Z axis, in degrees
B The rotation angle about the Y axis, in degrees
C The rotation angle about the X axis, in degrees
The command interface requires all six pose coordinates. However, as a 2D system,
the Alignment Sensor only accepts X, Y, and A and ignores Z, B, and C.
PLC/Robot Commands
The AS200 Alignment Sensor supports the following commands. How the
commands are referenced in PLC/Robot functions differs based on the
communication protocol (TCP/IP or SLMP Scanner).
Command Purpose
Referenced
in TCP/IP
functions
as:
Referenced in
SLMPScanner
functions as:
ACB Initiates an automatic calibration ACB 2030
AC Executes an automatic calibration AC 2031
HEB Initiates a hand-eye calibration HEB 2020
HE Performs a hand-eye calibration HE 2021
HEE Completes and computes a hand-eye calibration HEE 2022
CCB Initiates a hand-eye calibration CCB 2040
14


 To Next Page