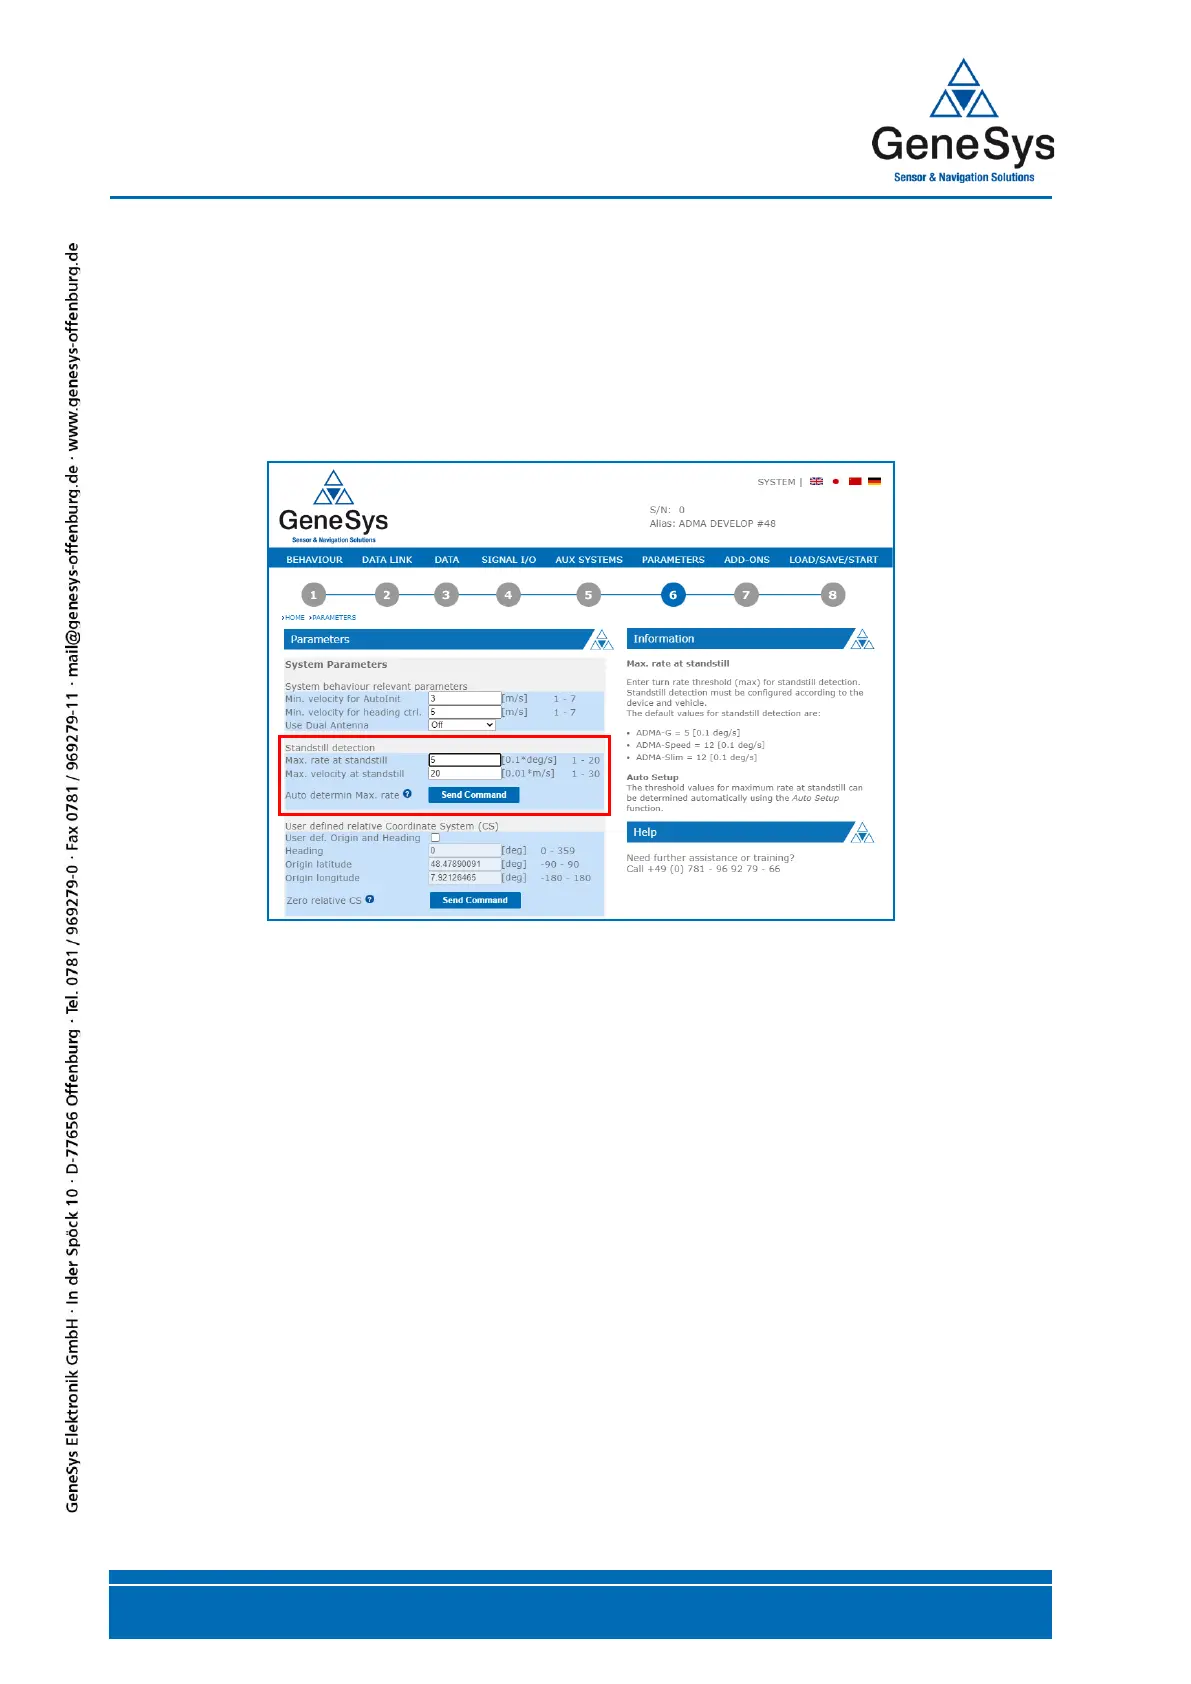
8.4 Standstill detection
The following describes standstill detection thresholds and their correct entry, which will increase the
data integrity. Standstill allows a special form of augmentation for use with the Kalman filter, the so
called Zero-Velocity-Update. This mode of the Kalman filter update increases the stability of the
measurement mode in case of standstill.
If the standstill is detected (Standstill bit = 1), the INS YAW and the INS Velocity are bounded. A
control-loop will only be allowed again after leaving this mode.
This constraint is determined by three independent values: Rate, Velocity and GNSS Mode.
Figure 32 Dialog: Parameters - Standstill detection


 To Next Page