Building Interlude: Make the TaskBot Smart!
Up until now our robot has been good at following instructions, but it has not been
able to make any decisions. We know from the getting started activities that sensors
enable robots to sense the environment around them. We can give robots the
ability to make decisions based on the information that sensors provide, thereby
appearing smart.
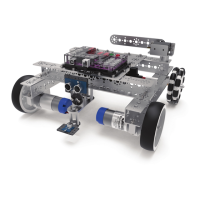
In the next coding examples, we will attach sensors to the PRIZM TaskBot. We will
work though two examples using the Line Finder Sensor and two examples using
the Ultrasonic Sensor. Instructions for attaching sensors to the PRIZM TaskBot are
shown below.
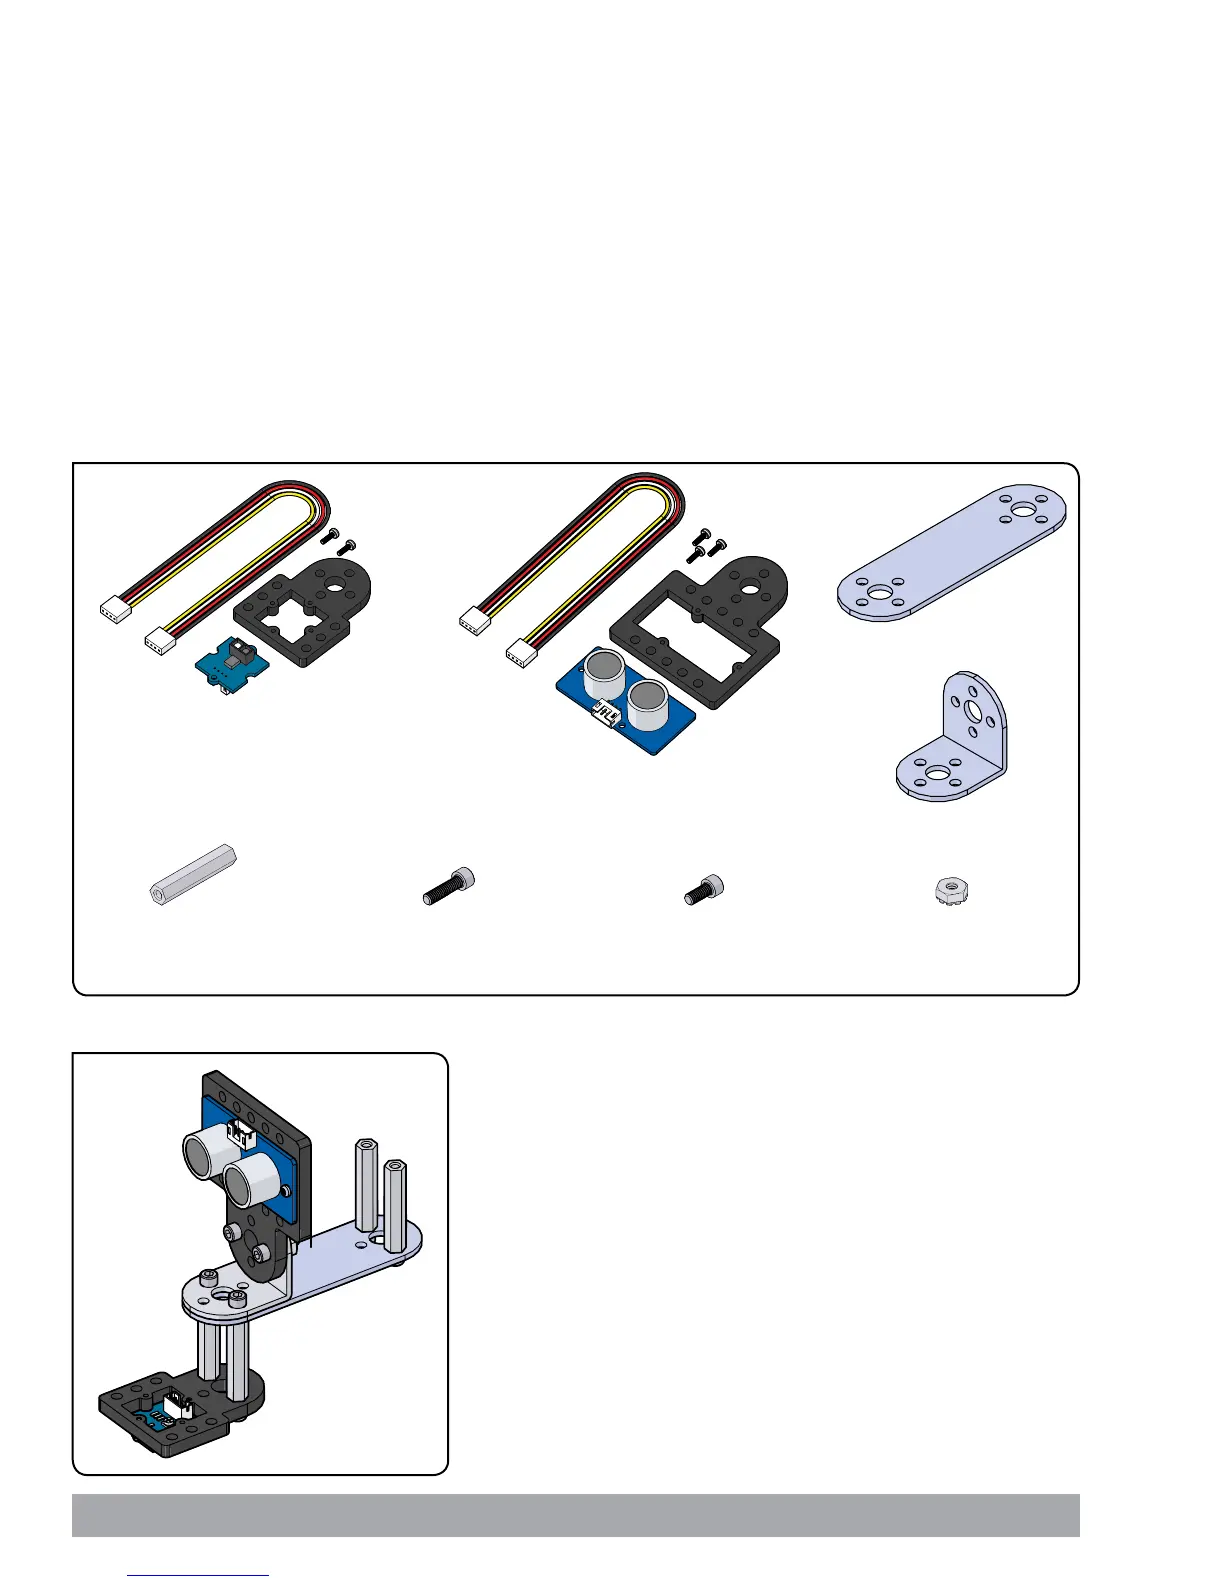
Finished assembly should look like this.
Parts Needed
4x
Stand-Off Post
6-32 x 32 mm 39107
2x
Kep Nut
39094
2x
Socket Head Cap Screw
6-32 x 5/16" 39098
6x
Socket Head Cap Screw
6-32 x 1/2" 39097
1x
L Bracket 39062
1x
Flat Bracket 39061
1x
Line Finder Sensor Pack 43056
1x
Ultrasonic Sensor Pack 43055
Step 1
96 Building and Coding the PRIZM TaskBot


 To Next Page