ECT Series User Manual
19
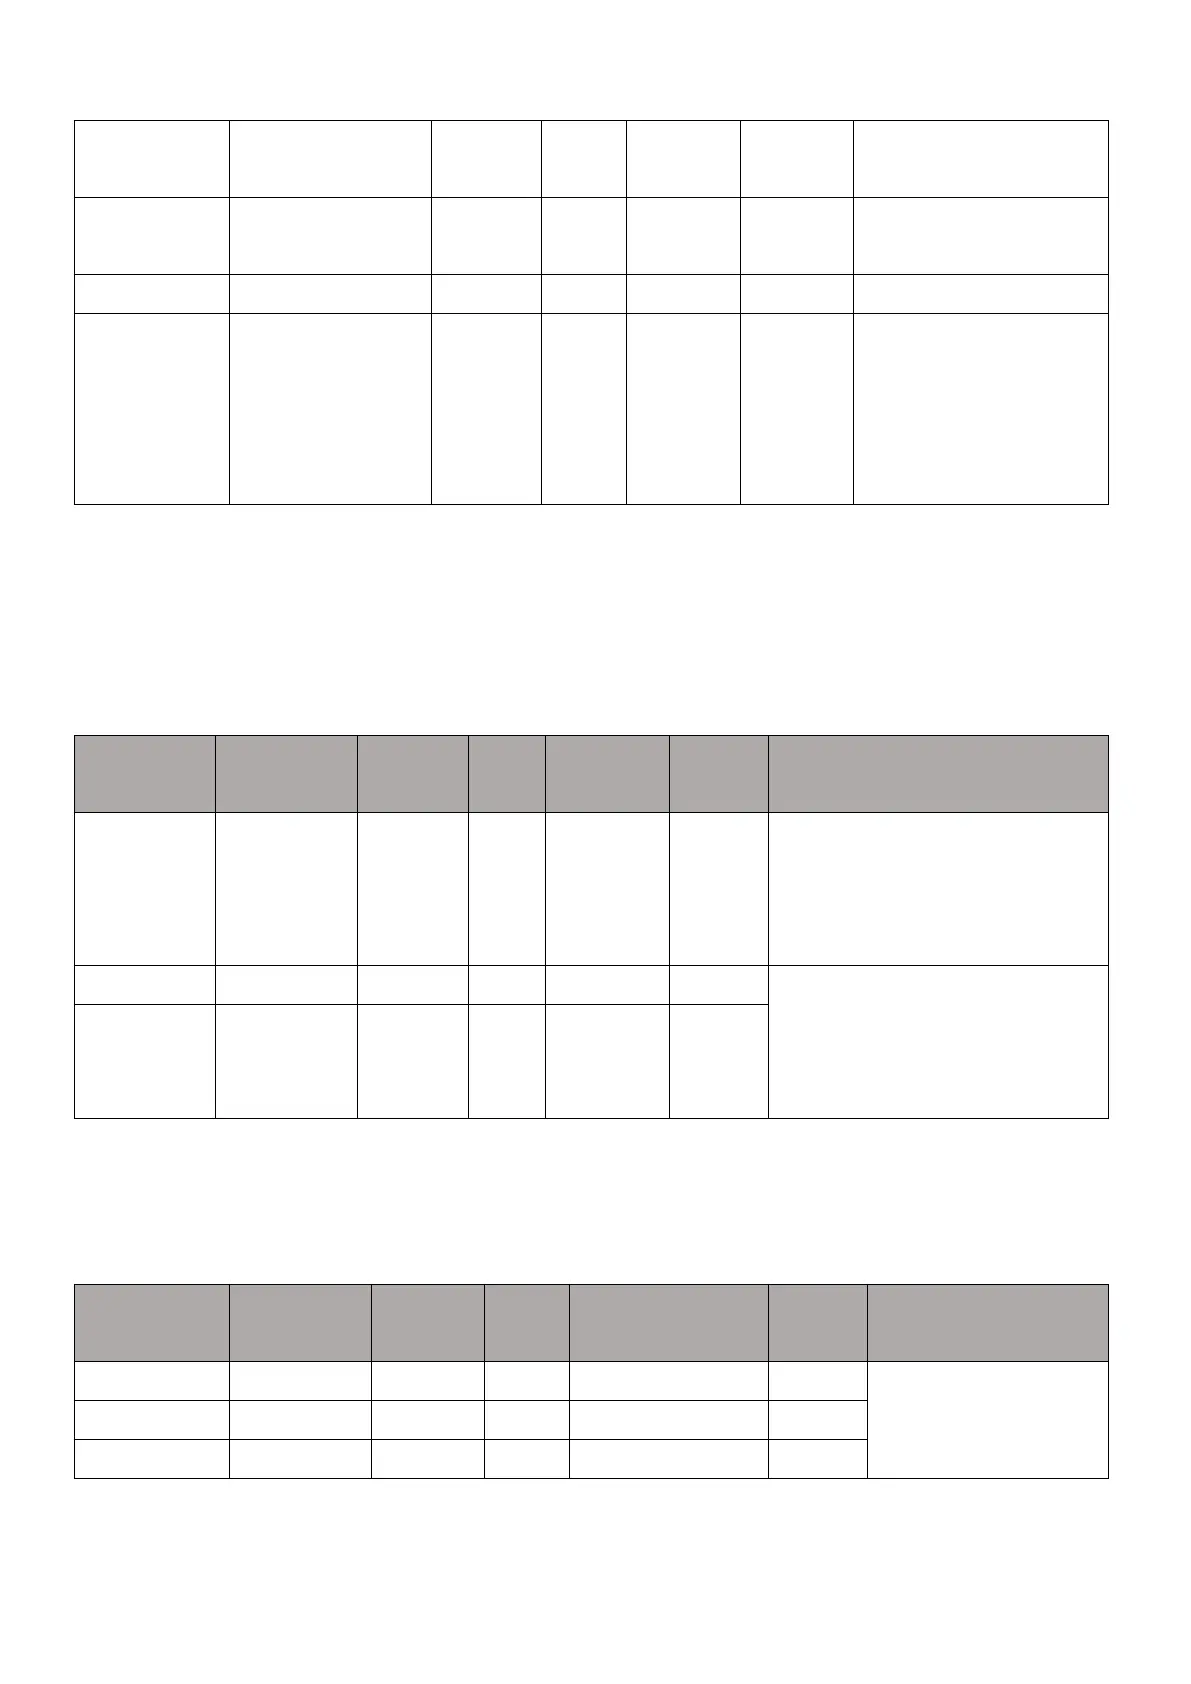
error when the motor
is stationary.
Used to eliminate
low-speed resonance
Usually this gain
cannot be greater than
200
This object only takes effect when ECT60 adopts servo mode 1 for closed-loop control. The
gain is usually the default.
2.2.22 0x2024 In Place Signal
In place signal judgment mode
0—— Detection at any time
1—— Detection after pulse
command stops
When the position error is less
than the set pulse value and
continues for the set in place
time, it is judged to be in place.
This object takes effect in the closed loop mode of ECT60, and is used to detect whether the
motor is within the set accuracy range.
2.2.23 0x2025 Servo Speed Filter
Filter when Servo
Mode 2 is set
This object takes effect under the condition of ECT60 servo mode 2 and is used to set the



 To Next Page