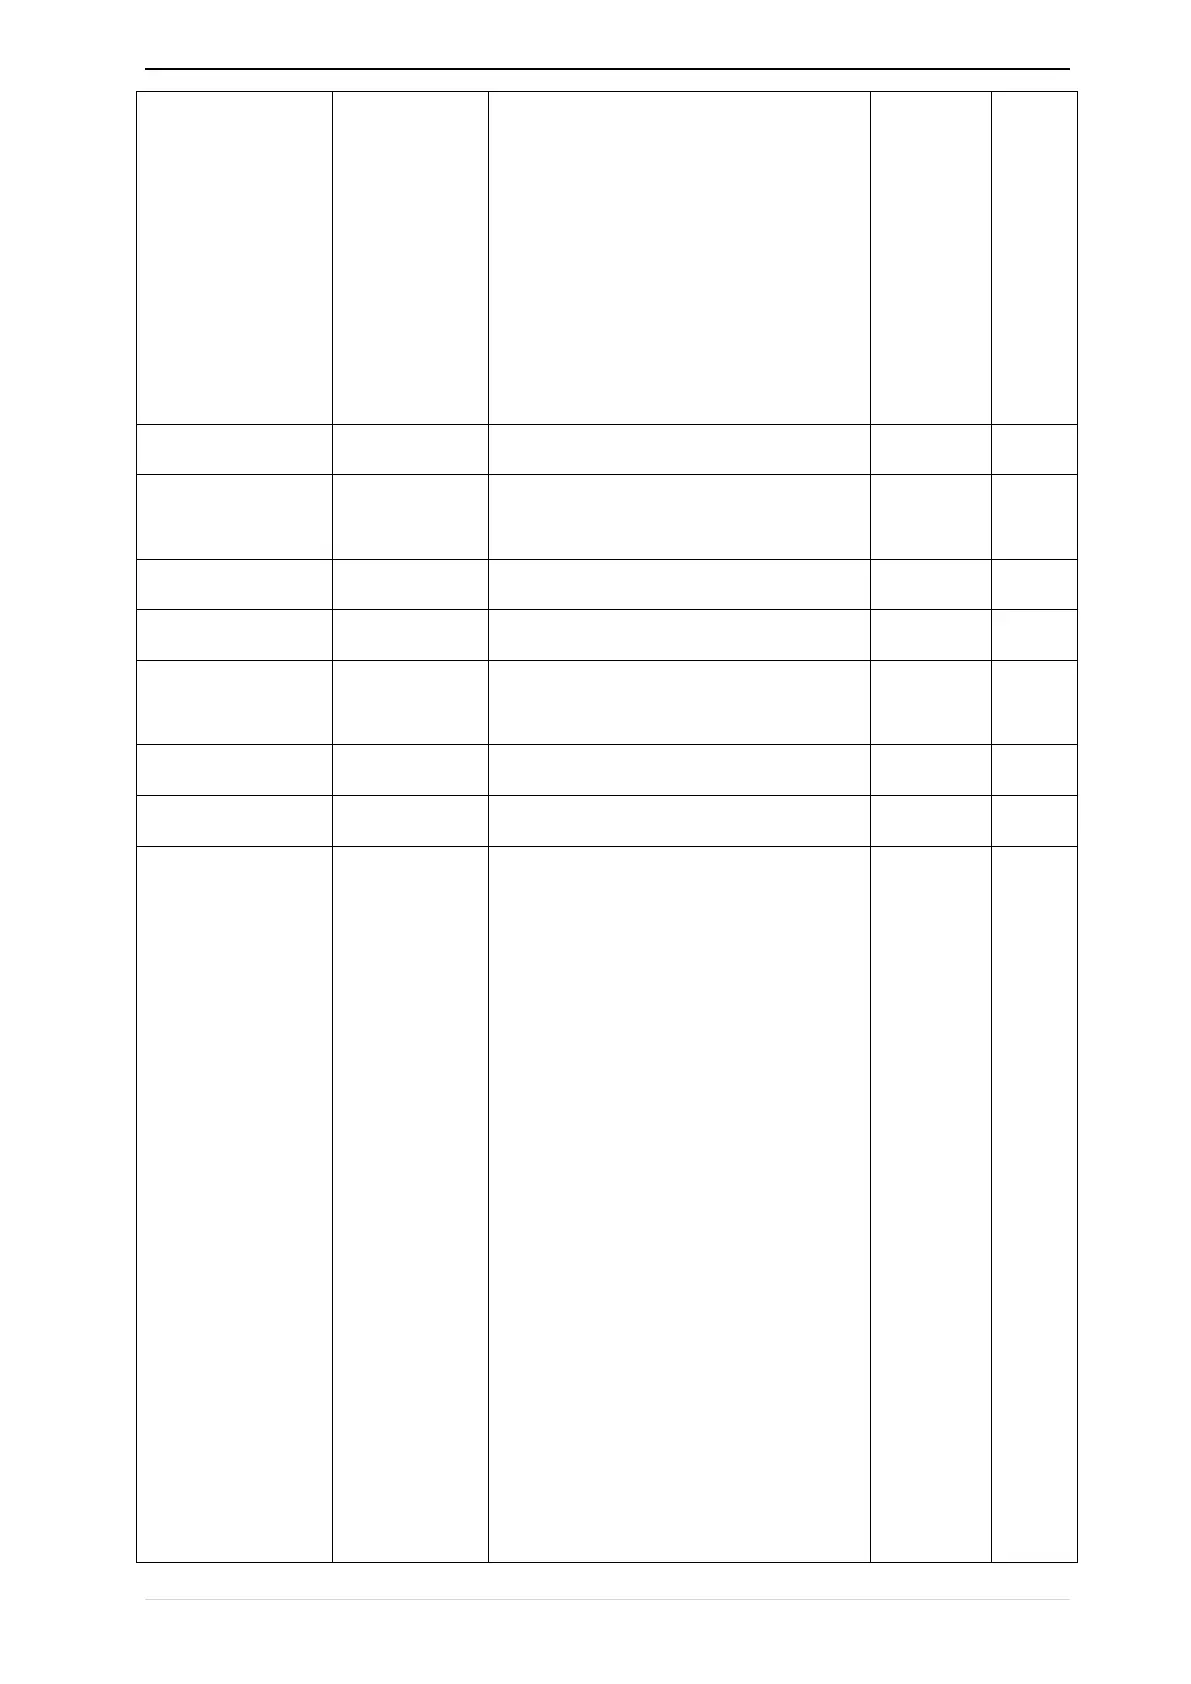
Bit1: Set the direction of the frequency
Bit2: direction of the main frequency
Bit3: direction of the secondary frequency
Bit4: Direction of the UpDown offset
Bit5: Direction of the encoder feedback
frequency
Reserved above Bit6
Bit0:Running status 0-Stop;1-Run
Bit1:Motor direction0-Forward;1-Reverse
Bit2:Ready signal:0-not ready;1-ready
Bit3:fault status 0-no fault;1-fault
Bit4~5:fault type:0-free stop;1-fast
stop;2-stop as per stop mode;3:continue to
run
Bit6:jog status:0-no jog;1-jog status
Bit7:Auto tune :0-no;1-yes
Bit8:DC braking:0-Non DC braking;1-DC
braking
Bit9:Reserved
Bit10~11:Acceleration and Deceleration:
0:stop/zero output;1:speed up;2:slow
down;3:constant speed
Bit12:Warning status: 0:no warning;


 To Next Page