19
ã Terberg Machines B.V. IJsselstein, The Netherlands
All rights reserved. No part of this book may be reproduced, stored in database or retrieval system, or published, in any form or in any way,
electronically, mechanically, by print, photoprint, microfilm or any other means without prior written permission from the publisher.
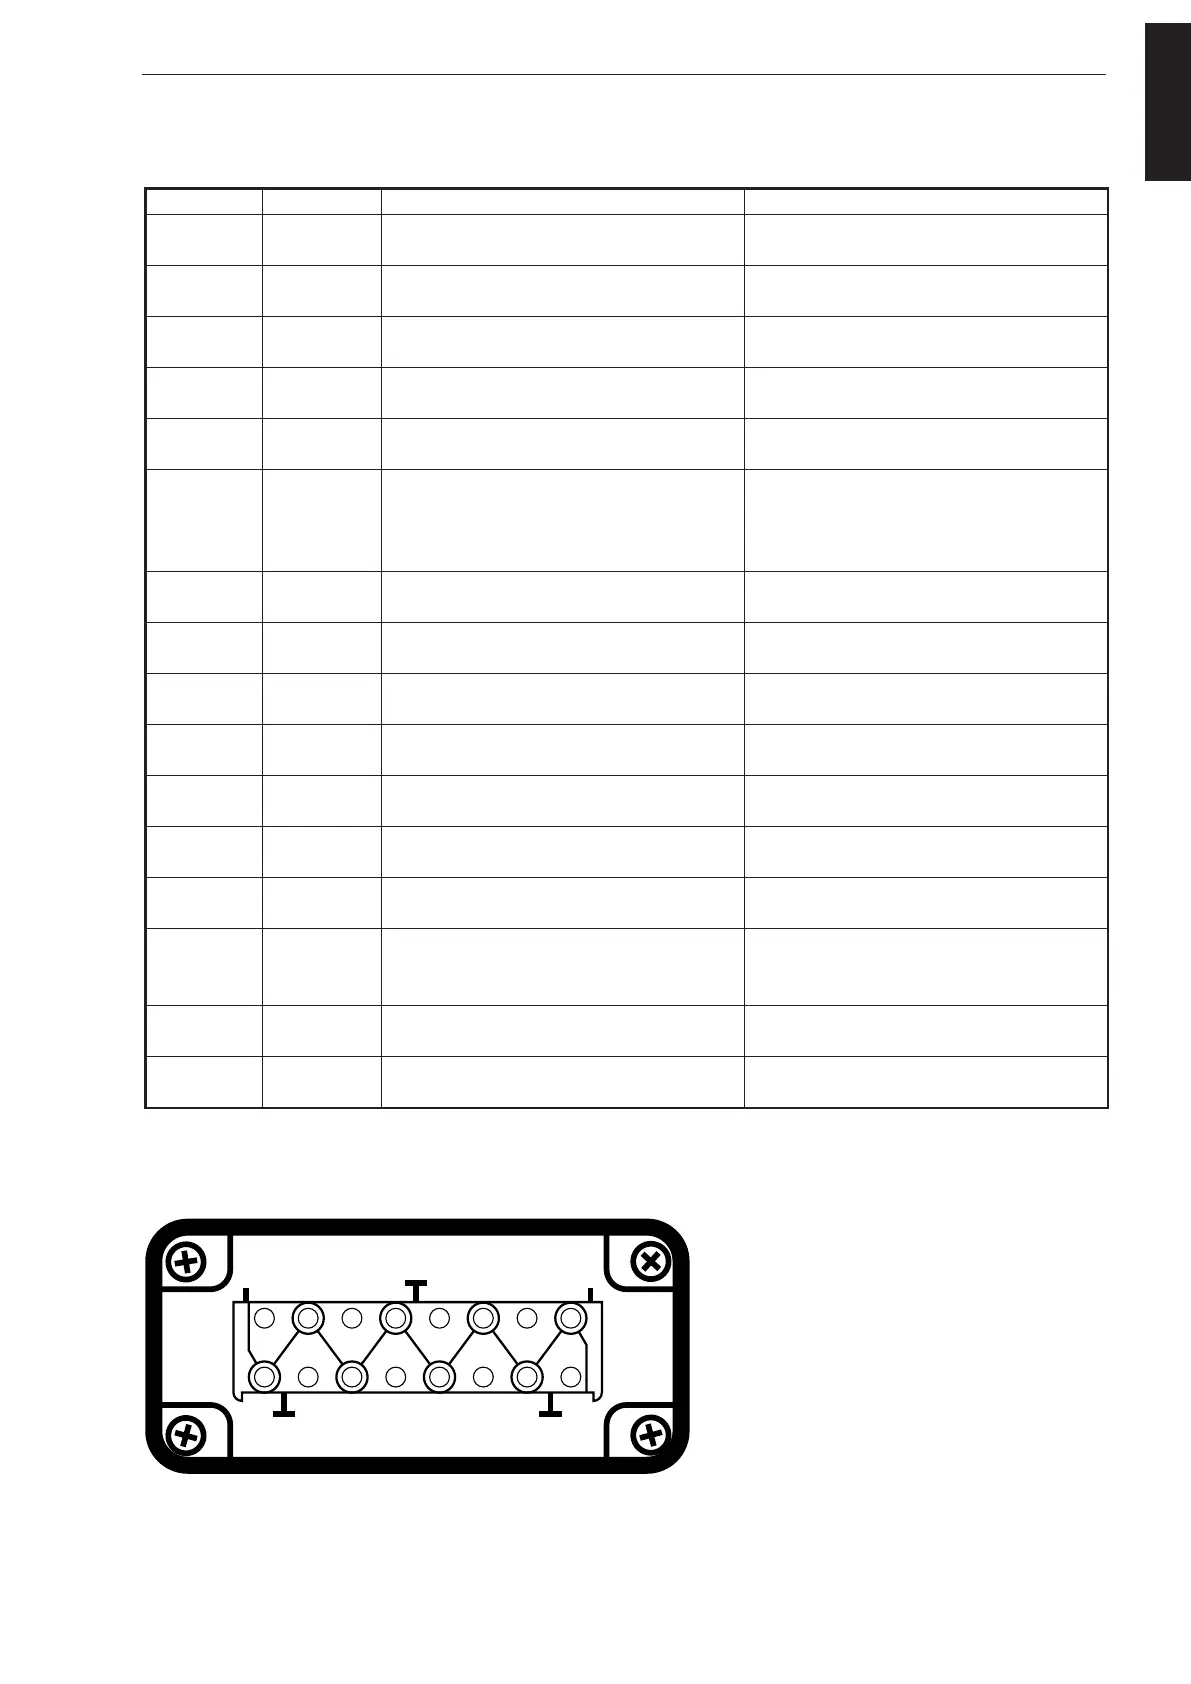
16-pole plug fixed socket pin / wire definitions on bin lift
Pin number: Signal type: Signal description: Observation:
1 Input RCV in neutral gear = +24 V 16 to 34 V
2 Not connected Info no bin lift fitted
3 Output Safe distance from footboard level
4 Output Safe distance from footboard level
5 Input Footboards OCCUPIED 0V
6 Output
Clash between bin lift and packer plate
(info to RCV that container is within
reach of packer plate).
+24 V = packer plate stops, as soon as
the container is out of reach of the
packer plate an extra start signal
compaction cycle is given.
7 Bus CleAN open CAN (L)
8 Not connected
9 Not connected
10 Not connected
11 Not connected
12 Input
Emergency stop control system:
normal “safe” state = +24 V
Maximum 3 Amps
13 Output
Signal hopper plate switch (OK = +24 V).
Safety distance okay from ground level.
14 Input
Clash between packer plate and bin lift
(info to bin lift that packer plate is within
reach of container).
+24 V = bin lift stops in horizontal
position out of reach of the packer plate.
15 Bus CleAN open CAN (H)
16 Output
Signal hopper plate switch (OK = +24 V).
Safety distance okay from ground level.
16-pole socket box contact side



 To Next Page