125
【move (arc) line [variable] X() Y() Z() Roll() Pitch() Yaw() Radius()
Wait(true/false) 】
● The command passes through the Cartesian motion and supports variable values.
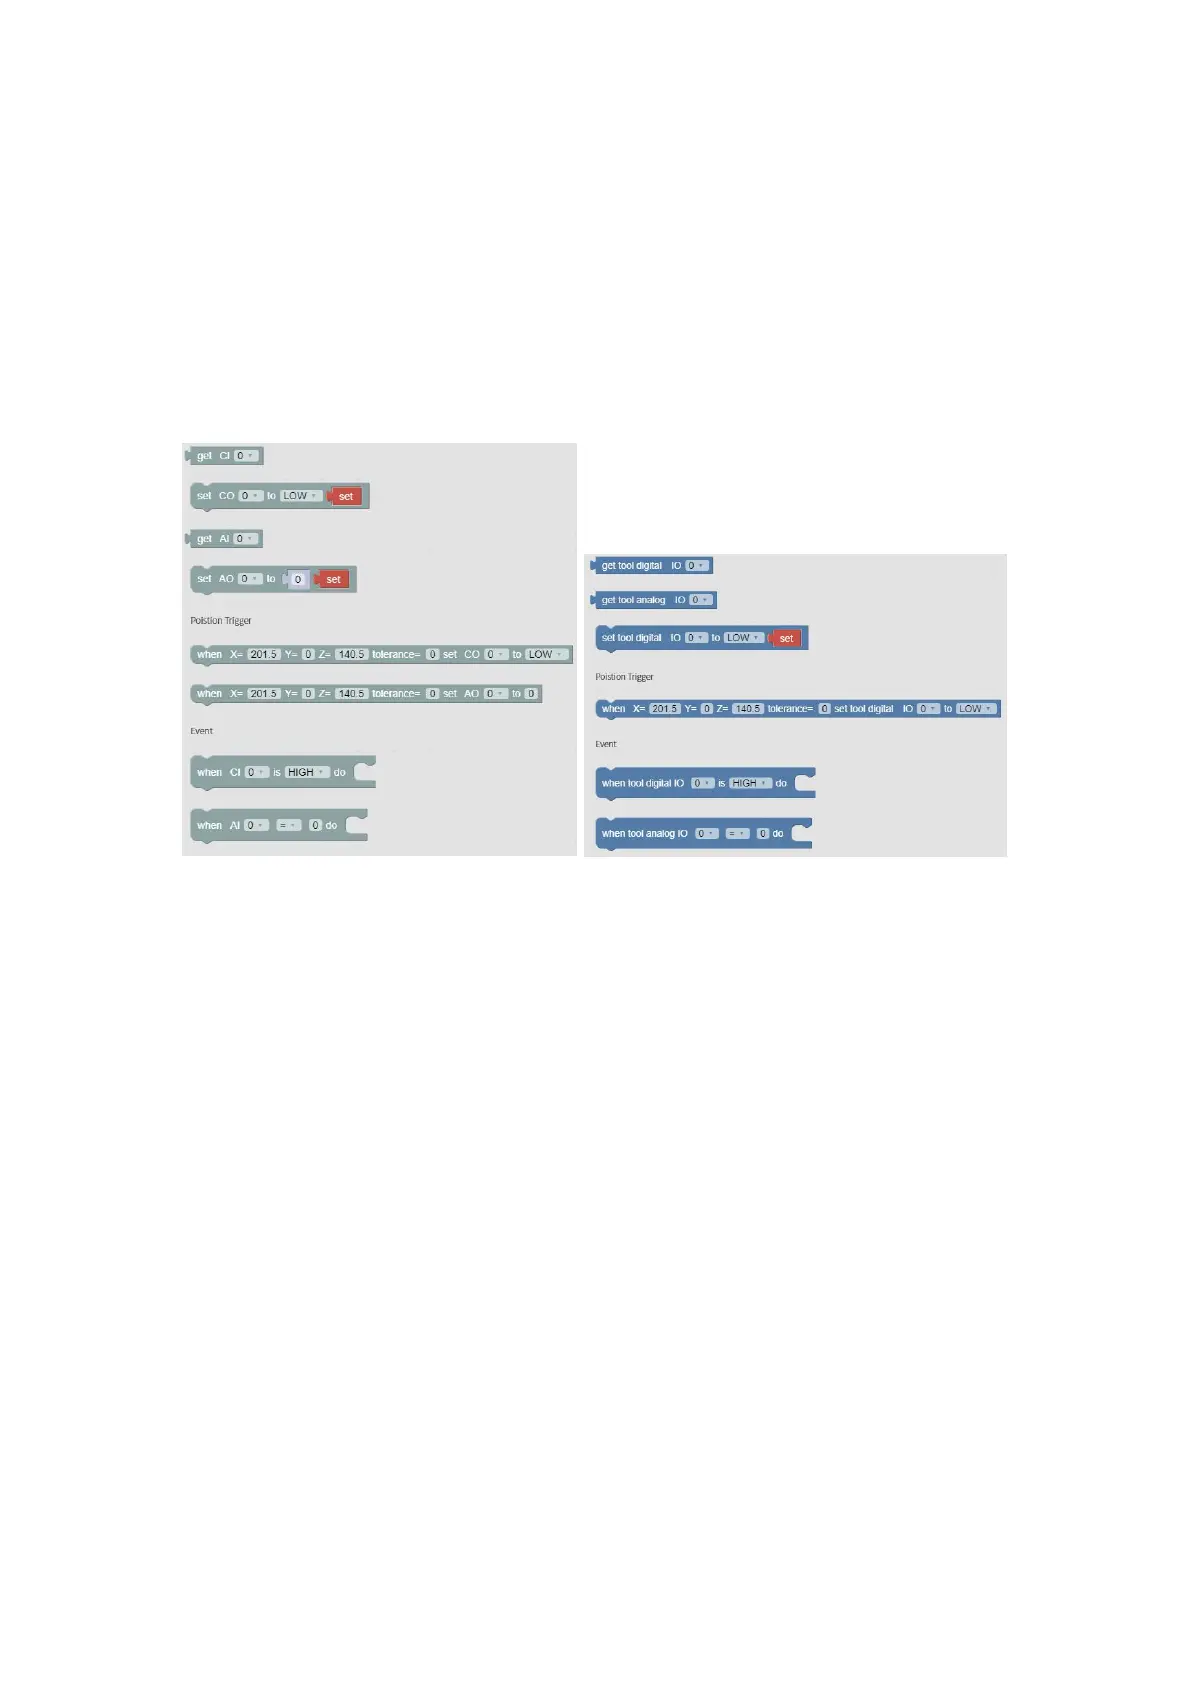
1.6.6 GPIO(Control Box and End tool interface)
The IO interface is made up of a control box interface and an end tool interface,
which can be used to acquire, set, and monitor IO interface operations. The control
box has 8 digital input interfaces, 8 digital output interfaces, 2 analog input interfaces,
and 2 analog output interfaces. The end tool has 2 digital input interfaces and 2 digital
output interfaces. 2 analog input interfaces. The control box digital IO is low-level-
triggered. The end tool digital IO is high-level-triggered.
【get I/O 】
● Acquire the I/O interface data of the code block.
【set I/O 】
● Set the I/O interface of the code block, click 【Set】 to run the command.
【set I/O when(X, Y, Z, tolerance)】


 To Next Page