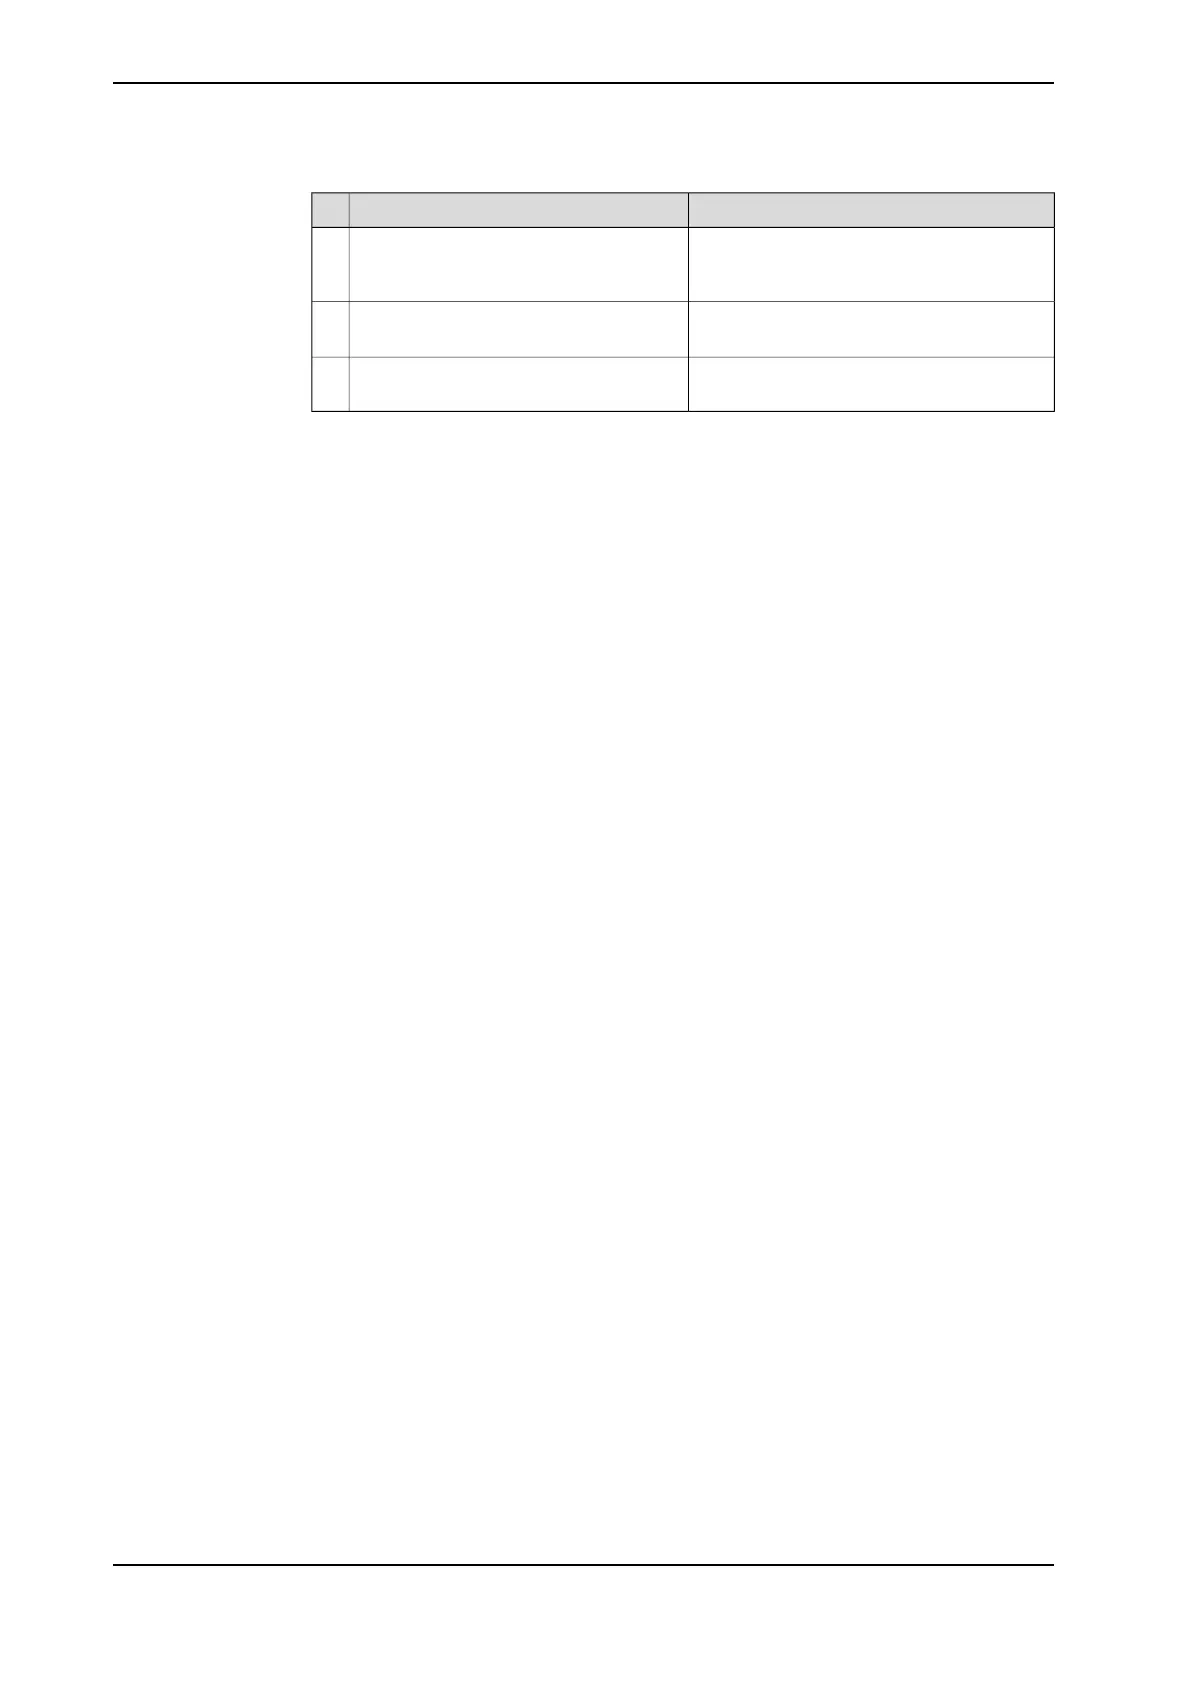
NoteAction
Update the system with the correct robot
type, see Operating manual - Integrator's
guide OmniCore.
Make sure the correct robot type is con-
nected as specified in the system.
8
Proceed as detailed in section Problem re-
leasing the robot brakes on page 404.
Make sure the robot brakes work prop-
erly.
9
The swivel has an in-built resistance that
needs to be set in the system parameters.
If applicable: Check the setting for the
swivel.
10
412 Product manual - OmniCore C30 Type A
3HAC089064-001 Revision: A
© Copyright 2024 ABB. All rights reserved.
6 Troubleshooting
6.2.9 Inconsistent path accuracy
Continued


 To Next Page