is not suitable for frequent drift
occasions
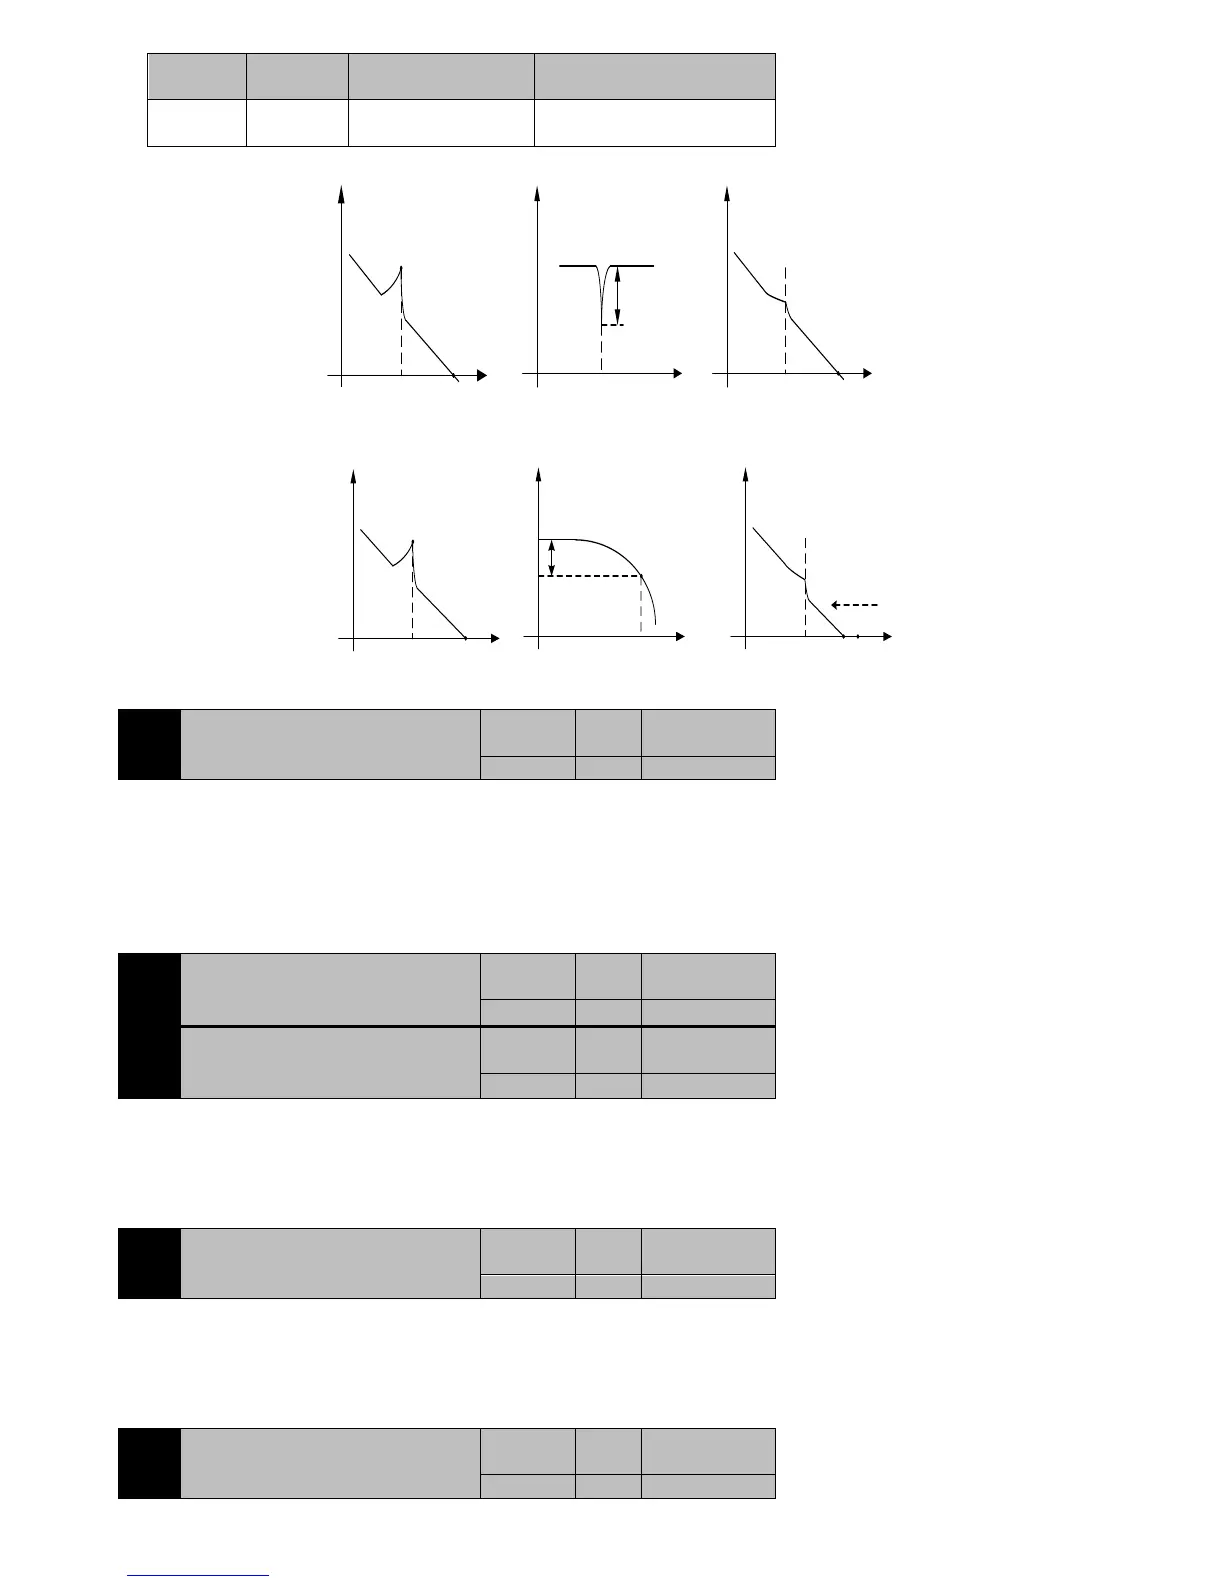
Notch
filter
gain
+
Notch depth
P1-50
resonance frequencyP1-49
=
Mechanical
response
gain
B.W
Resonance point was
suppressed
Mechanical
response
gain
B.W
Resonance
point
resonance frequencyP1-49 resonance frequencyP1-49
Constant
bandwidth
Figure7-14 The principle of vibration suppression using notch filter
+
Mechanical
response
gain
B.W
Resonance point was
suppressed
Low
pass
filter
gain
Frequency
-3db
0db
Cutoff
frequency and
P1-22
correlation
Mechanical
response
gain
B.W
Resonance
point
Resonance
frequency
=
Bandwidth reduction
Figure 7-15 The Principle of vibration suppression using low pass filter
Control Mode:P S T
Range:0~1
Data size:16bit
Display mode:Decimal system
Parameter function:set stop mode
P1-53=0:when servo OFF, free parking
P1-53=1:when servo OFF, slow down stop
Servo ON- receive instruction delay time
Brake command - servo OFF delay time
Control Mode:P S T
Range:0~500
Data size:16bit
Display mode:Decimal system
Parameter function:Please refer to section 3.7.2.
Braking command action speed
Control Mode:P S T
Range:1~1000
Data size:16bit
Display mode:Decimal system
Parameter function:Please refer to section 3.7.2.
Servo OFF- brake command waiting
time


 To Next Page