2. Alarmrecordingfunction
This function records and stores the error alarms (internal cause) as they occur, along with their alarm
number and alarm conditions at that time. Up to 50 alarms can be stored.
* This function does not store the "81: AC POWER DOWN" error alarm.
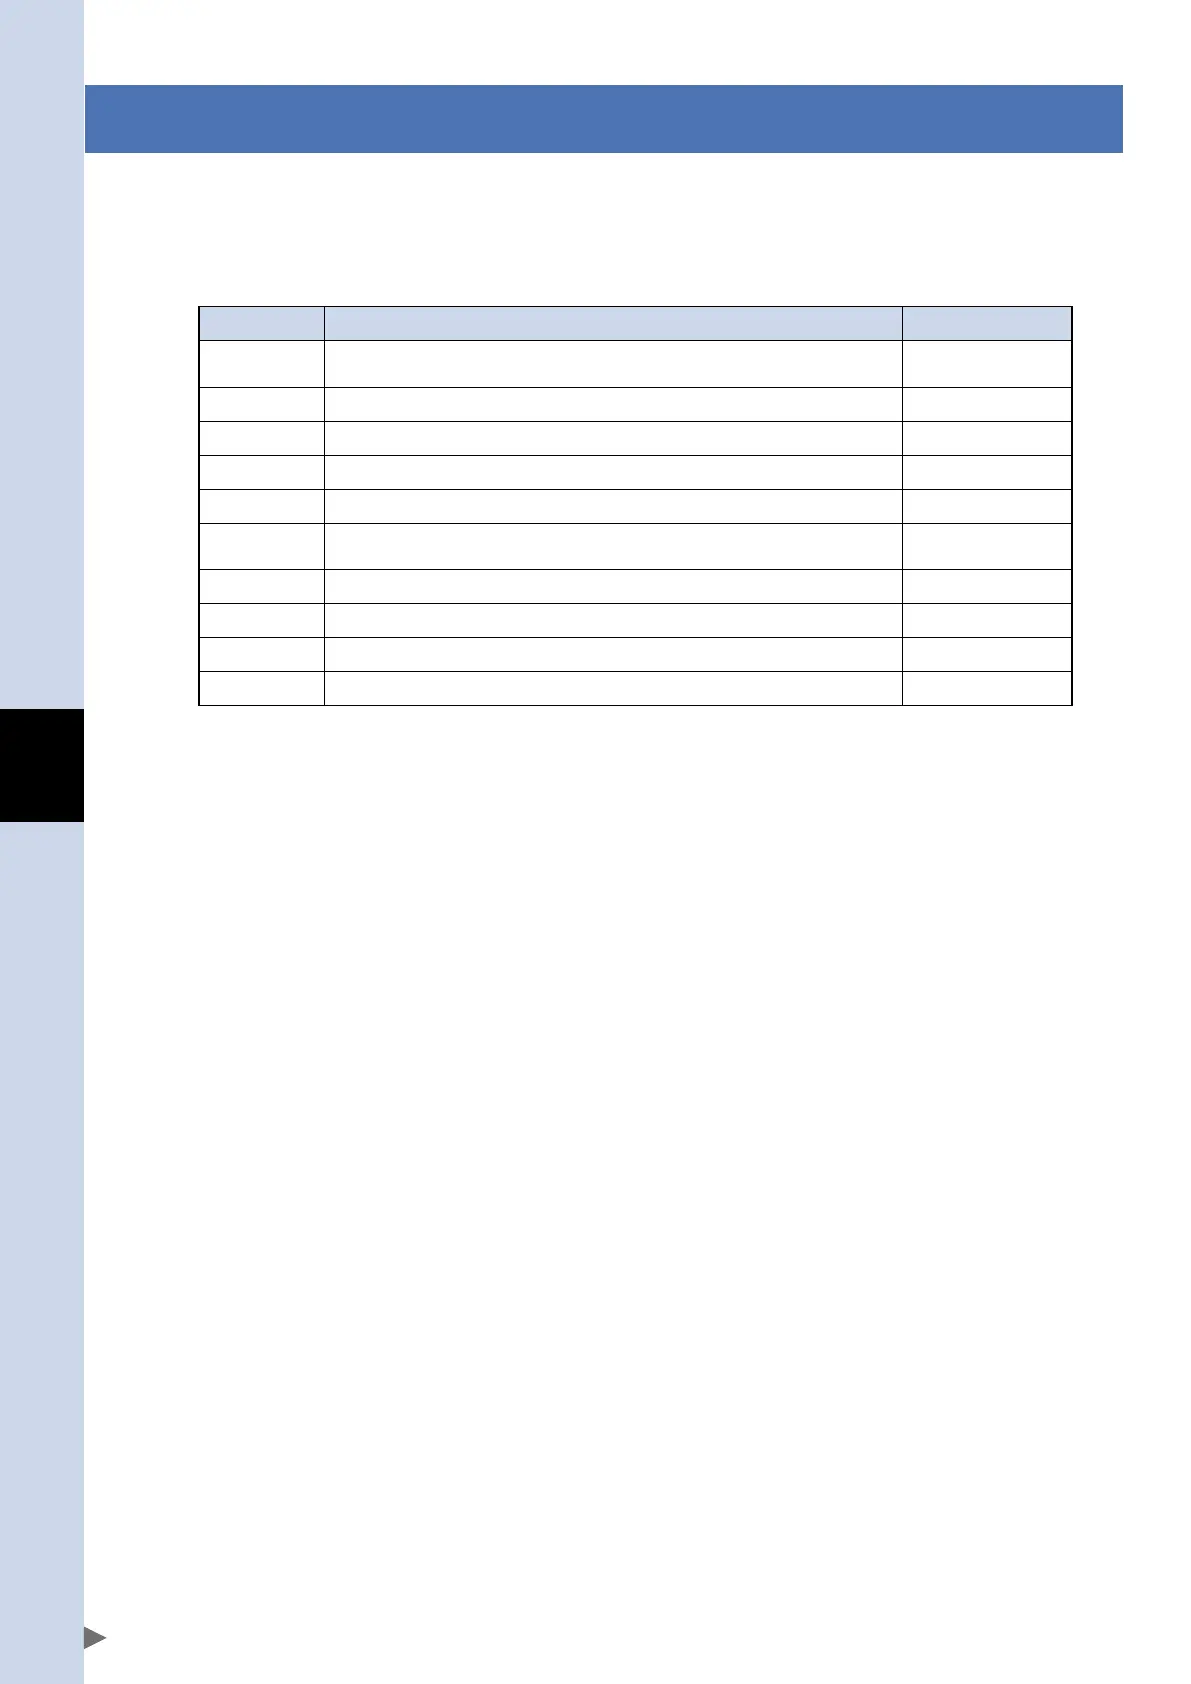
Alarm description
n
Item Description Units
Cause
If 2 or more error alarms occur, the cause of the alarm with the smaller alarm No.
is stored.
-
Time Total time counted while control power was on. Day : hour : minute
Position Current position information when an alarm occurred mm
Speed Speed at which robot was moving when alarm occurred. mm/s
Run status "Run type" that was selected when alarm occurred. -
Run point
Point number that was selected for operation when alarm occurred. When not in
operation a 0 (zero) is entered.
-
Current Command current when alarm occurred %
Voltage Motor power voltage when alarm occurred V
Input Input information when alarm occurred -
Output Output information when alarm occurred -


 To Next Page