Adjustments and Repairs
ò These procedures are to be performed only by a qualified technician who has received
proper training and certification from the manufacturer.
Adjusting the Timing Belts
Qualified Technician Only
When you check the tension of robot arm belts, as indicated in Figure 8-1 at the
beginning of this chapter, the slack should be no greater than 2mm (0.08"). Tighten the
belts only if you are absolutely certain they are slipping or retarding the motors.
•
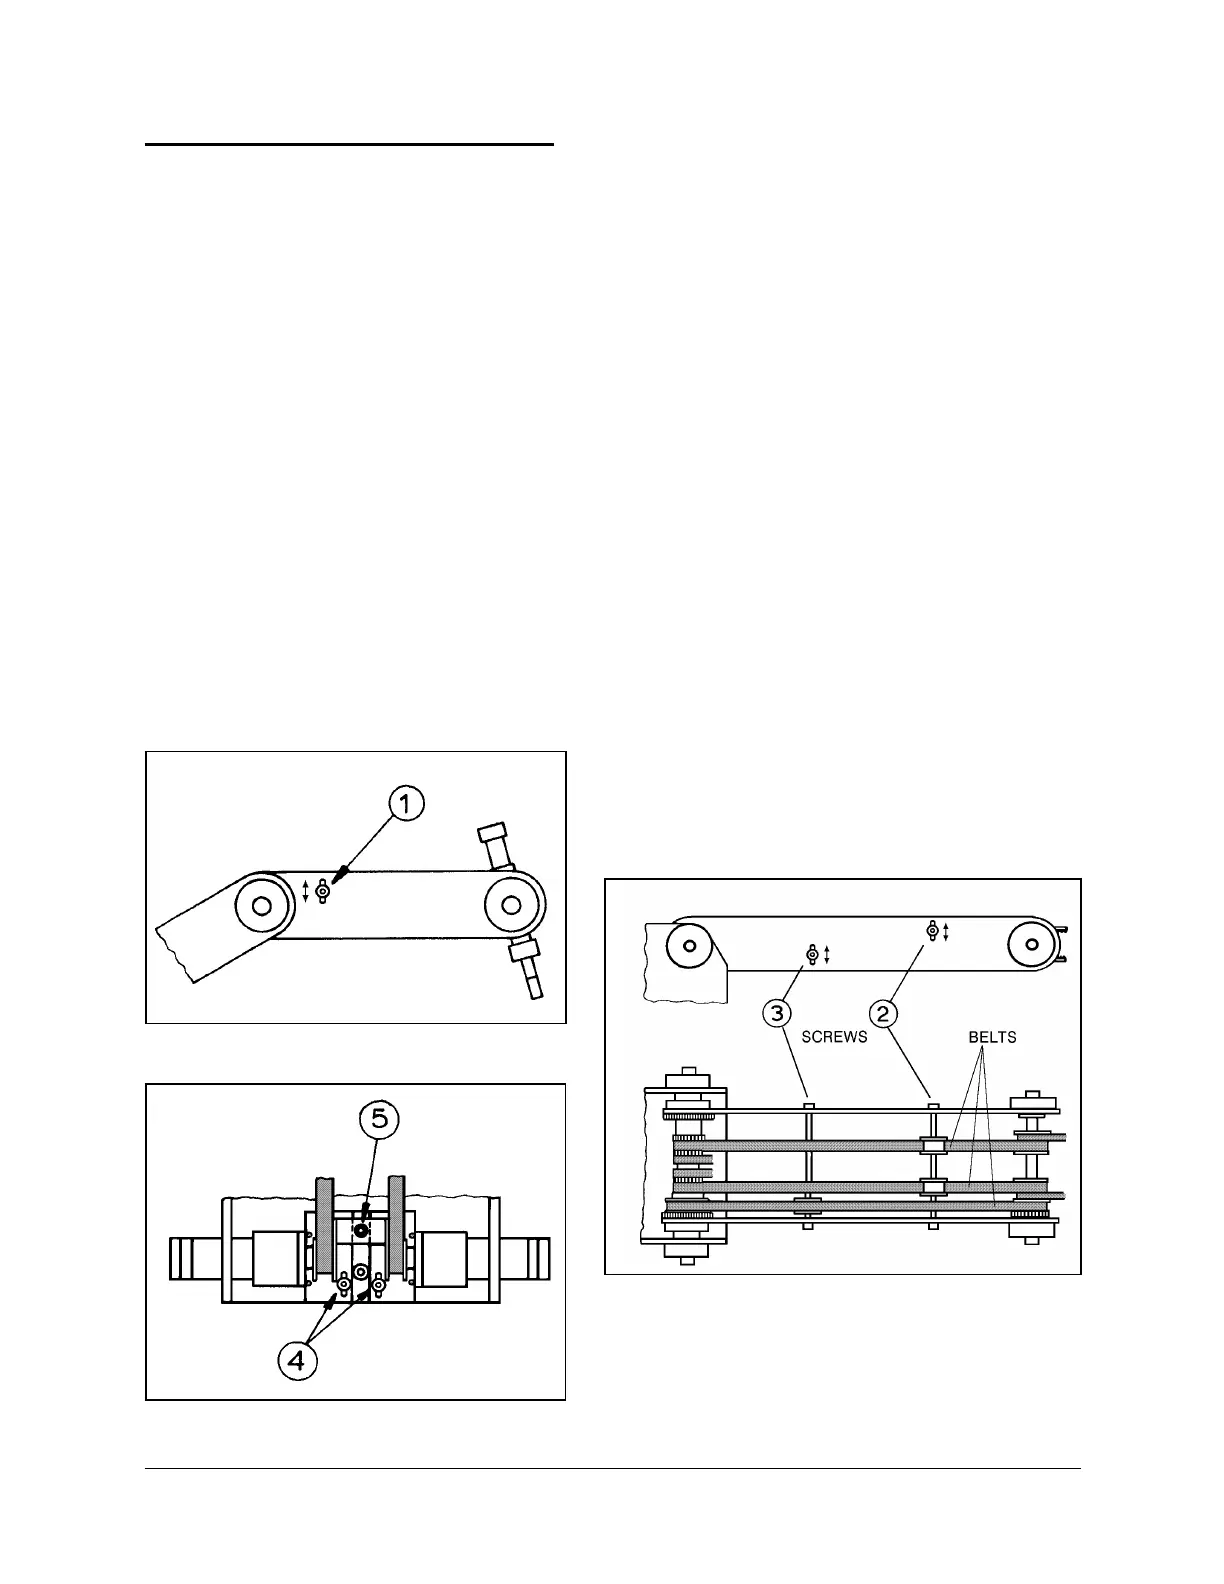
Figure 16 shows how to tighten the belts in the forearm which move the wrist axes
(pitch and roll). Loosen the two screws (1) which hold the tension shaft. Press down
on the shaft and retighten the screws.
•
Figure 17 shows how to tighten the belts in the upper arm which move the wrist axes
(2), and the belt which moves the elbow axis (3).
•
Figure 18 shows how to tighten the two belts in the robot base which move the wrist
axes. First, loosen the screw (5), and then loosen either one or both screws (4). Then,
to tighten the belts, simultaneously pull the appropriate motor and retighten screw(s)
(4). Finally, retighten screw 5.
Figure 16: Tightening Belts in Forearm
Figure 17: Tightening Belts in Upper Arm
Figure 18: Tightening Belts in Robot Base
User’s Manual 21 SCORBOT-ER 4pc
9810


 To Next Page