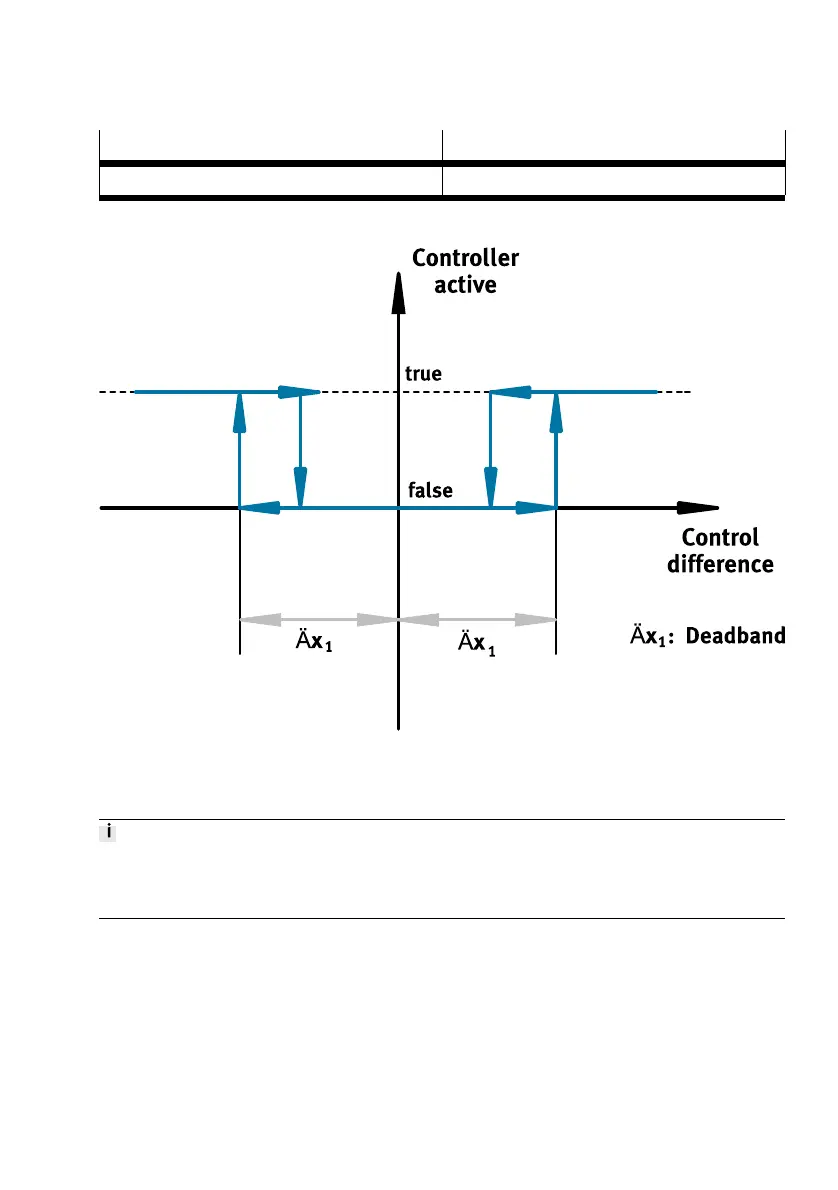
Value range Description
0.5…10.0% Factory setting:1.0%
Tab. 23
Fig. 25 Deadband
9.4.2.10 P-Gain – P-proportion of the PID controller
For most drives, the controller parameters are optimally determined during automatic initialisation.
The parameters should only be changed if the automatic initialisation cannot be carried out or does
not lead to satisfactory control behaviour.
This parameter can be used to set the P component of the PID controller. The P-proportion is the pro-
portional gain factor of a PID controller. The P-proportion influences the speed and stability of the
closed-loop control.
– The higher the value the higher the setpoint specification change in the case of a deviation.
– A P-proportion that is too high results in overshoots.
– A P-proportion that is too low slows the closed-loop control.
Commissioning
37Festo — CMSX-...-C-U-F1-... — 2019-09d


 To Next Page