SPECIAL ADJUSTMENT
7
7-13
7-2-2) Parameter setting method
Control system setting parameter #56
No. Name Setting range Initial value Change
56
Command follow-up
control selection
0: None, 1: Command follow-up control,
2: Command follow-up control
(with correction on stop)
0 Power
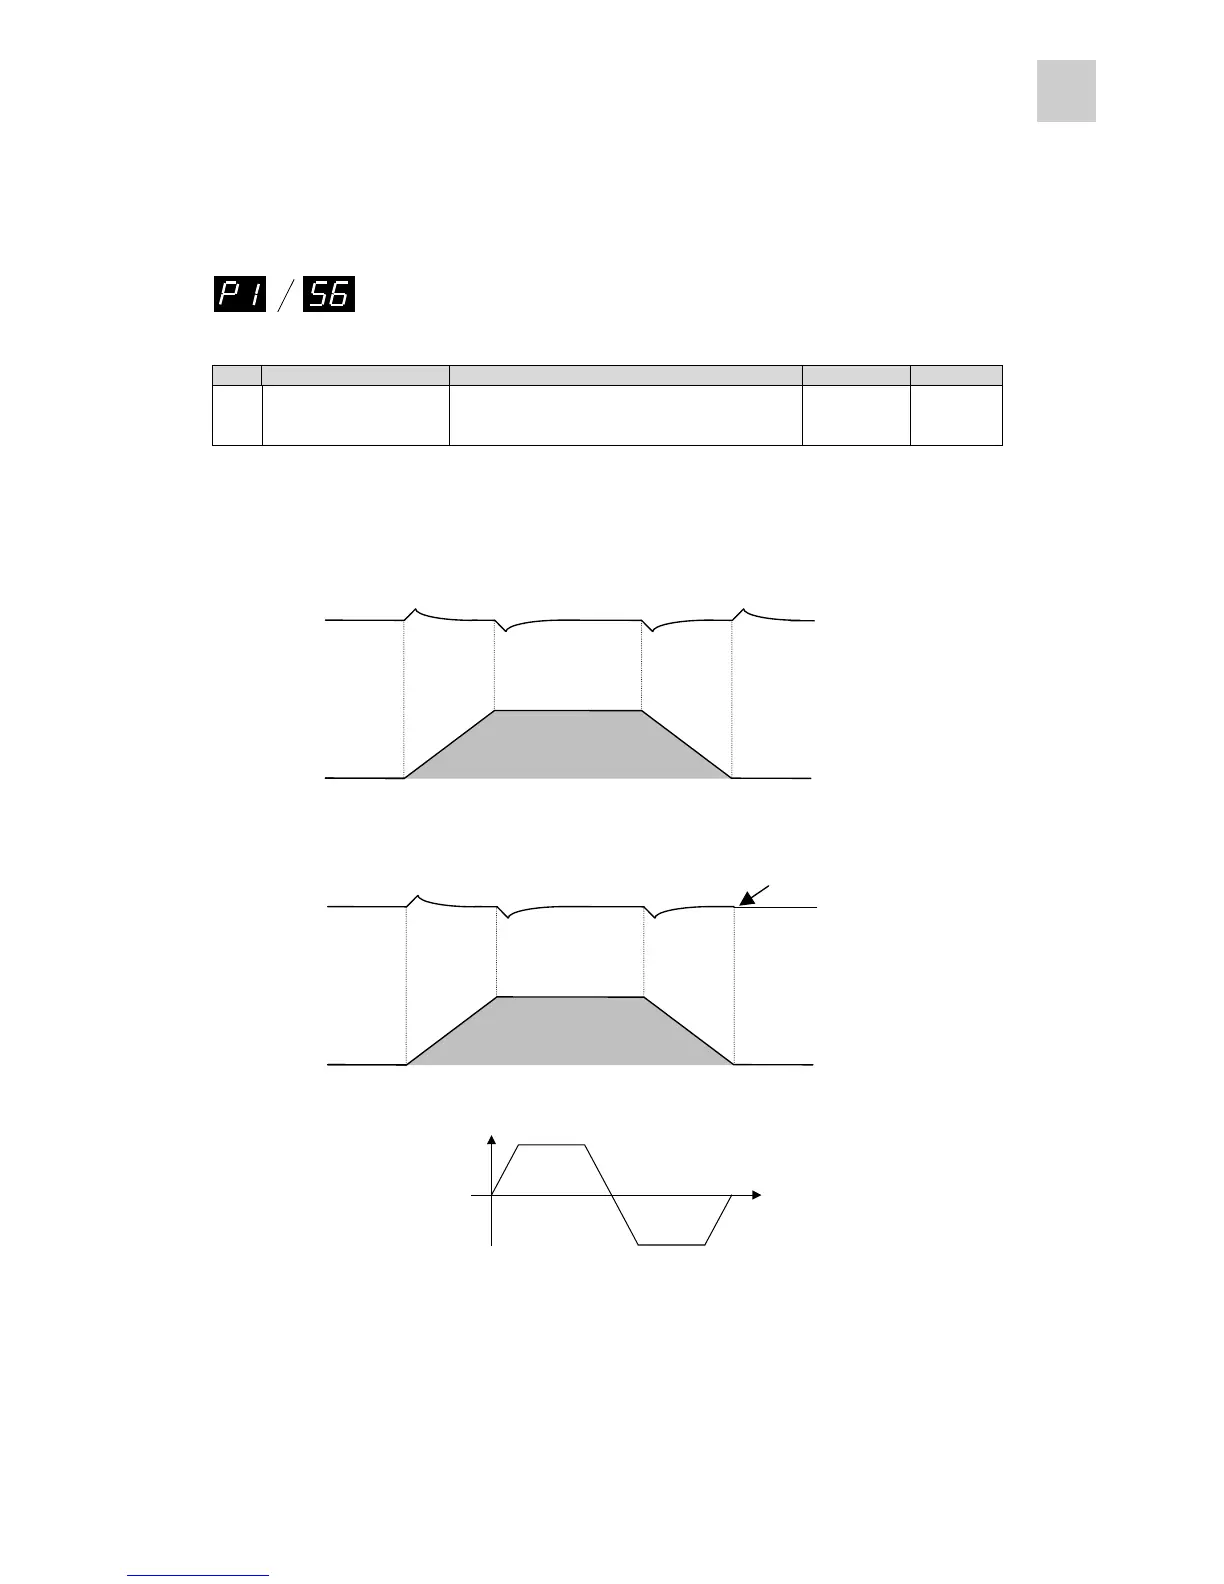
The command follow-up control includes two variations: with no correction on stop (setting: 1) and with
correction on stop (setting: 2).
Position deviation generates in both methods when the acceleration changes (at (1), (2), (3), and (4)).
In case “with correction on stop (setting: 2),” position deviation caused by the acceleration change when
the mechanical system is stopped is smaller.
Select “no correction on stop (setting: 1)” for operation patterns where changes from forward to reverse
rotation continue.
* In the command follow-up control mode, specify “10” or a larger value for the auto tuning gain
(parameter #7).
Forward
rotation
Speed
Reverse
rotation
Time
Position deviation
Command speed
Deviation of the stopping
mechanism becomes almost
zero.
Position deviation
Command speed



 To Next Page