3-32 Programming and Parameters
DYNAMIC CONTROL (File D)
Stop/Brake Modes
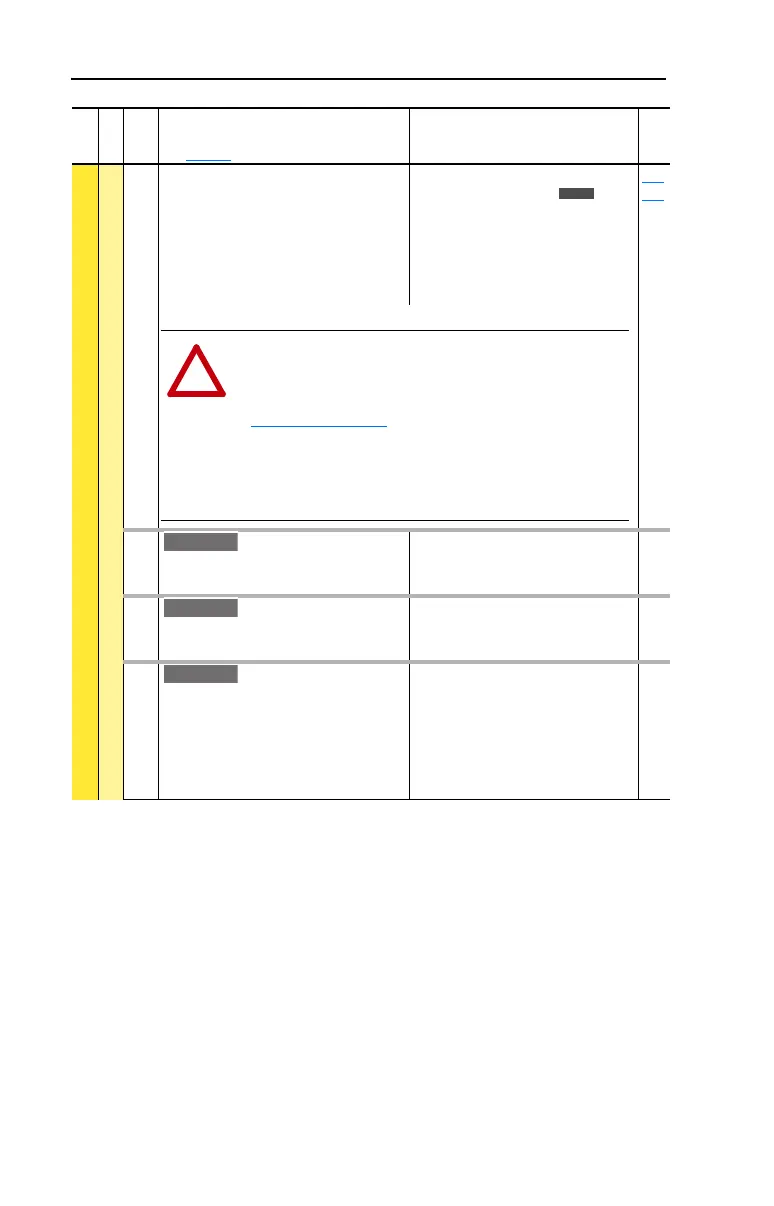
163 [DB Resistor Type]
Selects whether the internal or an
external DB resistor will be used.
If a dynamic brake resistor is connected to
the drive, [Bus Reg Mode x], A, B or Both
(if used), must be set to either option 2, 3
or 4.
Default:
Options:
0
2
0
1
2
“Internal Res”
“None”
“Internal Res”
“External Res”
“None”
161
162
164 [Bus Reg Kp]
Proportional gain for the bus regulator.
Used to adjust regulator response.
Default:
Min/Max:
Units:
1500
0/10000
1
165 [Bus Reg Kd]
Derivative gain for the bus regulator. Used
to control regulator overshoot.
Default:
Min/Max:
Units:
1000
0/10000
1
166 [Flux Braking]
Set to use an increase in the motor flux
current to increase the motor losses, and
allow a faster deceleration time when a
chopper brake or regenerative capability
is not available. Can be used as a
stopping or fast deceleration method.
Default:
Options:
0
0
1
“Disabled”
“Disabled”
“Enabled”
File D
Group
No.
Parameter Name and Description
See page 3-2 for symbol descriptions
Values
Related
E C
!
ATTENTION: The drive does not offer protection for externally
mounted brake resistors. A risk of fire exists if external braking
resistors are not protected. External resistor packages must be
self-protected from over temperature or the protective circuit shown
in Figure C.1 on page C-1
, or equivalent, must be supplied.
ATTENTION: Equipment damage may result if a drive mounted
(internal) resistor is installed and this parameter is set to “External
Res.” Thermal protection for the internal resistor will be disabled,
resulting in possible device damage.
E C
E C
E C v2



 To Next Page