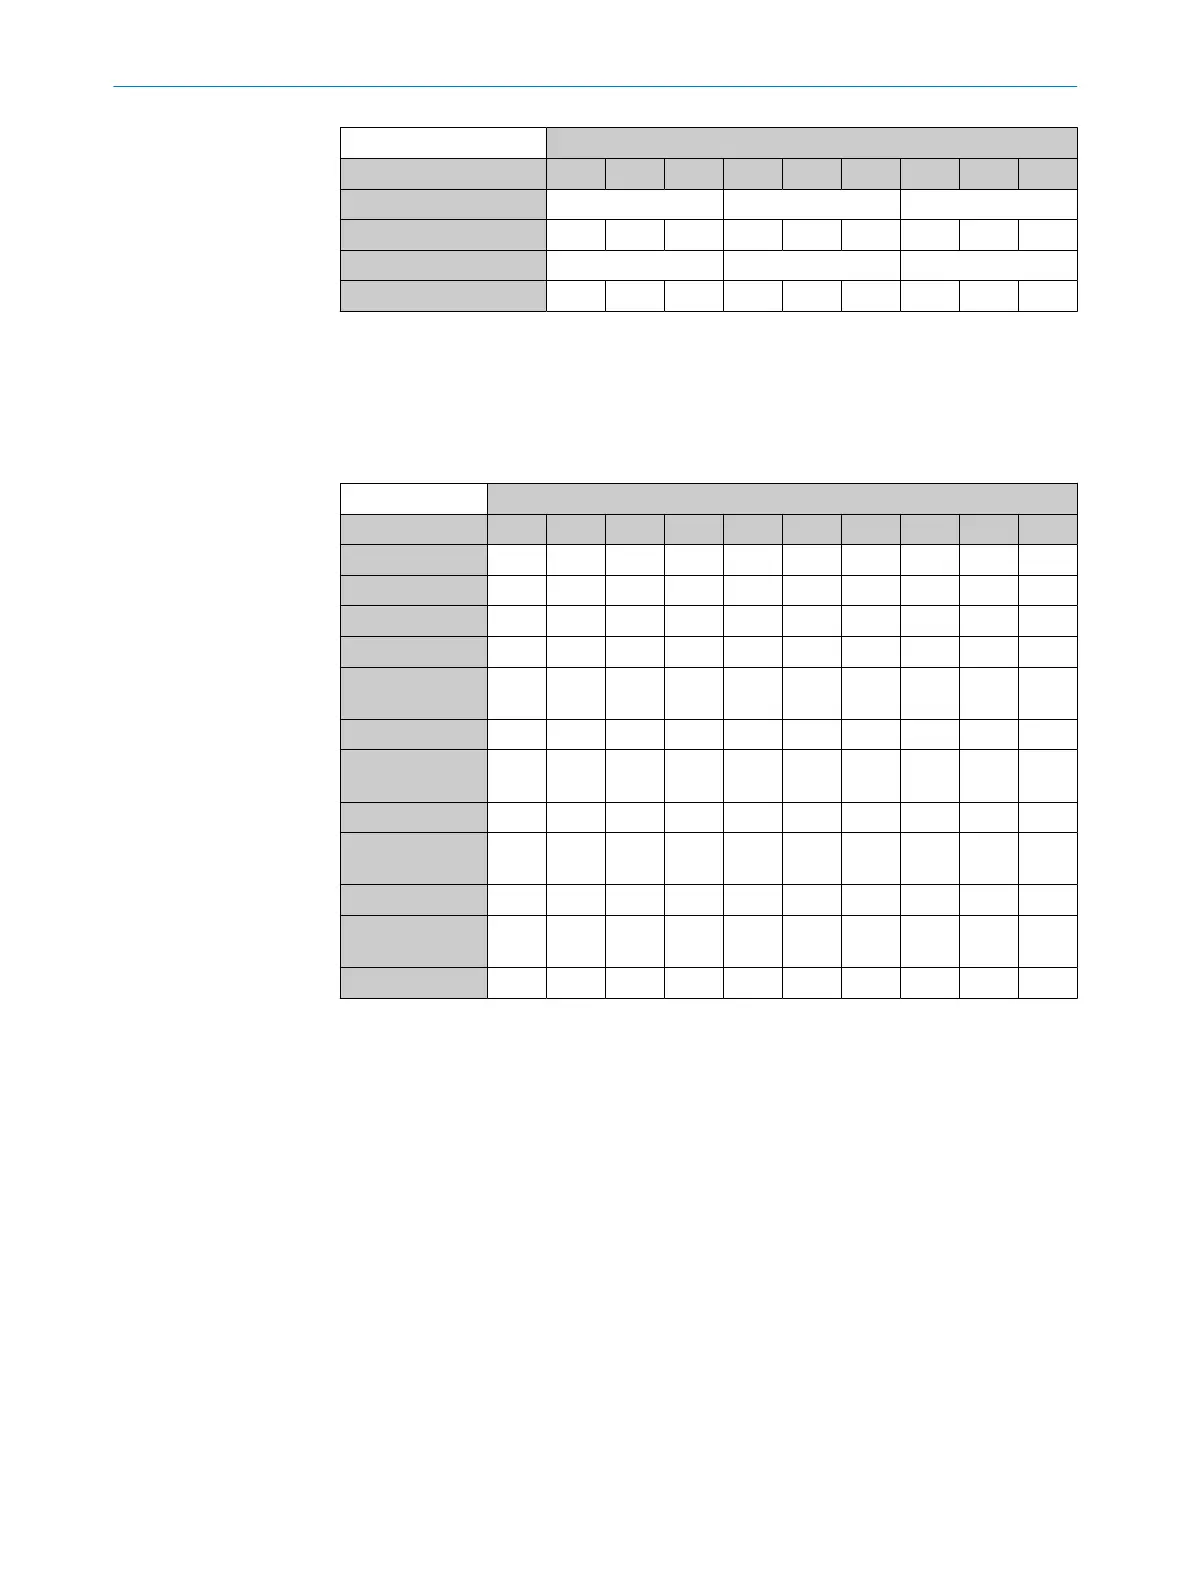
Angle (distance values in mm)
Scan 1 2 3 4 5 6 7 8 ...
Scan 1 output value 850 | 851 | 852 849 | 850 | 850 ...
2 849 850 850 853 852 852 850 851 ...
Scan 2 output value 849 | 850 | 850 852 | 852 | 852 ...
... ... ... ... ... ... ... ... ... ...
3.6.7.2 Average filter
The sliding average filter smooths the distance value. It does this by calculating the
arithmetic mean from several scans of the same point. The number of scans can be
configured (maximum 4 scans).
Table 6: Example: Average filter over 5 scans
Angle (distance values in mm)
Scan 1 2 3 4 5 6 7 8 9 …
1 0 0 1100 1100 1150 1150 1380 1380 0 …
2 0 0 1200 1200 1190 950 1500 1500 0 …
3 0 0 1150 1450 1200 1200 1450 1450 0 …
4 0 0 1170 1170 1220 1220 1470 1150 0 …
1 Output value
(scan 1-4)
0 0 1155 1230 1190 1130 1450 1370 0 …
5 0 0 0 1110 1150 1150 1380 1380 0 …
2. Output value
(scan 2-5)
0 0 1173 1225 1190 1130 1450 1370 0
6 0 0 1200 1210 1190 0 1500 1500 0 …
3. Output value
(scan 3-6)
0 0 1173 1235 1190 1190 1450 1370 0
7 0 730 1150 0 1200 1200 1450 1450 0 …
4. Output value
(4-7)
0 730 1173 1163 1190 1190 1450 1370 0
… … … … … … … … … … …
Individual outliers (shown in bold in the table) influence the average value.
Once the measured value telegram has been confirmed, the first measured value is
not output until after the configured number of scans. Therefore, there is always a time
delay equivalent to the number of scans configured for averaging. The digit of the first
scan included in the averaging calculation is always output in the scan counter. Invalid
distance values (= 0) are not included in the averaging calculation, so that in these
places a smaller number of scans is used in the division calculation.
Based on a scanning frequency of 15 Hz, a measured value is generated every 67 ms .
The time delay affecting data output results from this base value multiplied by the
number of averaging operations (e.g., 2 averagings = 134 ms, 10 averagings =670 ms).
3.6.7.3 Particle filter
The particle filter blanks small, irrelevant reflection pulses in dusty environments and
in rain or snow which are caused by dust particles, raindrops, snowflakes or the like. In
doing so, successive scans are continuously evaluated in order to detect static objects.
PRODUCT DESCRIPTION 3
8024851//2021-07-21 | SICK O P E R A T I N G I N S T R U C T I O N S | TiM3xx
21
Subject to change without notice



 To Next Page