4-125
4-3 Functions When Option PG Board (3G3AX-PG01) Is Used
4
Functions
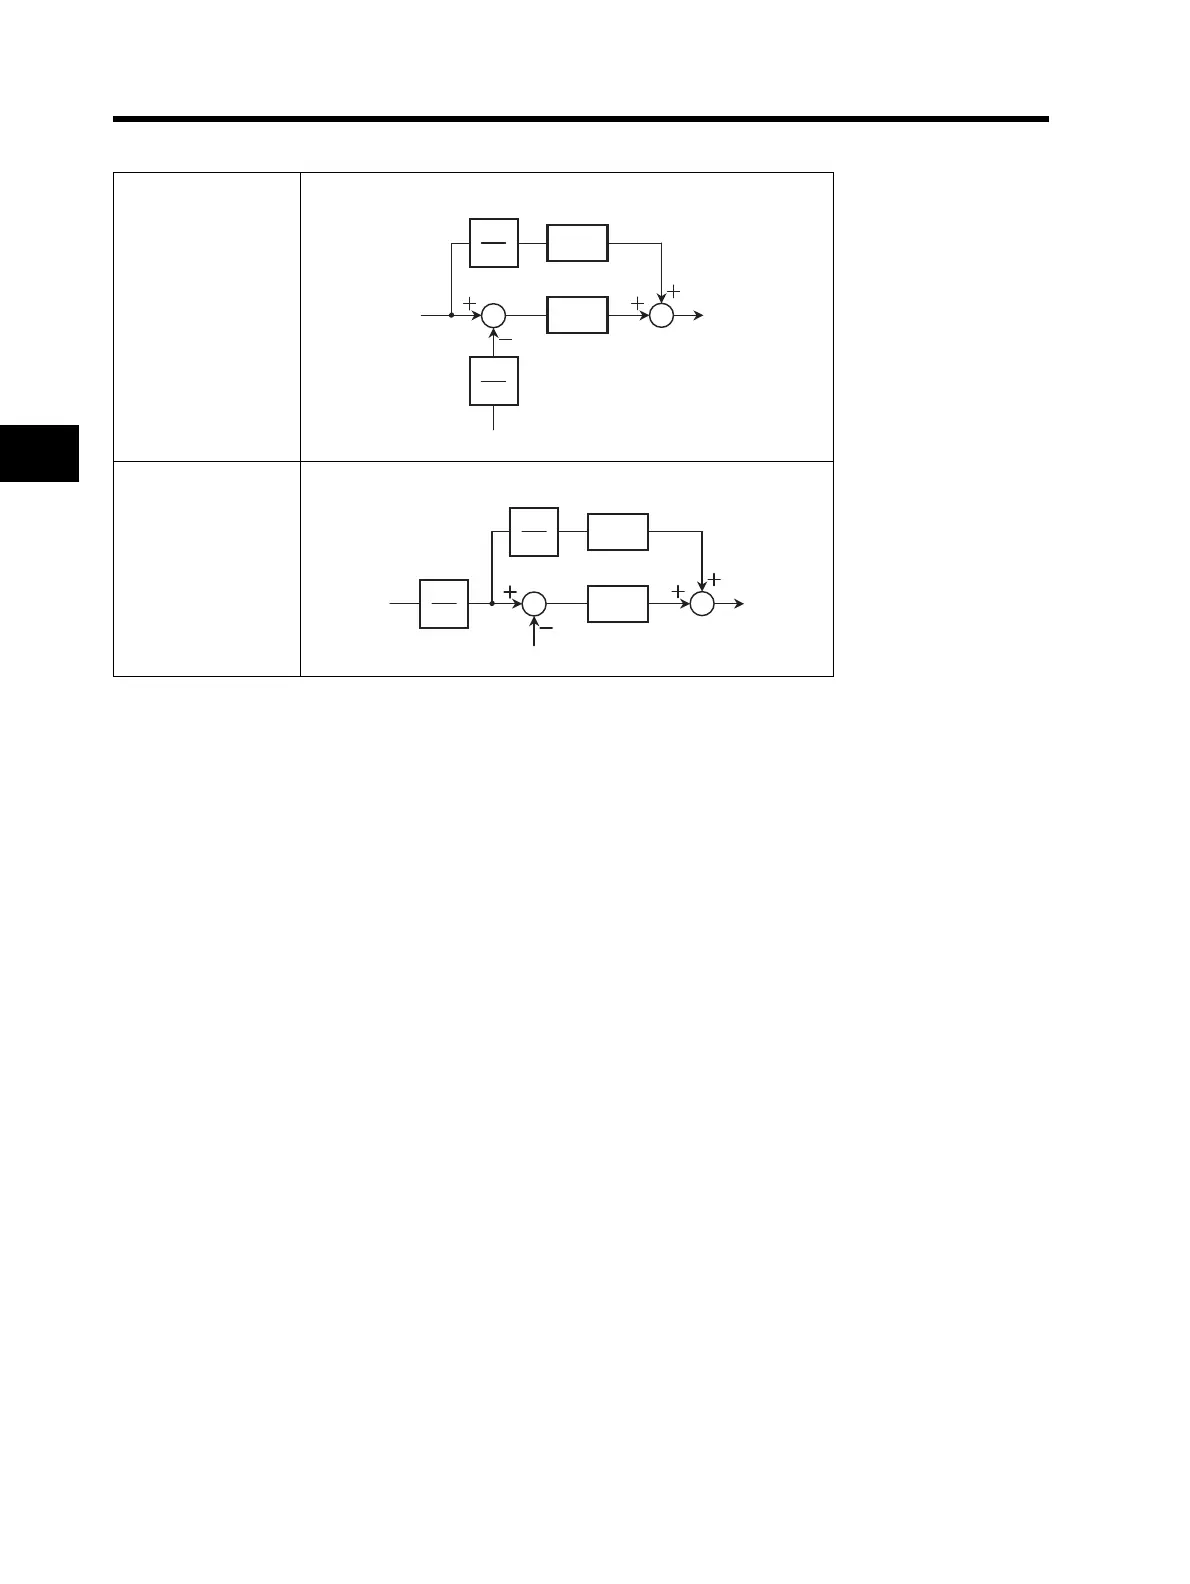
Note: Below are the block diagrams of the electronic gear function.
*1. It is recommended that position control feedfoward gain adjustment should be started with P022 = 2.00. To
reduce the position deviation between the main and sub motors, increase the feedforward gain. If motor
hunting occurs, reduce the feedforward gain.
*2. It is recommended that position loop gain adjustment should be started with P023 = 2.00. To increase
positioning accuracy and holding power, increase the position loop gain. If an increased position loop gain
causes hunting, reduce the position loop gain.
*3. Make sure that the N/D setting is within the range of 1/50 ≤ N/D ≤ 20.
(N: Electronic gear ratio numerator [P020], D: Electronic gear ratio denominator [P021])
P019 = 00 (FB)
P019 = 01 (REF)
Position
command
N
D
1
1+sT
Position feedback
Electronic gear
Position control feedforward gain
First-order lag filter
P022
P023
Speed
command
Position loop gain
Position
command
N
D
Position feedback
Electronic gear
Position control feedforward gain
P022
P023
Speed
command
Position loop gain
1
1+sT
First-order lag filter



 To Next Page