Chapter IV Operation
59
: command pulse equivalency
: encoder resolution (encoder pulse number of one round of motor shaft
rotation)
: helical pitch of ball screw
: mechanical reduction ratio (the motor rotates m rounds, the load shaft rotates n
rounds)
Electronic gear ratio
P/△l= number of instruction pulses required for one round of load shaft rotation
This system adopts for incremental encoder, because there is four-fold frequency circuit
in the system, so P
G
=4 x C, C is the pulse per rotation (also lines) of the encoder. In this
system, C=2,500, so P
G
=10,000 pulse/rotation.
The setting example of electronic gear ratio:
Example 1:
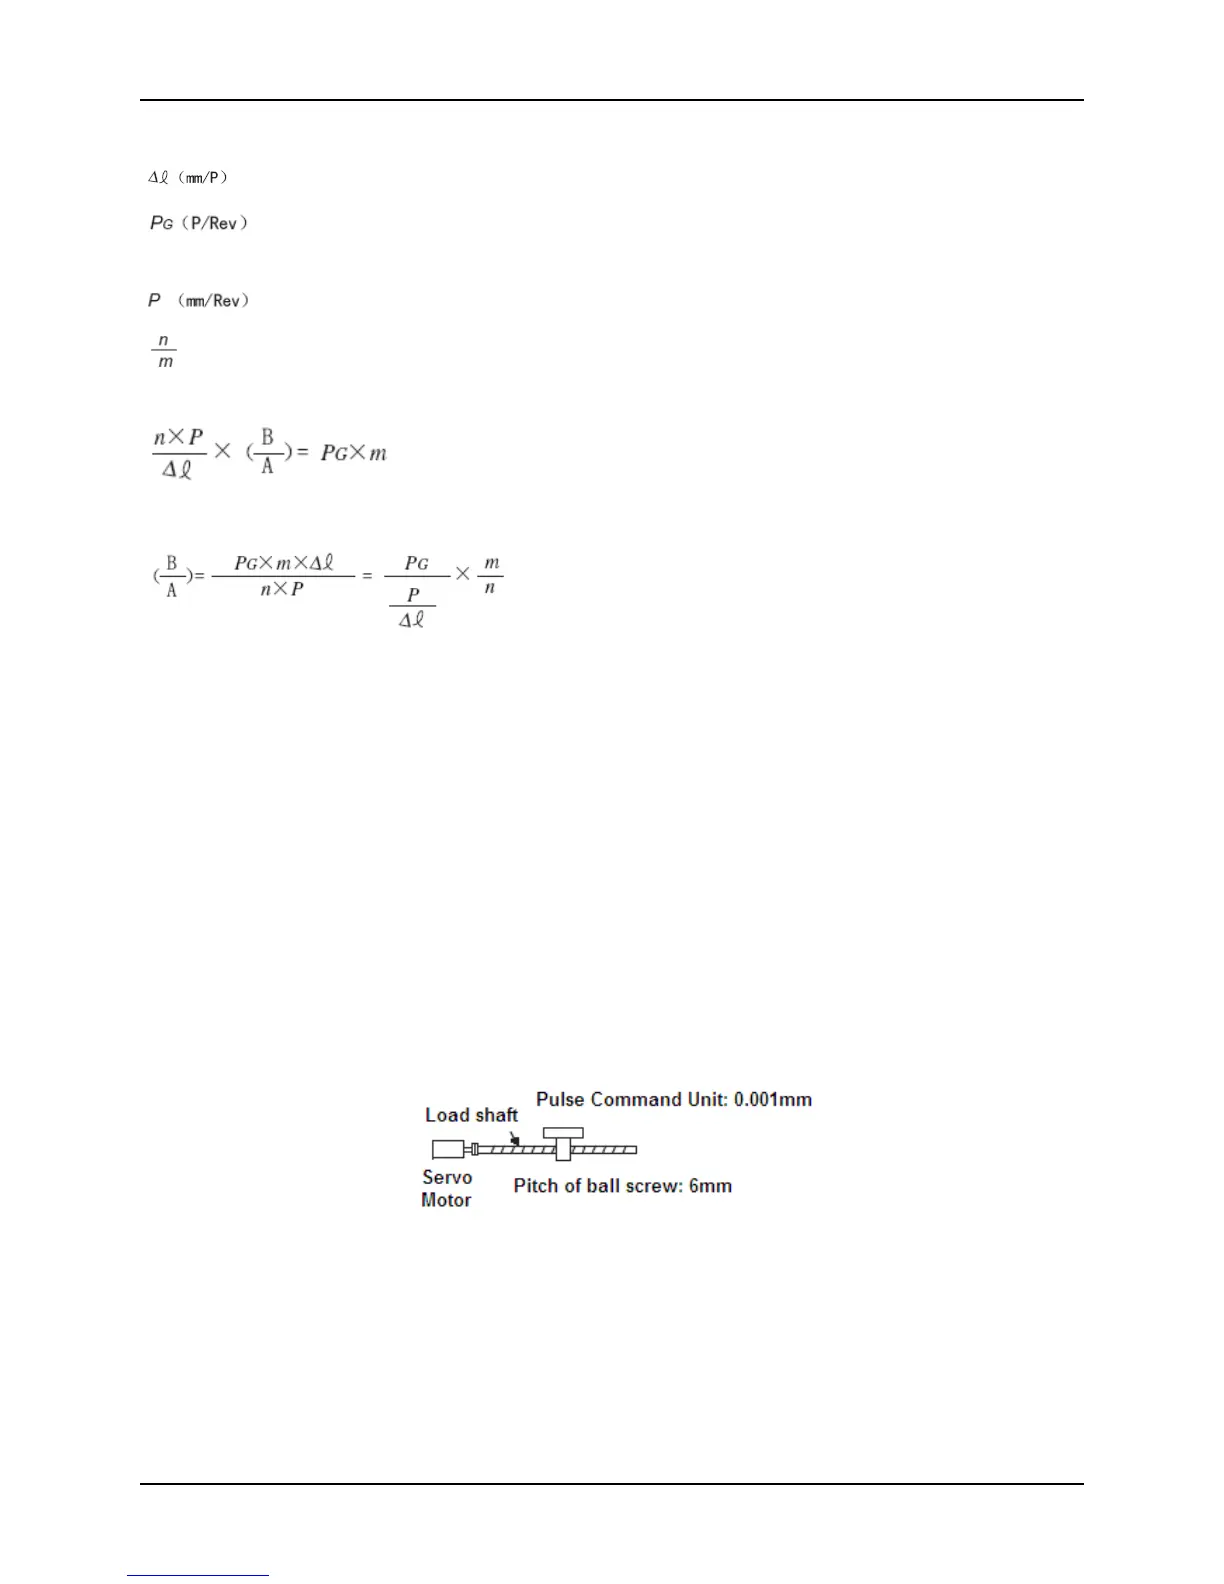
The mechanical composition is shown in the following figure:
Ball screw, the lead is 6mm, reduction ratio is 1, and the required command pulse
equivalency is 0.001mm.
Encoder resolution P
G
= 10,000 pulse/rotation
The command pulse amount of load shaft rotating one round = 6/0.001= 6,000
Electronic gear ratio B/A= 10,000/6,000= 5/3


 To Next Page