Indverter V2 Manual
Issue 03 Dated 11 November 2009 S/w Ver 12.4 HEXMOTO
Controls Pvt.Ltd
42
10. SERIAL COMMUNICATION INTERFACE
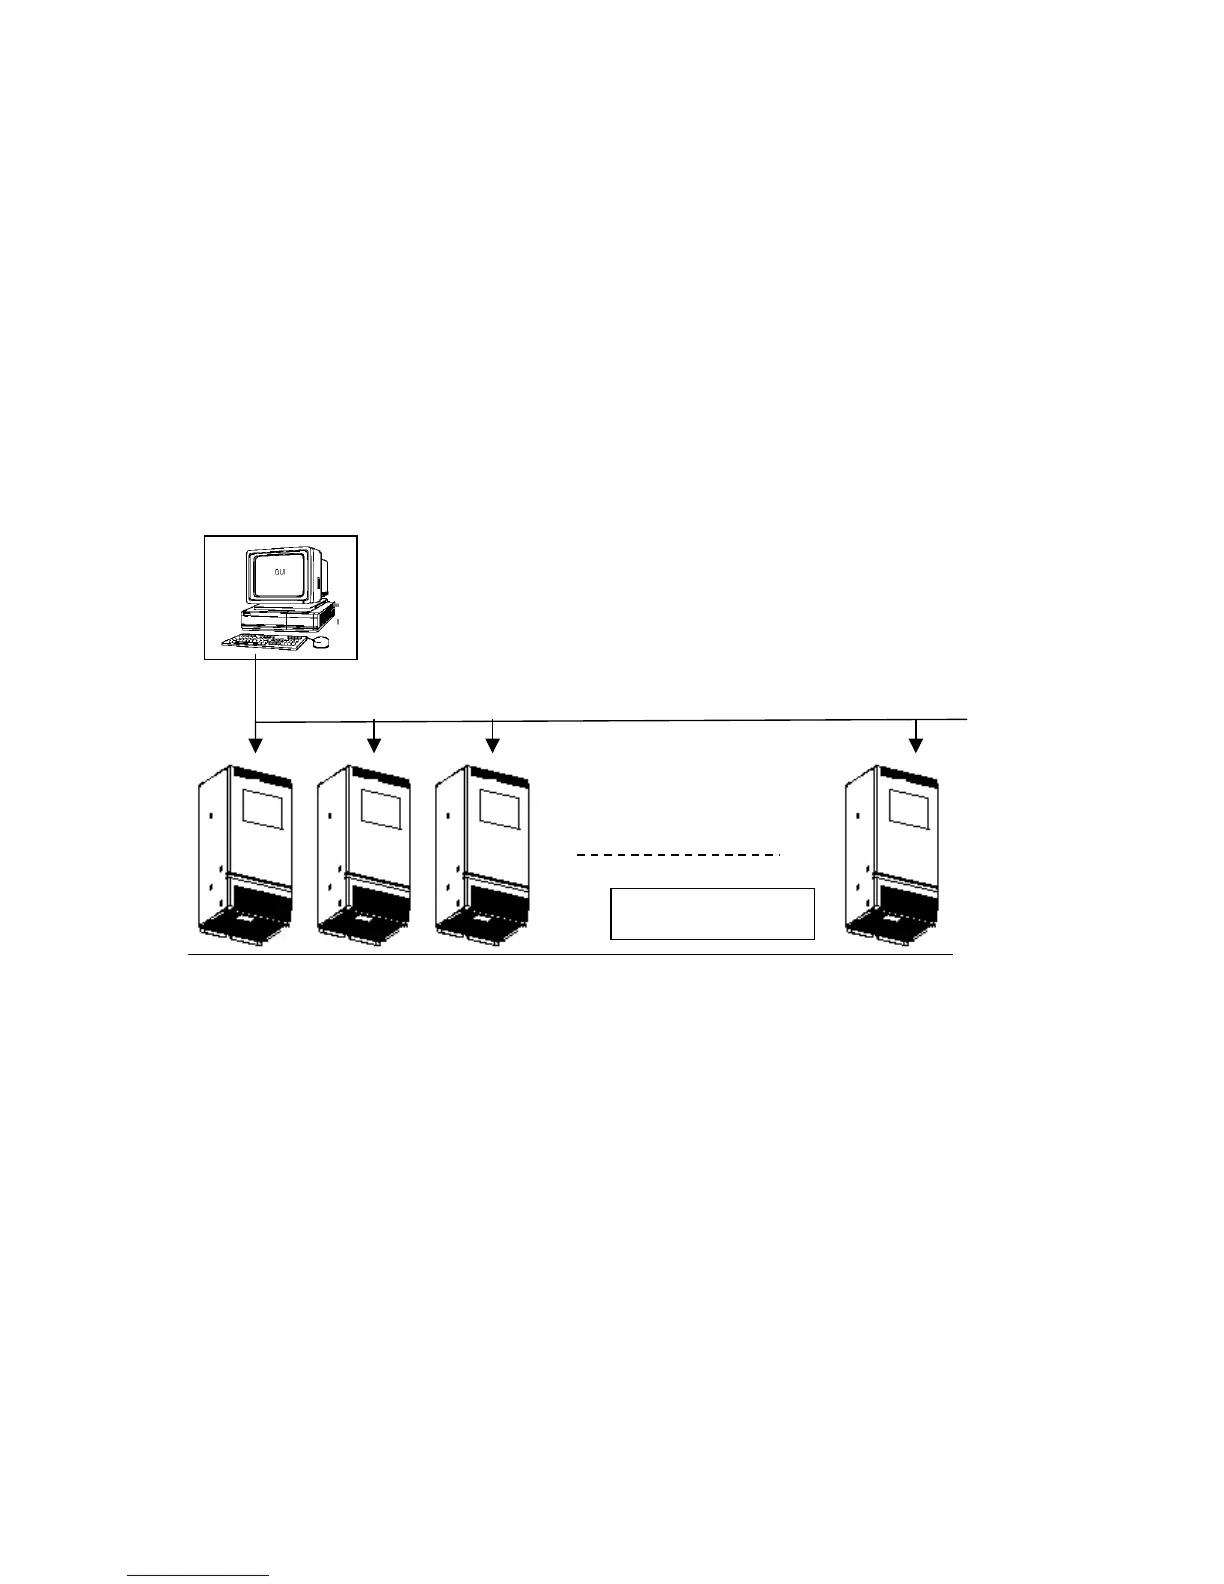
The drive controller can be remotely controlled with RS485 link provided on Connector CN3.
The communication is implemented using RS485 Serial communication with MODBUS protocol
specification version V1.1a RTU.
Usually, the drive controller works as one of the slaves to a Master PC or Host system. When programmed
as a slave using Para 66, it should be ensured that the Slave address of the controller is unique among the
other slaves. Programming 0002 in Para 66 makes drive controller as a slave with slave address 01.
A special feature of the drive controller allows the drive to work as a master controller to control other similar
drives. When configured as master using Para 66, the drive controller keeps broadcasting its Running
frequency. Other slaves can receive this broadcast data. When such system is used for synchronization
purposes, it should be ensured that all the slaves are programmed to receive the data by setting parameter
03 accordingly. Control logic for drive starting must be interfaced using Fault relay NC output to ensure that
if any one or more of the drives is faulty, all the drives operating in synchronism are disabled.
* When drive controller is configured as slave and Frequency reference to the drive is from serial
set by Para 03, AI+/ AI- analog input terminals can be used for ratio adjustments.
For detailed description of Synchronization procedure, refer to Synchronization of Drives manual
Maste


 To Next Page