EasyManua.ls Logo

OnRobot RG6 - Page 138

OnRobot RG6
198 pages
Print Icon
To Next Page IconTo Next Page
To Previous Page IconTo Previous Page
Loading...
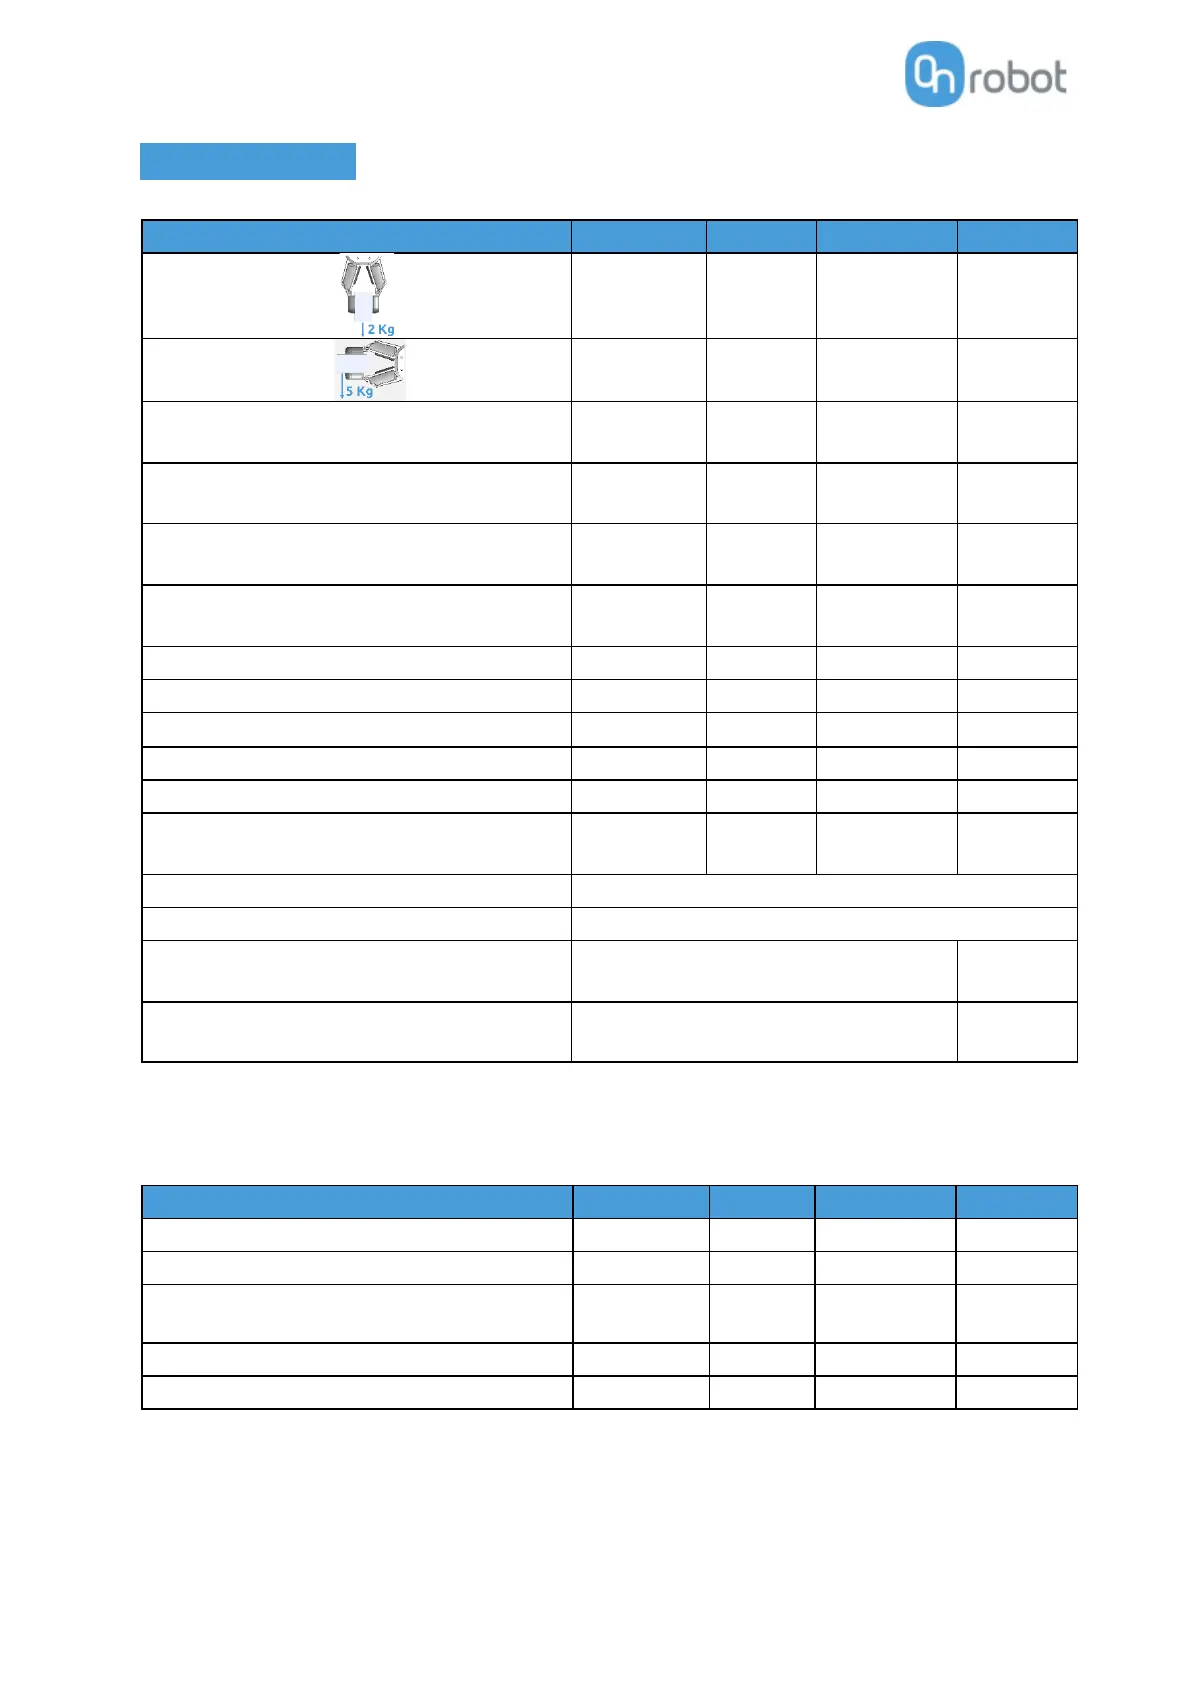
Hardware Specification
138
RG2
*See table on the next page
** based on 8mm total movement between fingers. The speed is linearly proportional to the force. For
more details see speed table on next page.
*Current spikes up to 3A (max 6mS) may occur during the release action.
General Properties
Minimum
Typical
Maximum
Unit
Payload Force Fit
-
-
-
-
2
4.4
[kg]
[lb]
Payload Form Fit
-
-
-
-
5
11
[kg]
[lb]
Total stroke (adjustable)
0
0
-
-
110
4.33
[mm]
[inch]
Finger position resolution
-
-
0.1
0.004
-
-
[mm]
[inch]
Repetition accuracy
-
-
0.1
0.004
0.2
0.007
[mm]
[inch]
Reversing backlash
0.1
0.004
-
-
0.3
0.011
[mm]
[inch]
Gripping force (adjustable)
3
-
40
[N]
Gripping force deviation
±25
%
Gripping speed*
38
-
127
[mm/s]
Gripping time**
0.06
-
0.21
[s]
Adjustable bracket tilting accuracy
-
< 1
-
°
Storage temperature
0
32
-
-
60
122
[°C]
[°F]
Motor
Integrated, electric BLDC
IP Classification
IP54
Dimensions
213 x 149 x 36
8.3 x 5.9 x 1.4
[mm]
[inch]
Weight
0.78
1.72
[kg]
[lb]
Operating Conditions
Minimum
Typical
Maximum
Unit
Power supply
20
24
25
[V]
Current consumption
70
-
600*
[mA]
Operating temperature
5
41
-
-
50
122
[°C]
[°F]
Relative humidity (non-condensing)
0
-
95
[%]
Calculated MTBF (operating life)
30.000
-
-
[Hours]
OnRobot RG6 - Page 138