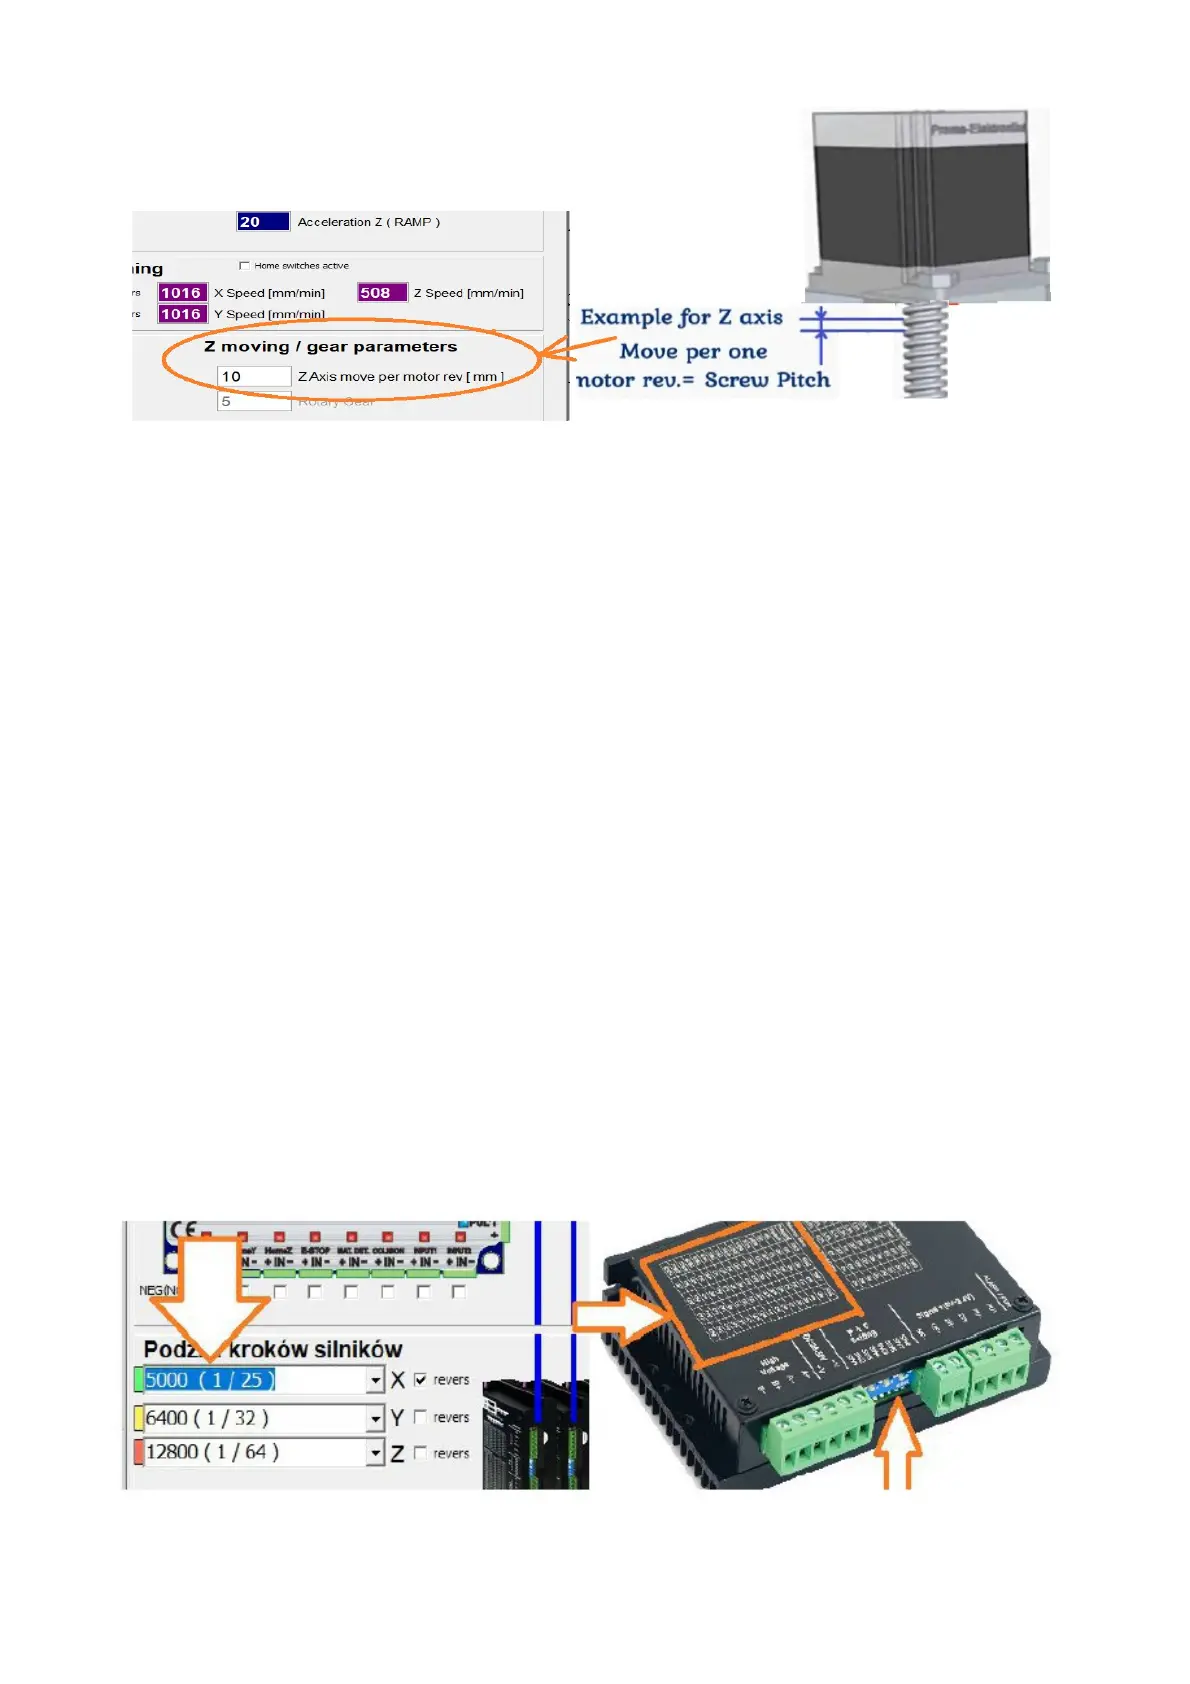
The Z axis is usually driven by a ball screw.
In the case of a screw drive, the feed rate per motor revolution is the
pitch of the screw, taking into account the gearing (if used).
5.3 Micro-stepping division
After the gear ratio parameters have been configured ( point 4.2 ),
the appropriate stepping division of the motors should be determined -
remember that the setting in the program and the configuration of the
motor controllers must be IDENTICAL.
Based on the given gear ratio parameters, the software analyses
whether the selected stepping division is optimal for the given drive
design.
Green colour: Recommended step division
Yellow : Acceptable step division
Red : Division not recommended
Please select the appropriate division (with the up/down keyboard arrows
you can conveniently move between different division values ) in the
electronics tab, then set the division identical to the one in the software on
the stepper motor driver.
Note : Some motor controllers only accept changes when the power is
switched back on.
13


 To Next Page