Chapter VI Specified Function Introduction
92
Function Description:
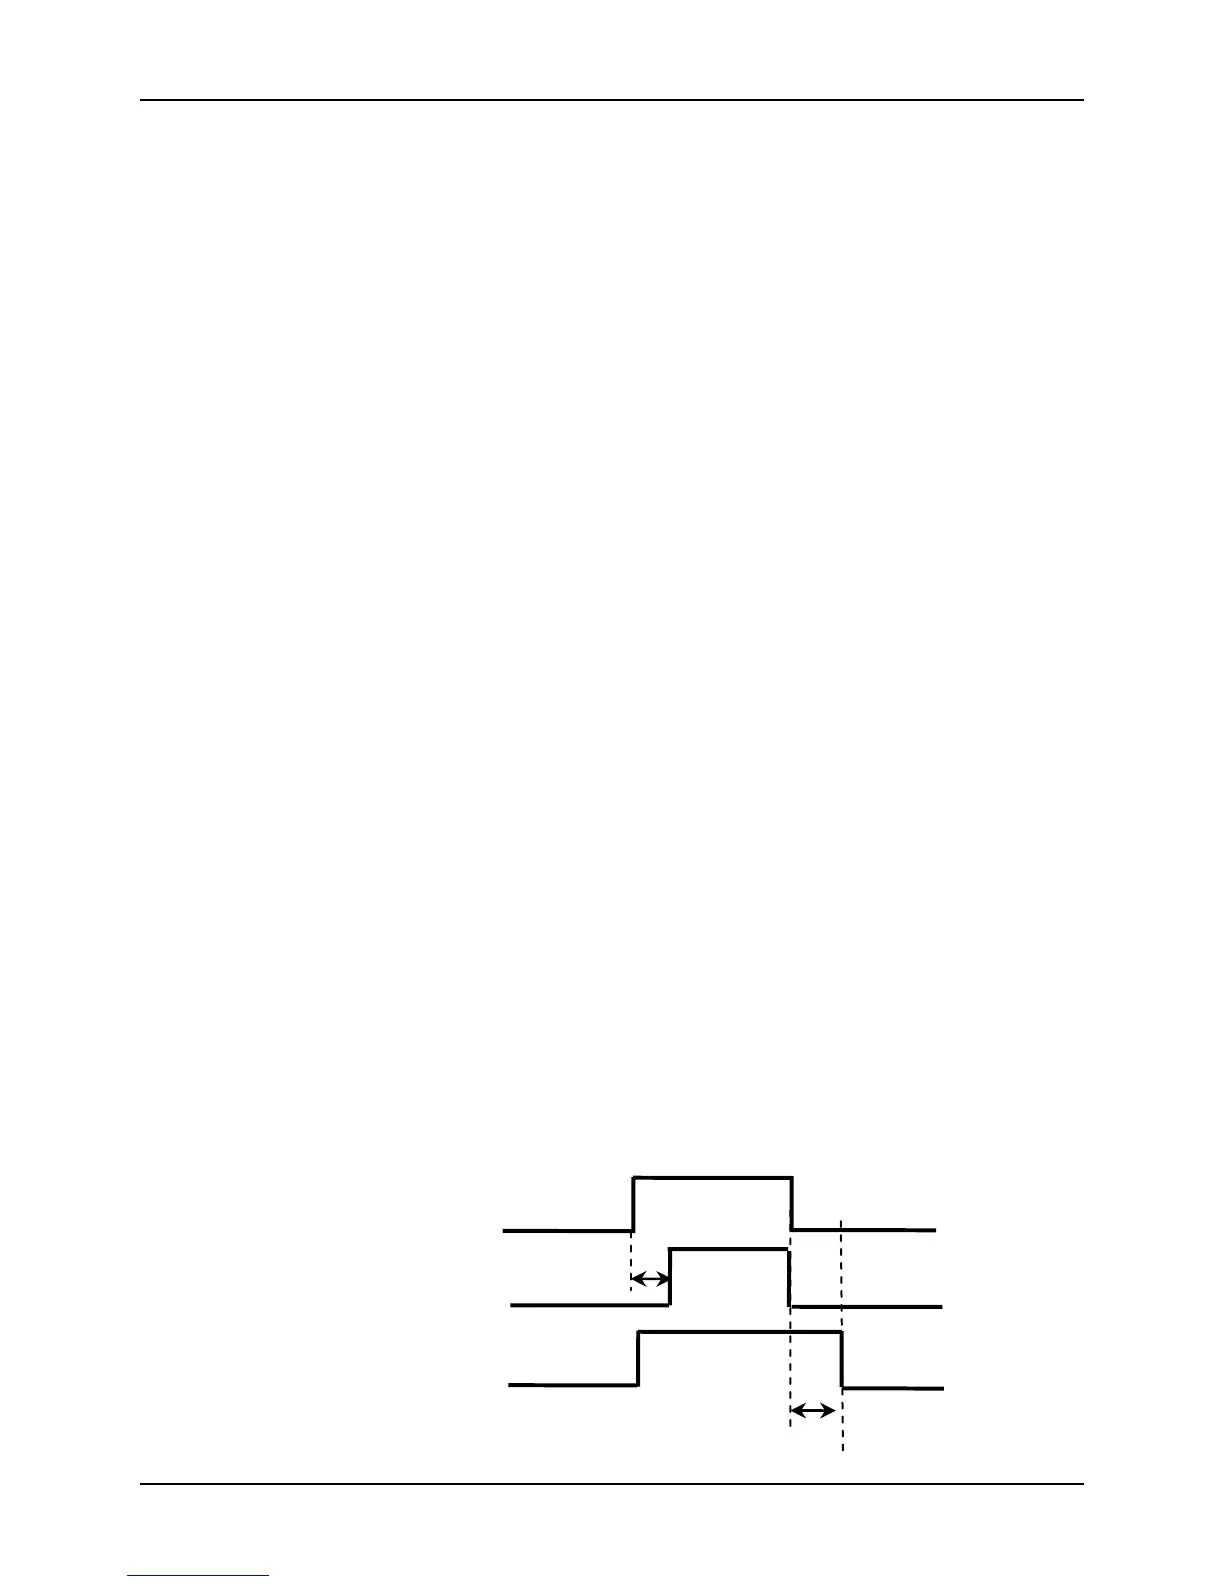
The above parameters set holding brake (electromagnetic brake) action sequence.
P01.10:
This parameter sets the speed detection value for the purpose to judge if the motor is
standstill. The setting value is used only for holding brake control. When actual speed
of motor is below this setting, the motor is judged to be standstill, conversely the motor
is judged to be in operation.
P01.11:
This parameter sets the delay time for holding brake released to servo off.
This parameter prevents tiny displacement or falling down of work piece due to motor
shaft’s movement during brake action. Setting value should be slightly greater than the
mechanical brake's delay time.
P01.12:
This parameter sets the speed of running motor to activate holding brake., this
parameter setting value should be greater than P01.10 setting value.
This parameter is to make the motor speed down to a low speed and then make the
brake action to avoid damaging the brake.
P01.13:
This parameter sets the waiting time from motor disenabled to brake action. This
parameter is to make the motor speed down to a low speed and then make the brake
action to avoid damaging the brake.
The actual action time of the brake is subject to the first meet the conditions of time in
P01.12 and P01.13.
The brake action sequence diagram:
■ The motor is in the stopping state (that the actual motor speed is lower than
P01.10 setting value), the brake action sequence is as follows:


 To Next Page