240 Version: 1.2.1 MS249E C-863.12 Mercury Controller
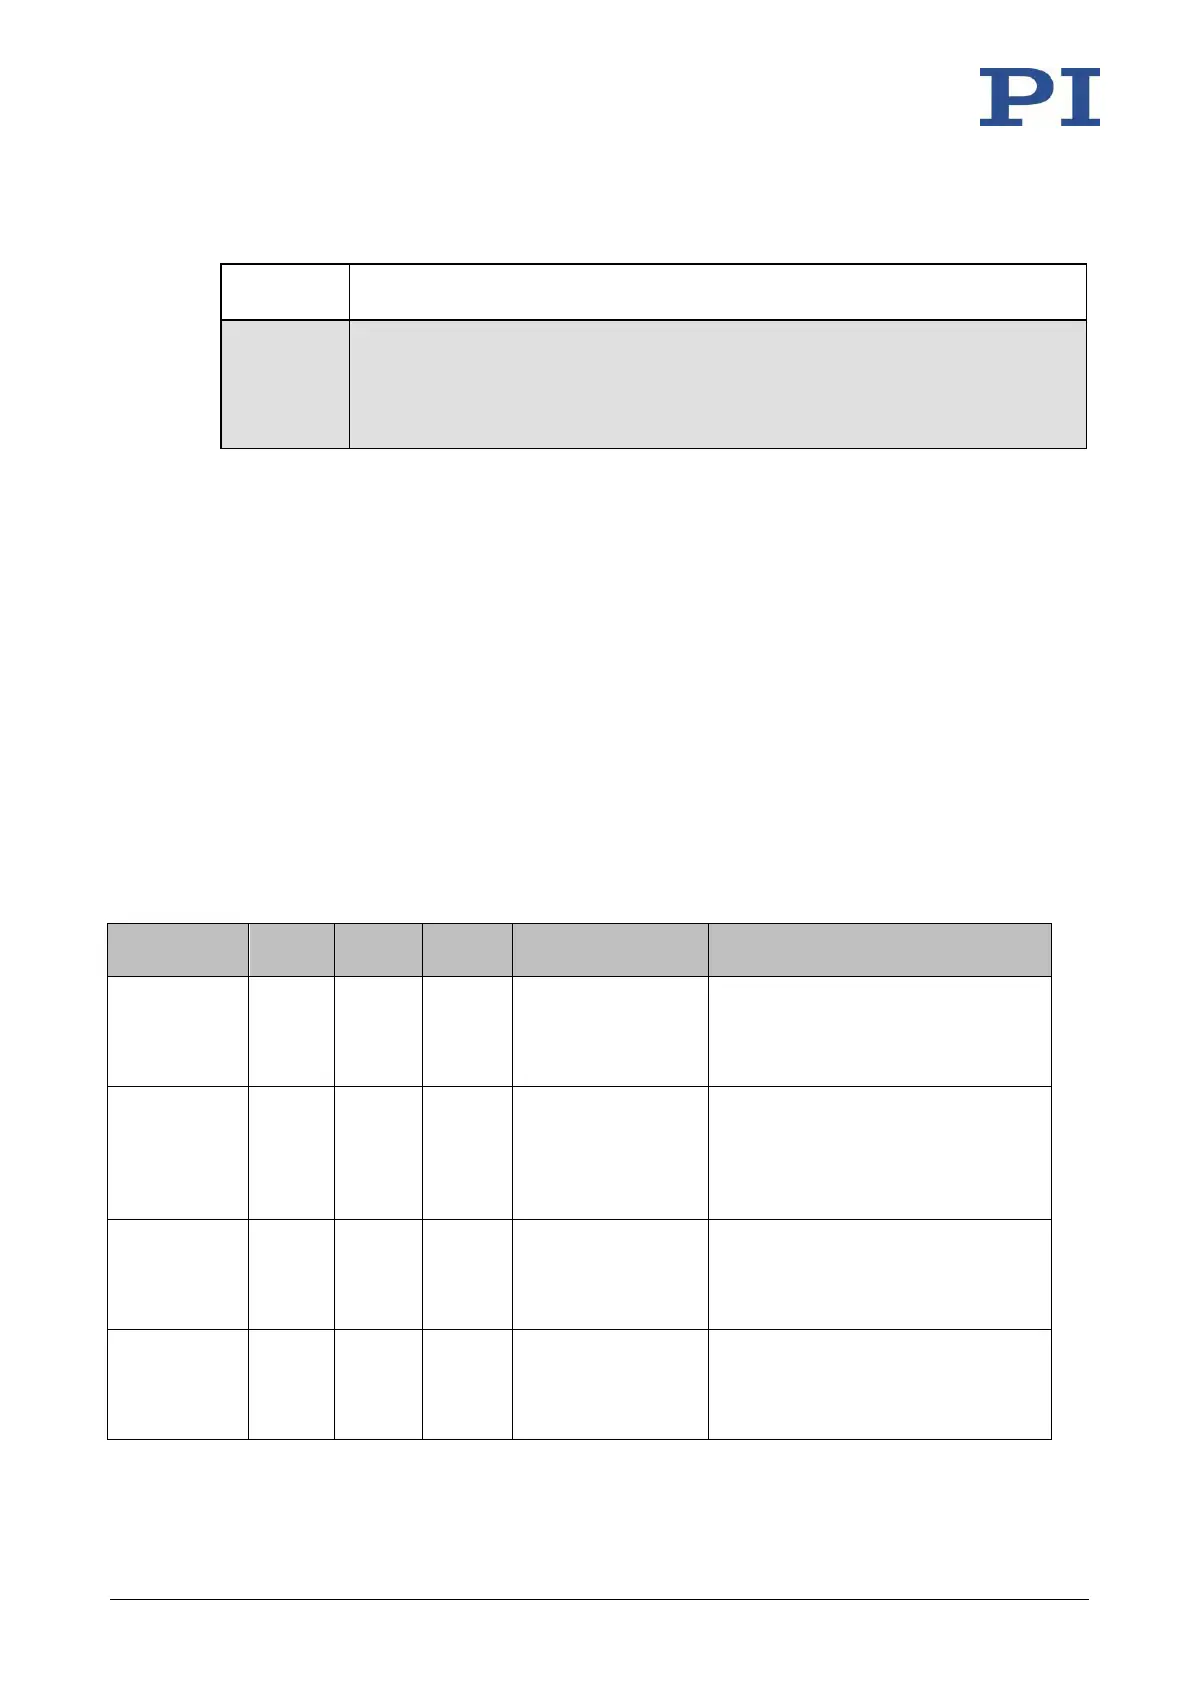
Meaning of the color highlight in the parameter table:
The value of the parameter can be loaded from a positioner database (p. 36).
The value of the parameter is from one of the following sources:
▪ Factory default setting
▪ Set by the controller during runtime and read only
▪ Read from the ID chip of the positioner (for future use)
Designations in the header of the following table:
▪ ID = Parameter ID, hexadecimal format
▪ Type = Data type:
− INT = integer value, including Boolean values
− FLOAT = floating point number
− CHAR = String format
▪ CL = Command Level for write access
▪ Element = Element type to which the parameter refers, for more information, see
"Commandable Items" (p. 12)
▪ Parameter name = Name of the parameter
▪ Description = Explanation of the parameter
Maximum Position
Error (Phys. Unit)
Maximum position error
Is used for detecting motion errors.
For details, see "Motion Errors" (p.
73).
Maximum permissible absolute
amount of the control value
(dimensionless)
For details, see "Motor Control" (p.
11).
Maximum Closed-
Loop Velocity (Phys.
Unit/s)
Maximum velocity in closed-loop
operation
Specifies the maximum value for
parameter 0x49.
Closed-Loop
Acceleration (Phys.
Unit/s
2
)
Acceleration in closed-loop
operation
Limited by parameter 0x4A.
For details, see "Generation of


 To Next Page