Chapter 3 G Command
49
I Programming
Format
:
G30 P2 X_ Y_ Z_ ; the machine 2nd reference point return (P2 can be omitted)
G30
P3 X_ Y_
Z_ ; the machine 3rd reference point return
G30 P4 X_ Y_ Z_ ; the machine 4th reference point return
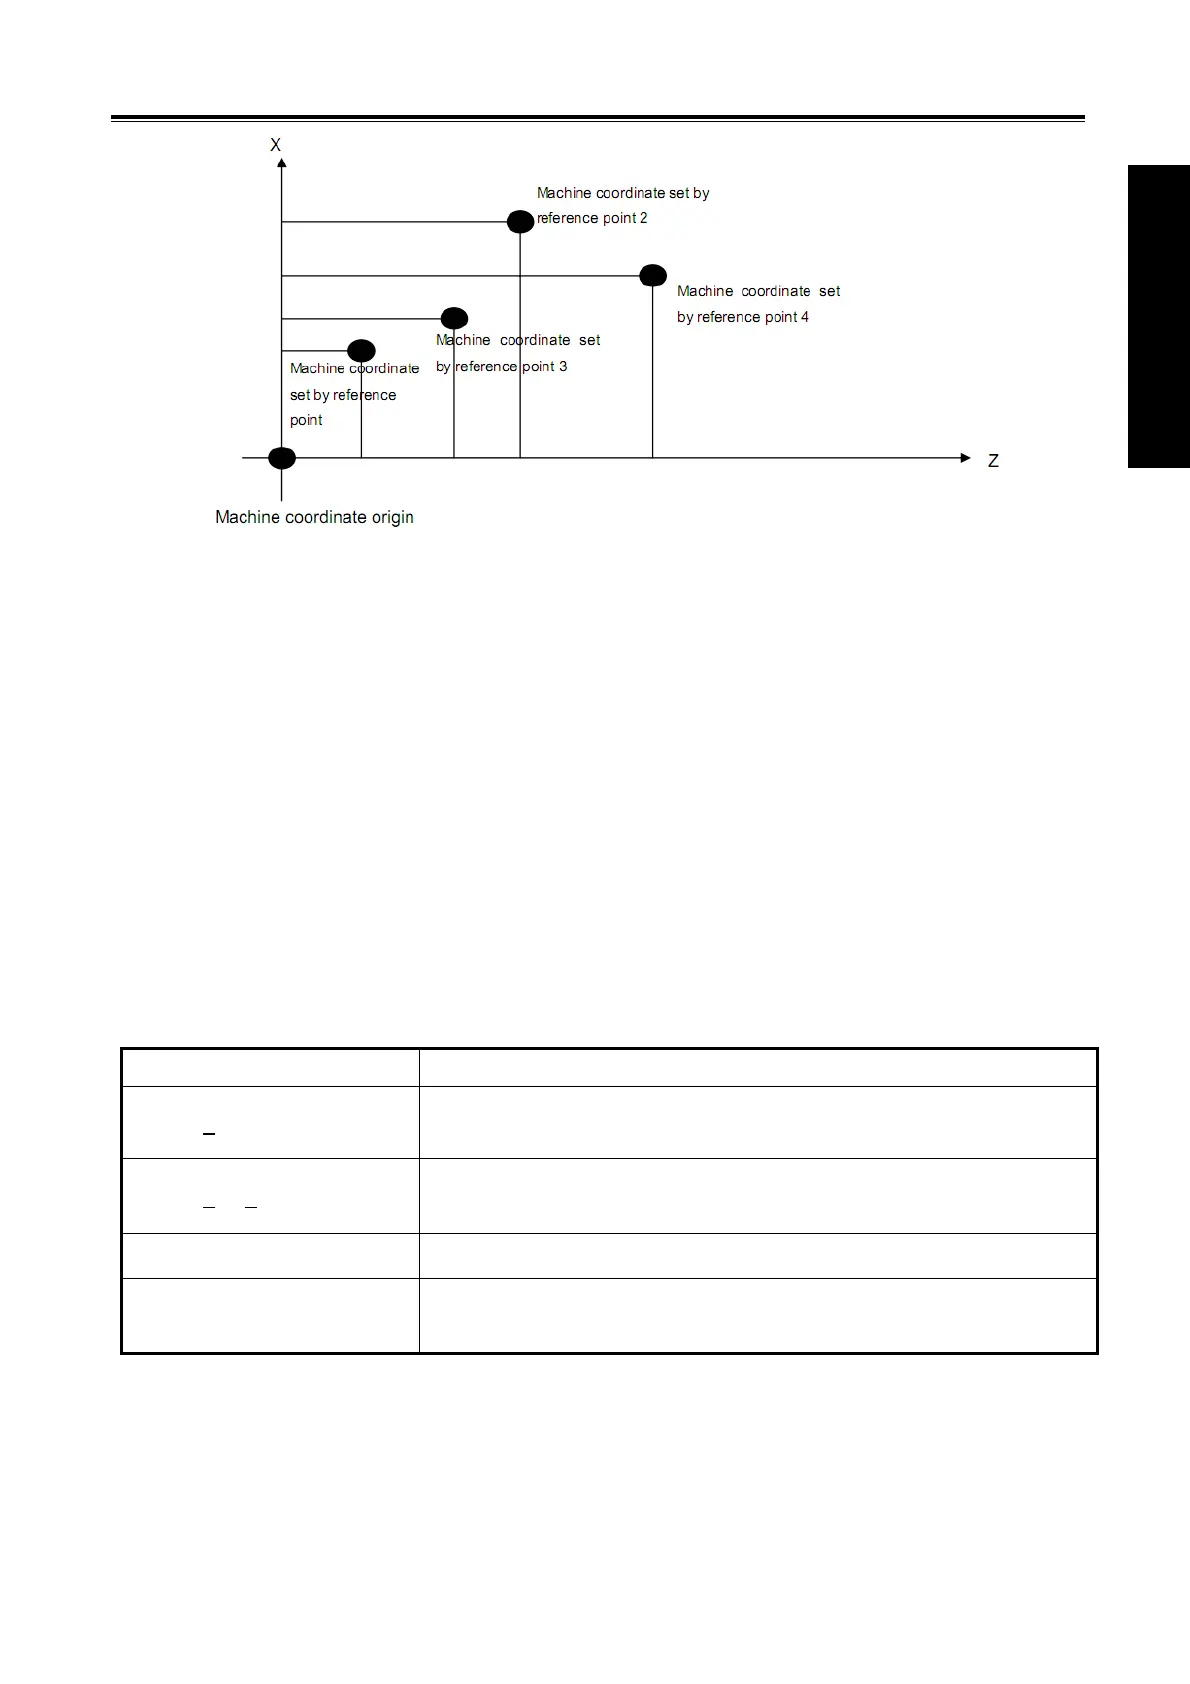
Function: From the start point, after the intermediate point by X, Y and Z is reached at a rapid
traverse rate, the machine 2
nd
, 3
rd
and 4
th
reference points are returned. The
command word P2 can be omitted
when the machine 2
nd
reference point is returned.
Explanation: G30, which is a non-modal G-command;
X:
X axis coordinate for intermediate point;
Y: Y axis coordinate for intermediate point;
Z:
Z axis coordinate for intermediate point;
One of the command address X, Y and Z or all of them can be omitted, see the following
figure:
Command Function
G30 Pn X
Machine n
th
reference point return for X axis, Y and Z axes in the
original position
G30 Pn Y_ Z_
Machine n
th
reference point return for Y and Z axes, X axis in the
original position
G30
3 axes in the original position, the next block continued
G30 Pn X_ Y_ Z _
X, Y and Z axes return to the machine n
th
reference point
simultaneously.
Note 1: n is 2, 3 or 4 in above table;
Note 2: Deceleration and zero signals check are not needed when 2
nd
, 3
rd
and 4
th
reference points return
is performed.
Command action process (see the following figure, an instance of machine 2
nd
reference point return):
(1) Positioning to intermediate point of the specified axis from current position at a rapid traverse rate
(from point A to point B);


 To Next Page