SuZhou Eshine Elevator Components Co., Ltd. Chapter 4 Function Introduction
YS-K01 Door Controller User Manual ―39―
4.7 Group P6 Advanced Parameters
Code Name Description Range
factory setting
PC1, PC2, DPA output selection
0: The signal is open which represents the OD/CD arrival and door position output (equal to the relay
normally open contact).
1: The signal is closed which represents the OD/CD arrival and door position output (equal to the
relay normally closed contact).
0: Door position output.
1: The re-open signal is output at the CD resistance.
Door position output setting
When the door position is excess to this function setting value, the door position output signal (DPA) is
enabled.
• Only when set P6.01 as 0 (door position output) can this function be enabled.
Dec time of open & close resistance
This function parameter define the Dec time from the present CD speed decelerating to zero speed
when the CD resistance occurs.
• If the setting is too small, it will result in door seriously shaking when decelerates; If the setting is
too big, it will result in too slow decelerating speed.
Open & close holding time on demo mode
Defines the holding time of OD or CD arrival on the demo mode (P0.06 = 2).
Mode selection on open & close invalidation
0: Holding the torque at the OD&CD arrival range, but zero-speed running at other position.
1: Stop running.
2: Only holding the torque at the OD&CD arrival range.
Torque setting on open&close invalidation
When set P6.05 as 0, the special torque will be output to prevent the door from moving.
4.8 Group P7 Vector Control Parameters
Code Name Description Range
factory setting
P7.00 High speed ASR KP 10
3000
350
P7.02 Low speed ASR KP 10
3000
350
P7.04 ASR switching frequency 0.00
P0.07
8.00Hz
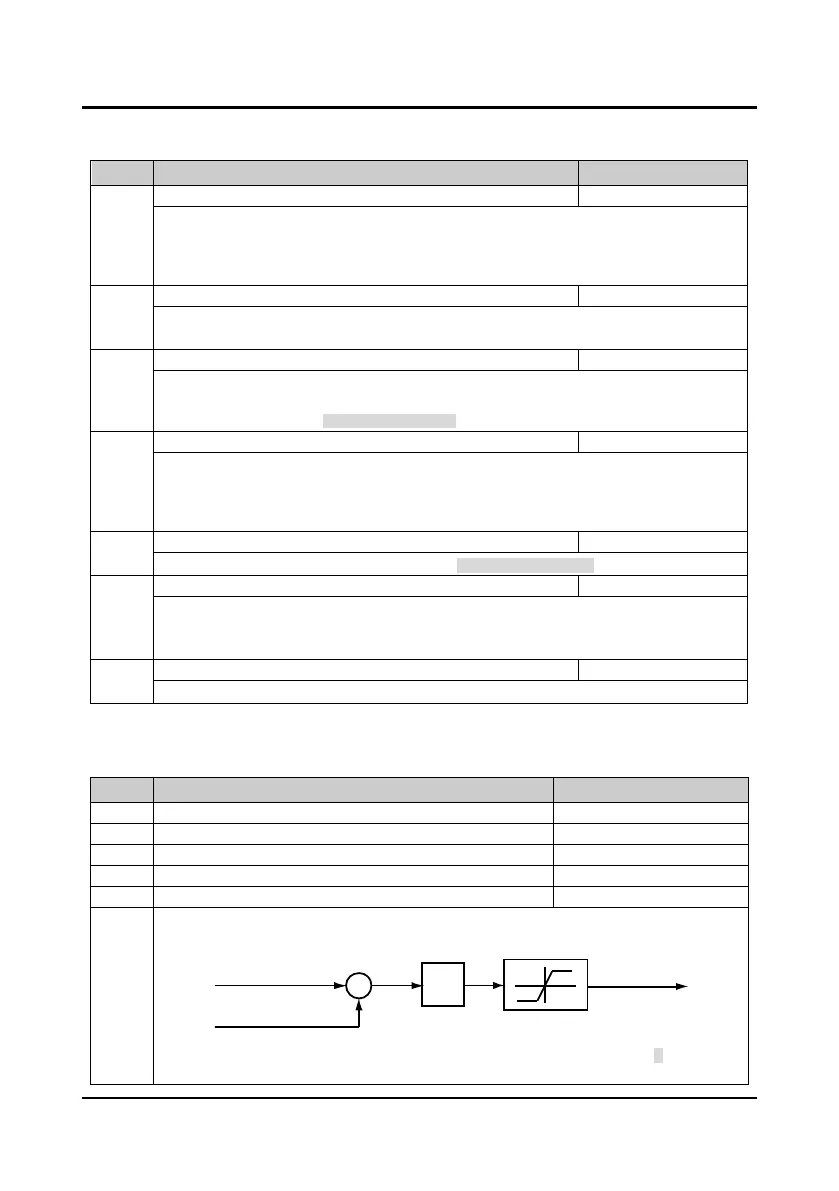
The parameters of P7.00-P7.04 comfirm the PID parameters of ASR. The structure of ASR is shown
in figure.
• The system’s response can be expedited through increasing the proportional gain P, but
oscillation may occur if the value of P is too high.
Torque current
setting
Frequency command
+
-
Frequency feedback
PID
Error
Torque limit



 To Next Page