PY Manual Copyright © 2006 SANYO DENKI AMERICA, Inc.
89
Deceleration Time Tvde
Remote Operator Mode:
0
Page:
11
Default Value:
0 ms
Function:
CMD
Setting Range:
0 to 9999 ms
Description:
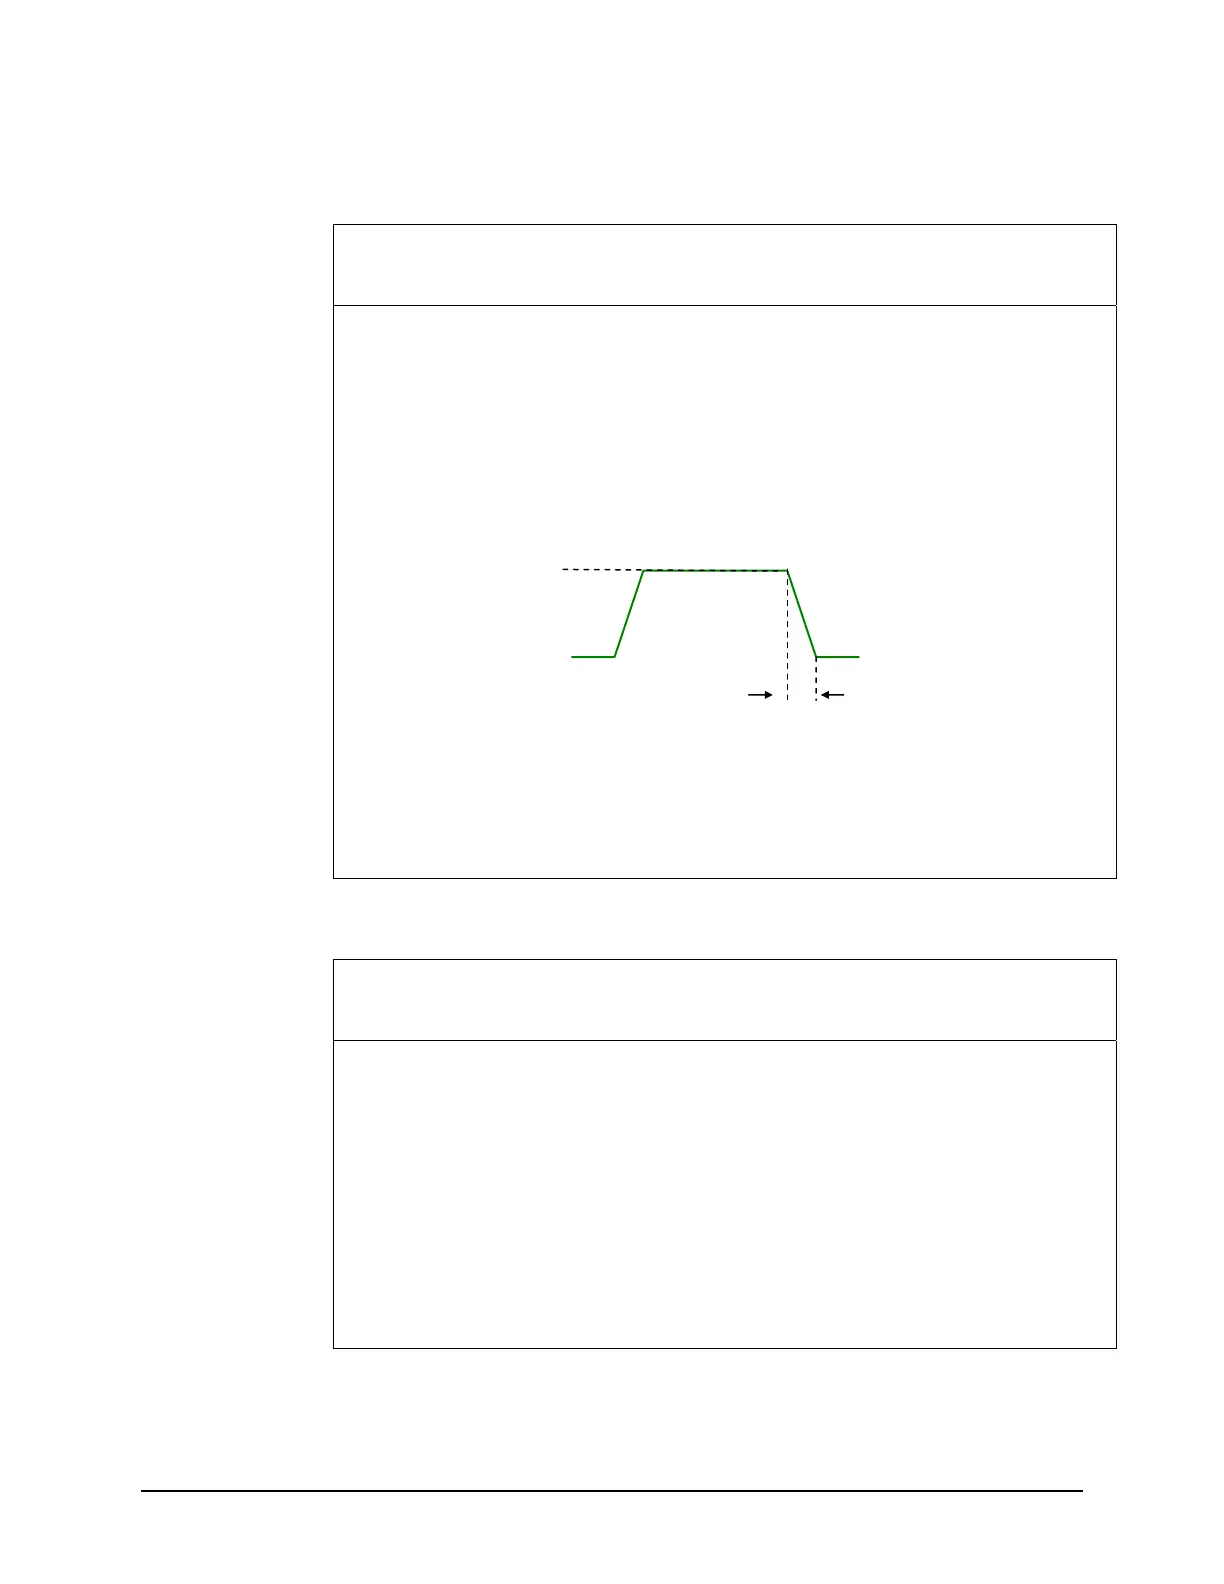
• This parameter is used for limiting the deceleration time in the velocity command mode. The setting represents
the minimum time over which the motor velocity can decelerate by 1000 min
-1
(rpm per minute).
•
Even if the velocity command voltage suddenly changes, the velocity command inside the servo amplifier is
limited so that the acceleration/deceleration is equal to that determined by this time.
Note:
•
This parameter is effective in the velocity control type. Using this when an external closed loop position
controller is used introduces a phase delay that may cause instability and vibration.
•
This parameter determines the rate of deceleration when an over-travel limit is reached.
Velocity Loop Proportional Gain Addition KvpA
Remote Operator Mode:
0
Page:
12
Default Value:
0 Hz
Function:
Alarm
Setting Range:
0 to 255 Hz
Description:
• The actual velocity loop proportional gain is:
Kvp + (KvpA x RSW)
When Gain Switching is active, it will be:
Kvp2 + (KvpA x RSW)
•
RSW: A value set on the rotary switch.
•
Moving the switch on front of the drive to the side labeled “GAIN” enables this.
1000 RPM
0 RPM
Tvde
Artisan Technology Group - Quality Instrumentation ... Guaranteed | (888) 88-SOURCE | www.artisantg.com


 To Next Page