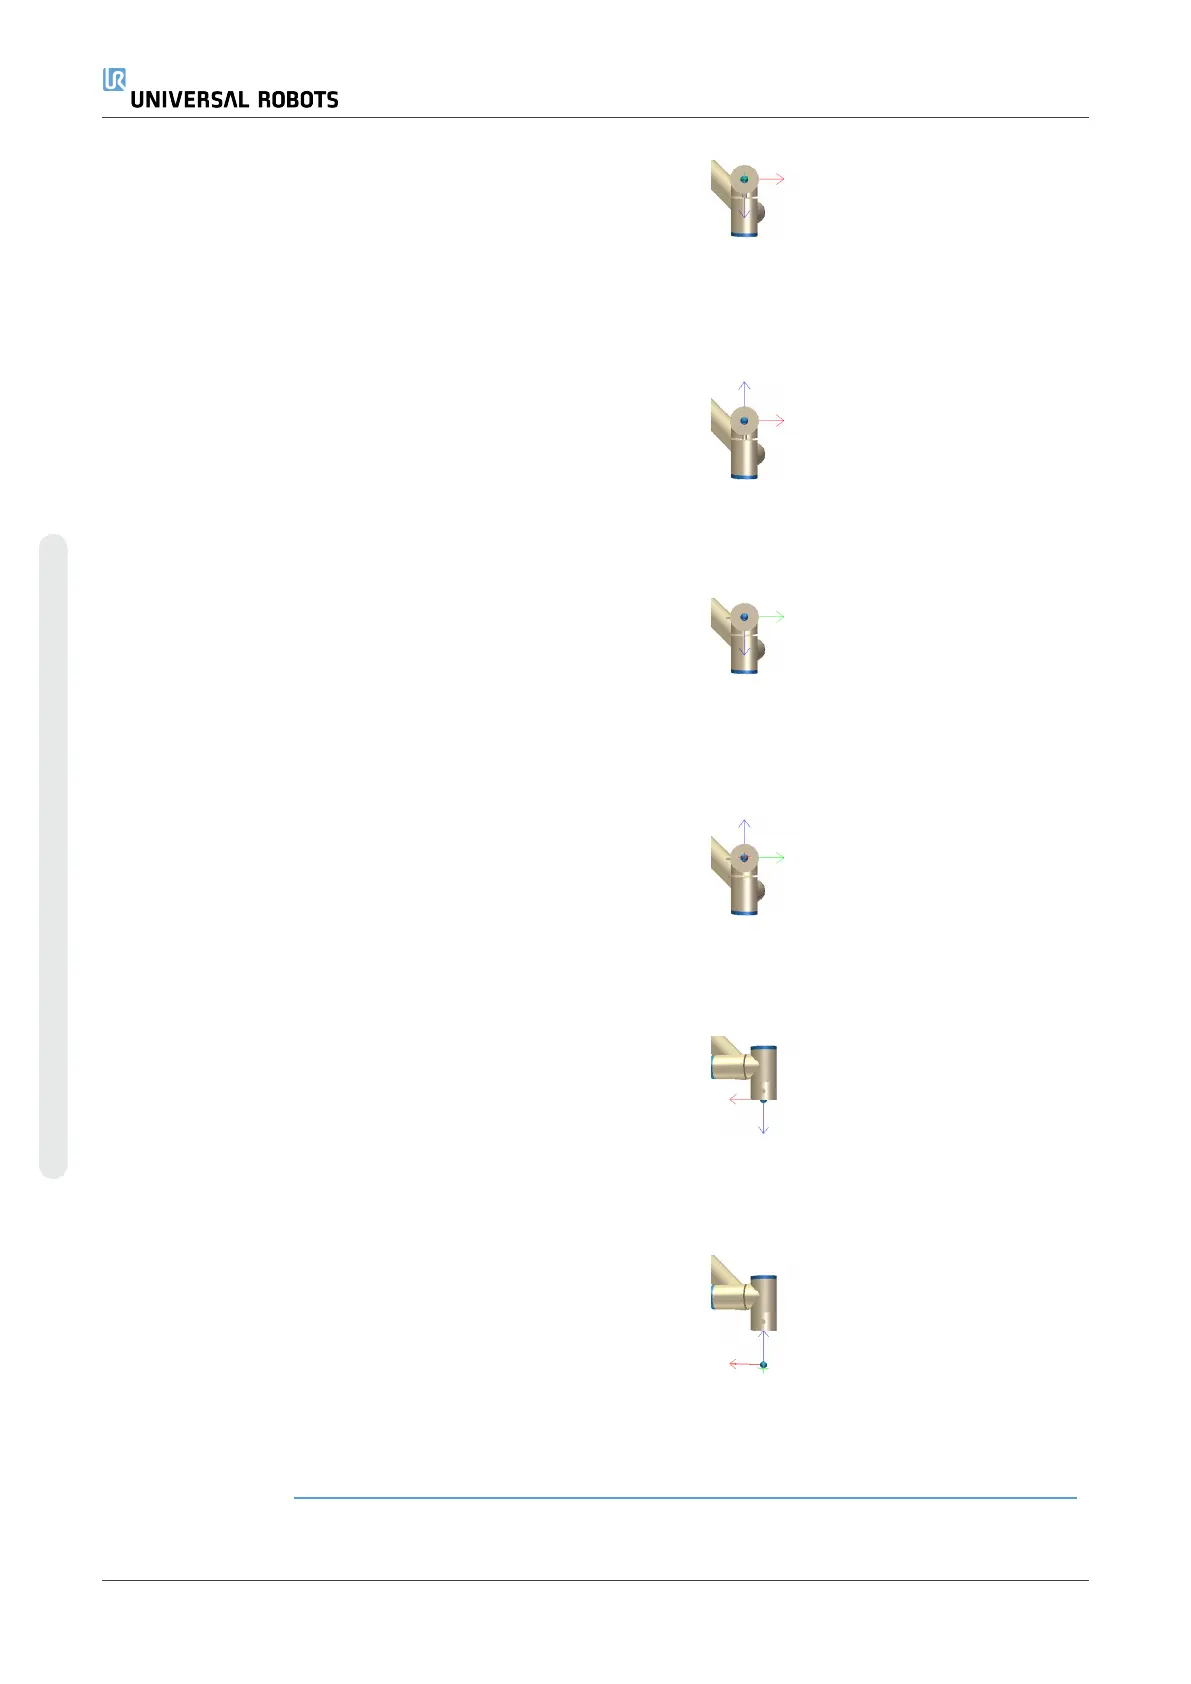
Screwdriving axis parallel to the negative Y
direction of the robot’s tool flange1
Orientation
•
RX: 1.5708
rad
•
RY: 0.0000
rad
•
RZ: 0.0000
rad
Screwdriving axis parallel to the positive Y
direction of the robot’s tool flange2
Orientation
•
RX: -1.5708
rad
•
RY: 0.0000
rad
•
RZ: 0.0000
rad
Screwdriving axis parallel to the positive X
direction of the robot’s tool flange3
Orientation
•
RX: 0.0000
rad
•
RY: 1.5708
rad
•
RZ: 0.0000
rad
Screwdriving axis parallel to the negative X
direction of the robot’s tool flange4
Orientation
•
RX: 0.0000
rad
•
RY: -1.5708
rad
•
RZ: 0.0000
rad
Screwdriving axis parallel to the positive Z
direction of the robot’s tool flange5
Orientation
•
RX: 0.0000
rad
•
RY: 0.0000
rad
•
RZ: 0.0000
rad
Screwdriving axis parallel to the negative Z
direction of the robot’s tool flange6
Orientation
•
RX: 3.1416
rad
•
RY: 0.0000
rad
•
RZ: 0.0000
rad
UR10e 298 User Manual
Copyright © 2009–2024 by UniversalRobotsA/S. All rights reserved.




 To Next Page