NoteAction
To release the brakes, connect the 24 VDC
power supply.
2
Connect to connector R2.MP4:
• + = pin 2
• - = pin 5
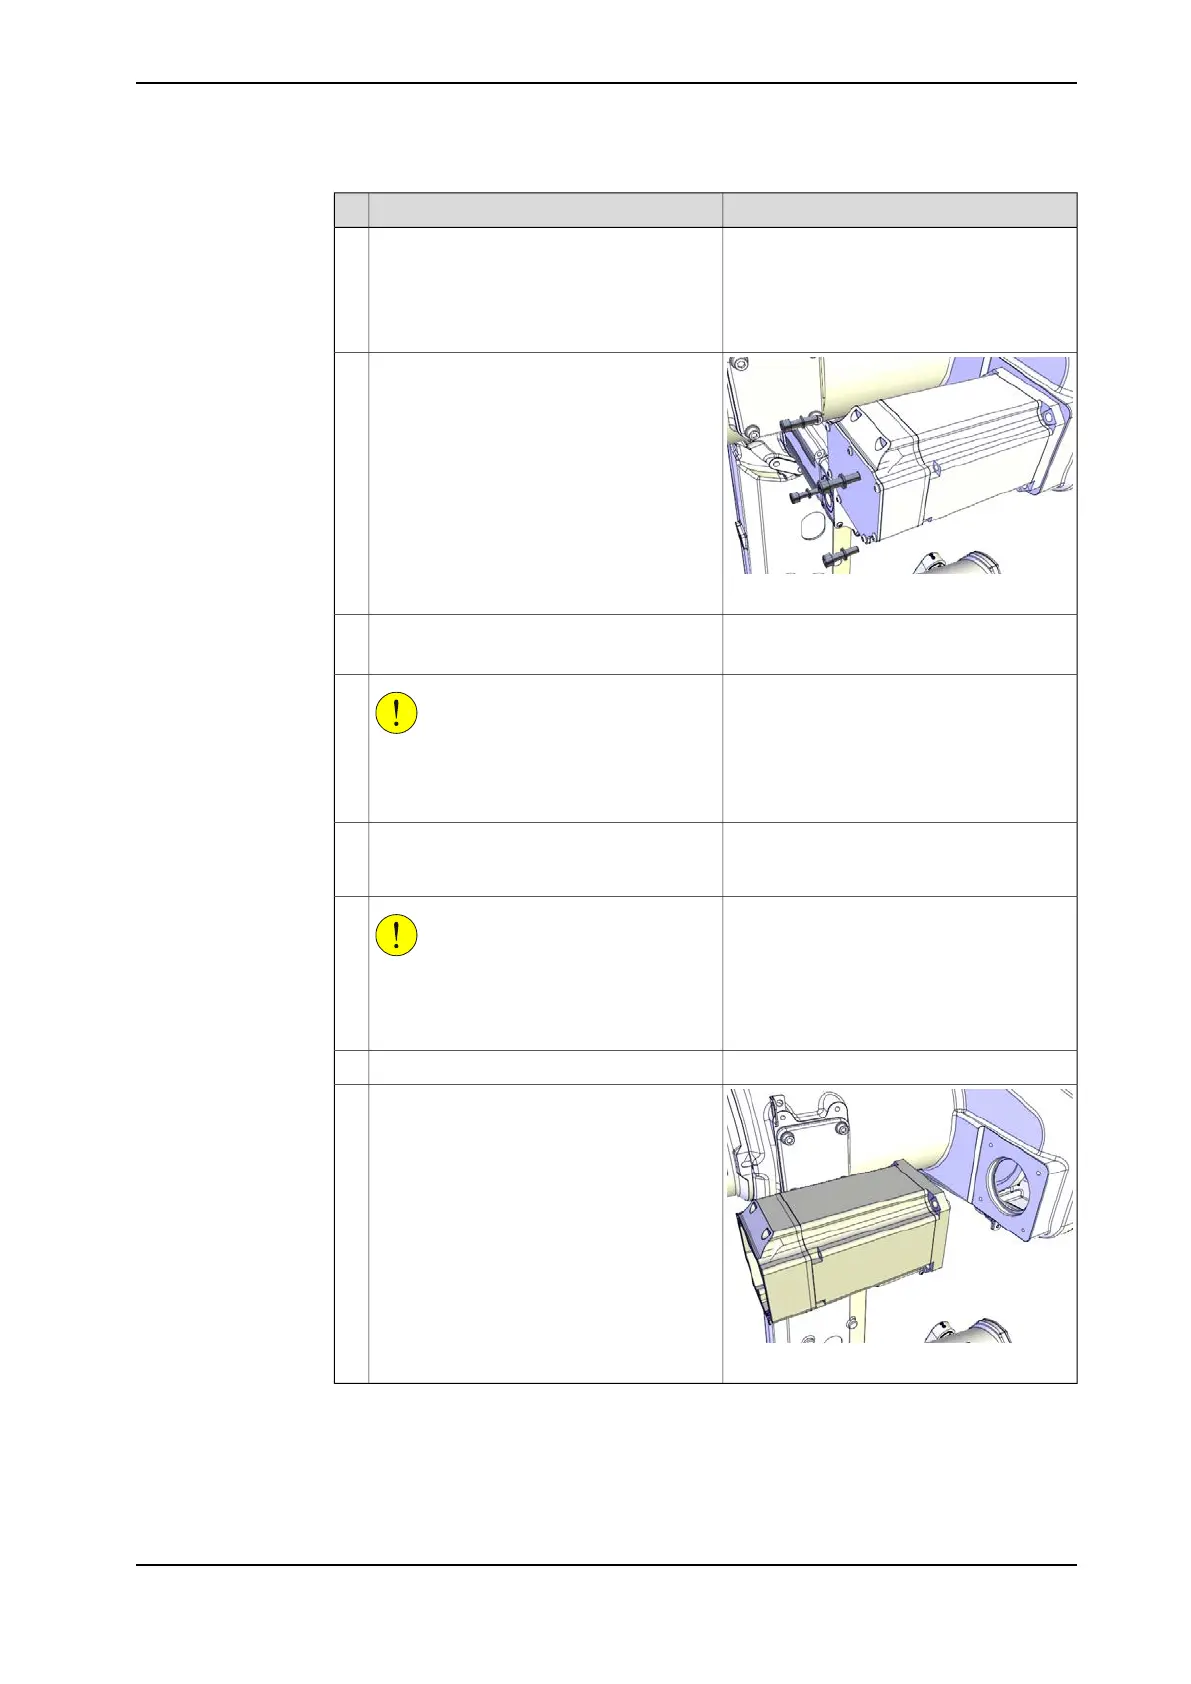
xx1200001137
Unscrew the attachment screws that secure
the motor.
3
Guide pin, M8x150: 3HAC15520-2Apply two guide pins in opposite holes.4
Always use guide pins in pairs.
CAUTION
Whenever parting/mating motor and gear-
box, the gears may be damaged if excess-
ive force is used.
5
Removal tool M12: 3HAC057339-002Press the motor out of position by fitting
the removal tool in the remaining attach-
ment holes for the motor.
6
Always use removal tools in pairs.
CAUTION
The motor weighs 13 kg.
All lifting accessories used must be sized
accordingly.
7
Disconnect the 24 VDC power supply.8
xx1200001138
Remove the motor by carefully lifting it
straight out/straight up (if the upper arm
points upwards).
Make sure the pinion is not damaged.
9
Continues on next page
Product manual - IRB 6790 465
3HAC063331-001 Revision: B
© Copyright 2019 - 2020 ABB. All rights reserved.
4 Repair
4.7.4 Replacing the axis-4 motor
Continued


 To Next Page