Parameters 279
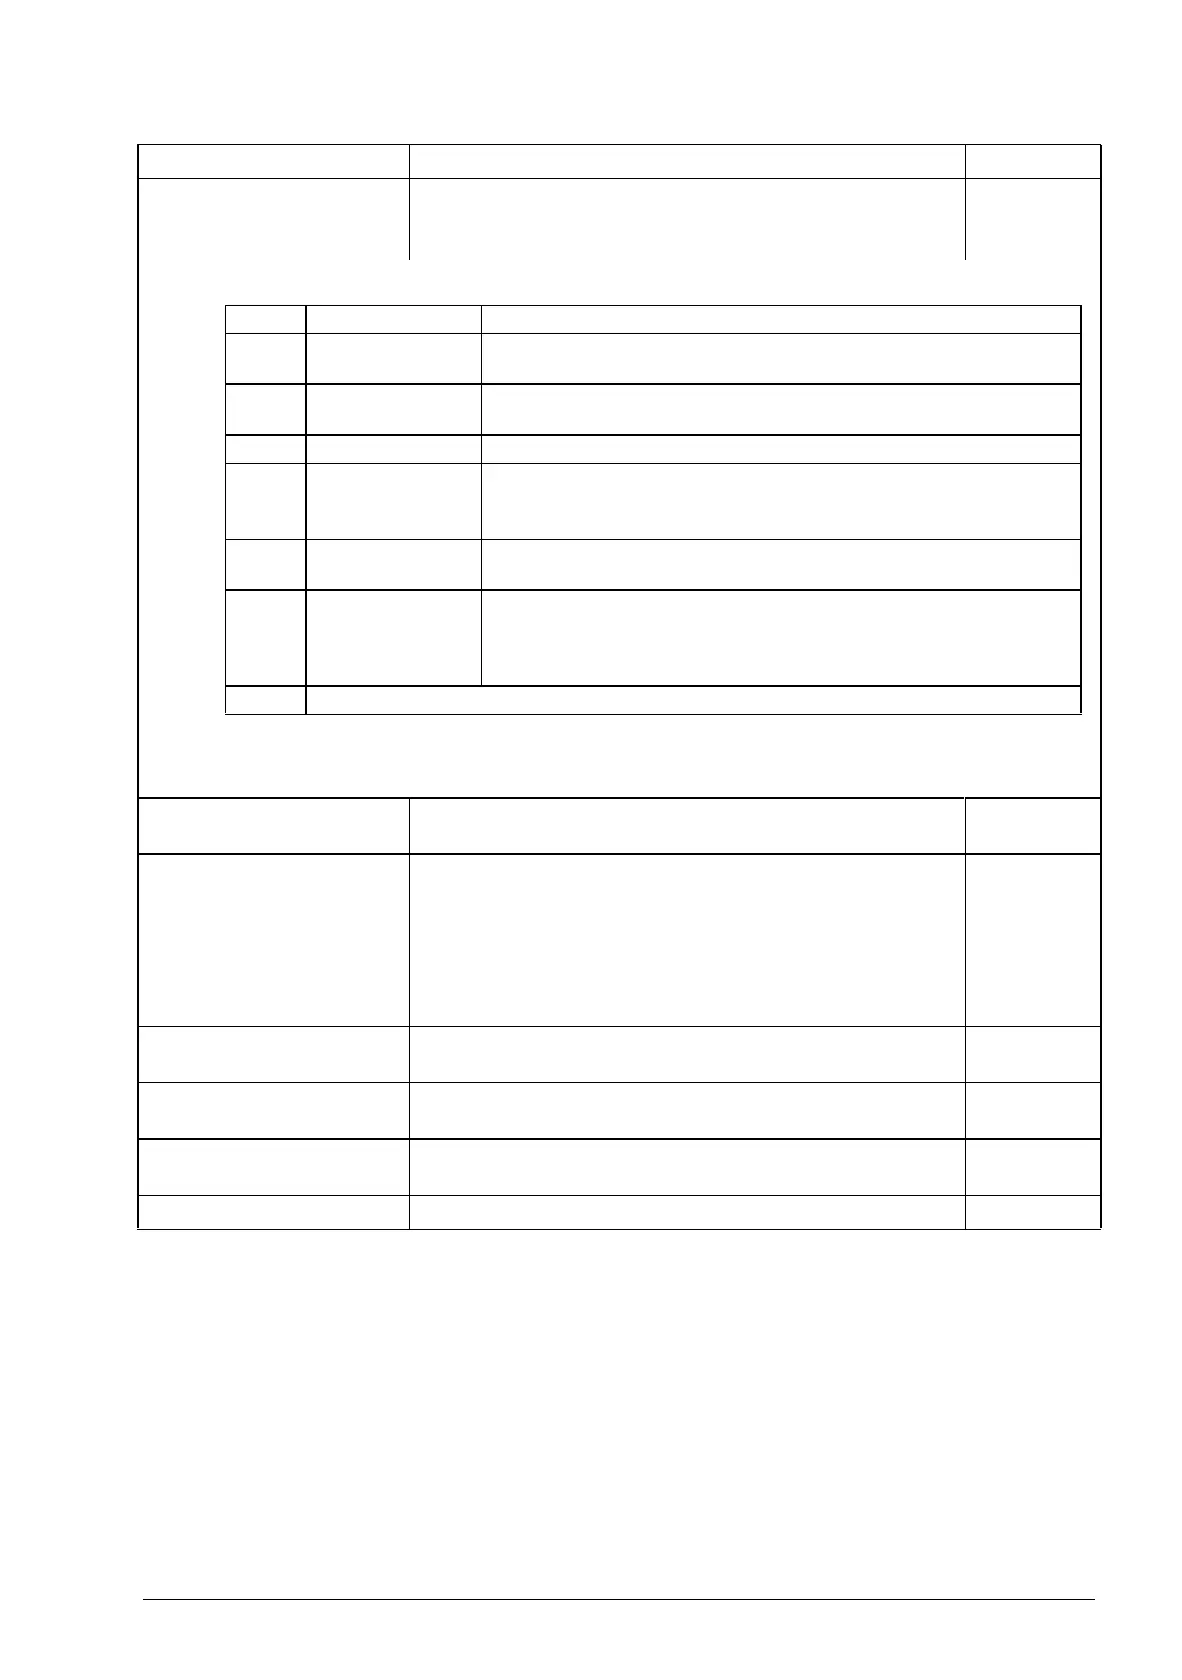
90.35 Pos counter status Status information related to the position counter function.
See section Position counter (page 44).
This parameter is read-only.
-
0000 0000b …
0111 1111b
Position counter status word. 1 = 1
90.41 Motor feedback
selection
Selects the motor speed feedback value used during motor
control.
Note: With a permanent magnet motor, make sure an
autophasing routine (see page 51) is performed using the
selected encoder. If necessary, set parameter 99.13 ID run
requested to Autophasing to request a fresh autophasing
routine.
Estimate
Estimate A calculated speed estimate generated from the Vector core is
used.
0
Encoder 1 Actual speed measured by encoder 1. The encoder is set up
by the parameters in group 92 Encoder 1 configuration.
1
90.42 Motor speed filter
time
Defines a filter time for motor speed feedback used for speed
control (90.01 Motor speed for control).
3 ms
0 … 10000 ms Motor speed filter time. 1 = 1 ms
No. Name/Value Description Def/FbEq16
Bit Name Value
0 Encoder 1
feedback
1 = Encoder 1 selected as load feedback source
2 Internal position
feedback
1 = Internal load position estimate selected as load feedback source
3 Motor feedback 1 = Motor feedback selected as load feedback source
4 Pos counter init
ready
0 = Position counter not initialized, or encoder feedback was lost.
Fresh counter initialization recommended.
1 = Position counter successfully initialized
5 Position counter re-
init disabled
1 = Position counter initialization is being prevented by par. 90.68
6 Position data
inaccurate
1 = Encoder feedback intermittent or lost. (If the drive is running,
estimated position is used whenever encoder feedback is
unavailable. If the drive is in stopped state, position counting will
continue based on encoder data after the connection is restored.)
7…15 Reserved



 To Next Page