Chapter 5: Detailed description of parameters
174
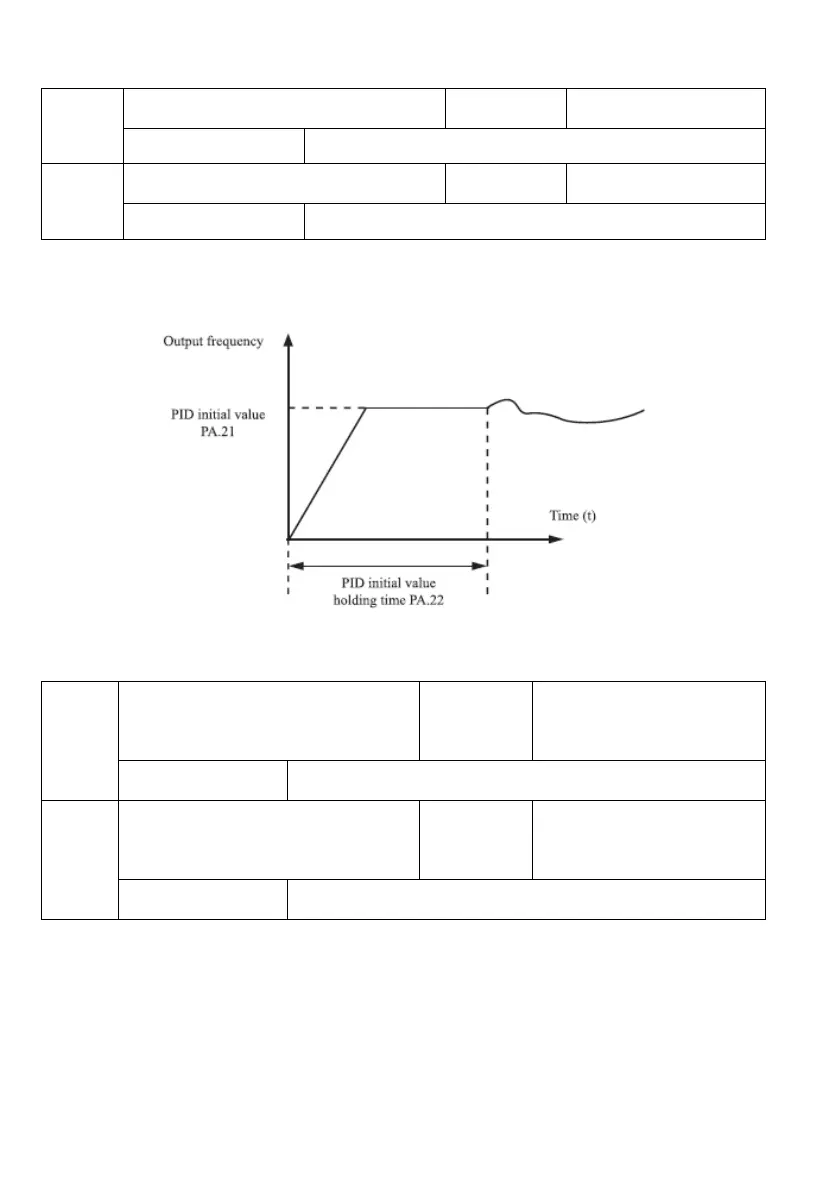
Initial value of delaying PID
When the inverter starts, the PID will start the closed loop algorithm only after the
PID output is stabilized to the PID value (PA.21) and this delay time is set in PA.22.
Figure 4-25 Functions of initial value the PID
Maximum deviation between two
PID outputs in the forward
direction
Maximum deviation between two
PID outputs in the backward
direction
This function serves to limit the variance between two PID outputs (2 ms to the PID
output) which suppress the fast change of the PID output and stabilize the AC motor
operation.
PA.23 and PA.24 correspond to the maximum absolute value of the output deviation in the
forward and reverse directions.


 To Next Page