NoteAction
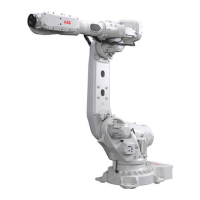
xx2200001521
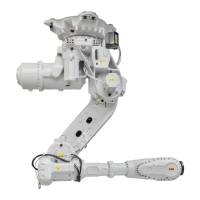
Jog the robot into position:
• Axis 1: no significance
• Axis 2: -45°
• Axis 3: +70°
• Axis 4: calibration position (0°)
• Axis 5: +90°
• Axis 6: no significance.
2
DANGER
Turn off all:
• electric power supply
• hydraulic pressure supply
• air pressure supply
to the robot, before entering the safeguarded
space.
3
Attaching the lifting accessories to the arm system
NoteAction
DANGER
Make sure that all supplies for electrical power,
hydraulic pressure, and air pressure are turned
off.
1
CAUTION
The weight of the complete arm system is 865 kg
All lifting accessories must be sized accordingly.
2
Continues on next page
Product manual - IRB 6710 435
3HAC085695-001 Revision: A
© Copyright 2023 ABB. All rights reserved.
5 Repair
5.8.1 Replacing the axis-1 gearbox
Continued



 To Next Page
