12. Usage
MiR250 User Guide (en) 11/2020 - v.1.3 ©Copyright 2020: Mobile Industrial Robots A/S. 173
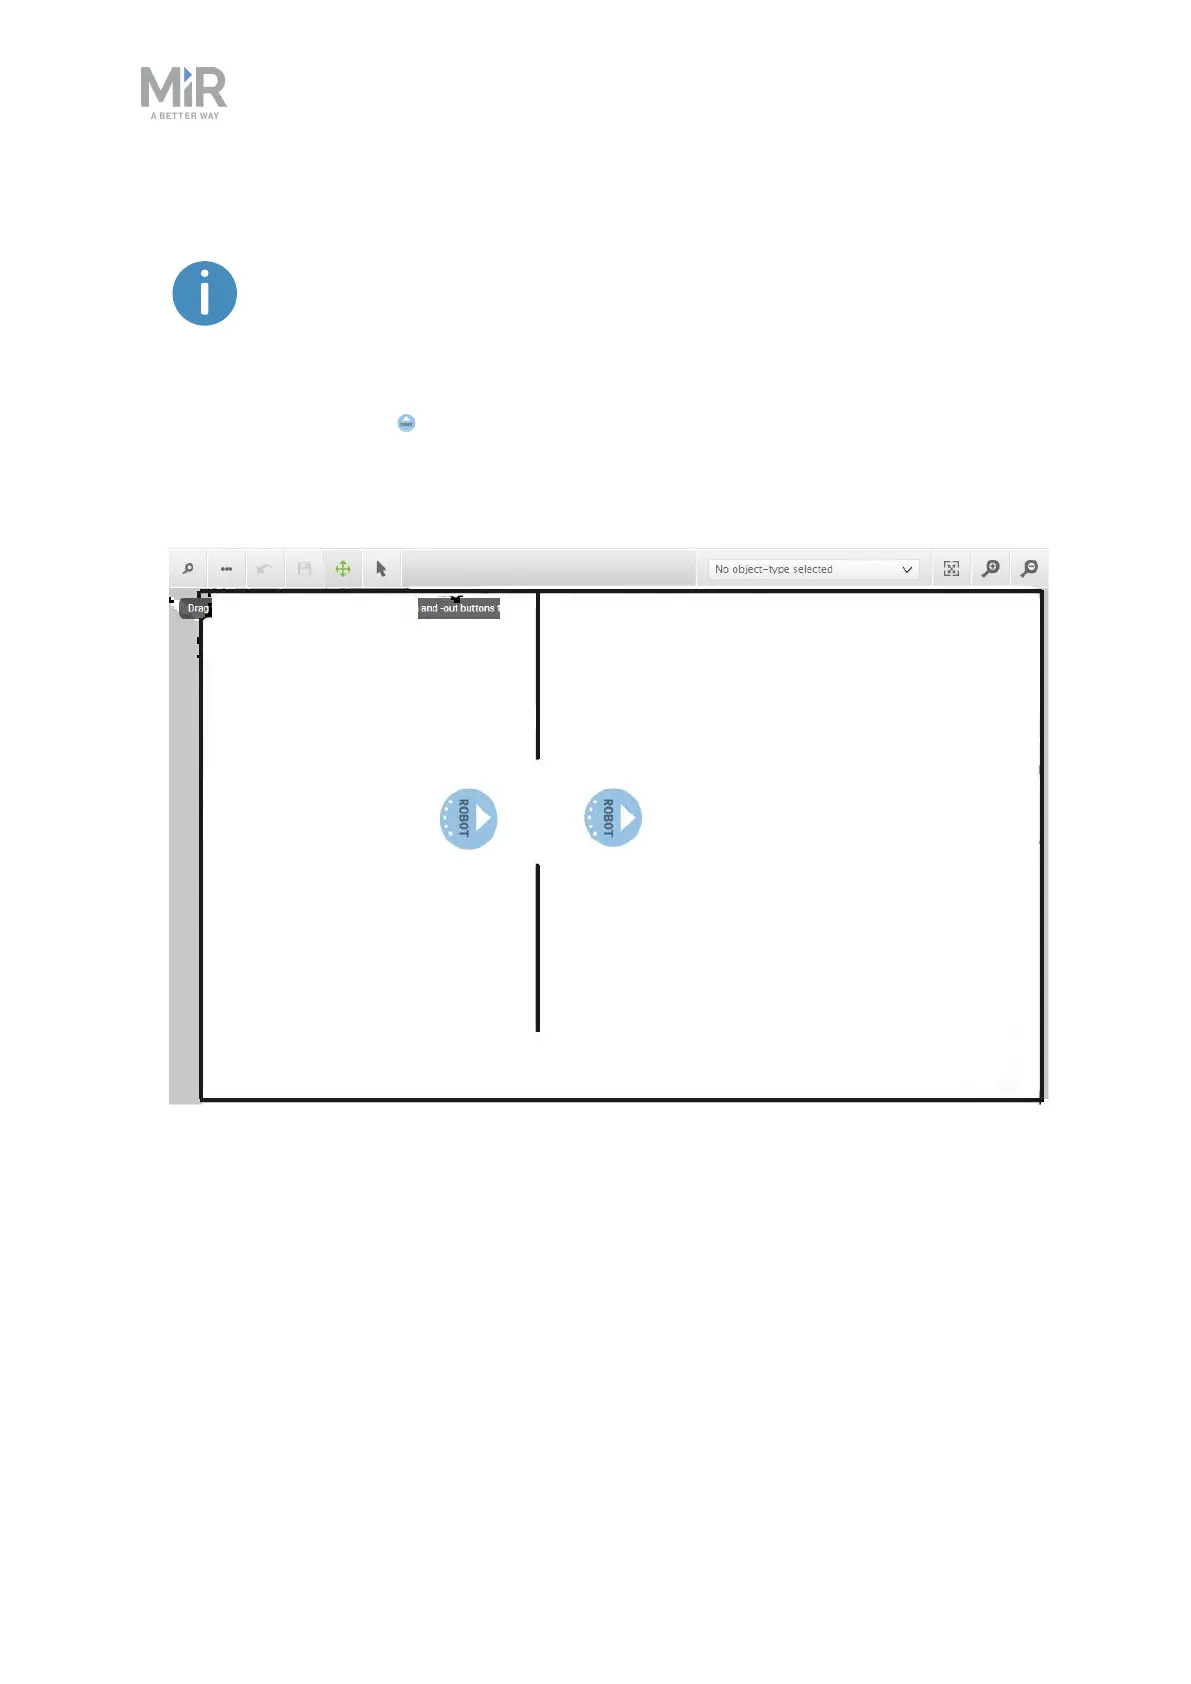
For better localization, draw the walls where the doorway is, and make the
doorway approximately one meter wide in the map by deleting some of the
walls on each side of the doorway. You may need to delete more of the wall
if the robot will not go through the doorway.
• Placed a robot position on each side of the doorway where the first position is named
pos 1 and the second pos 2. The positions must be placed in front of and directly in the
middle of the doorway, and they must point in the same direction (the driving direction of
the robot).
• Made the area around the doorway an operating hazard zone as the robot will be driving
through the doorway with muted Protective fields—see Using operating hazard zones on
page129.


 To Next Page