Technical Manual N5 (CANopen)
6 Operating modes
Other travel commands
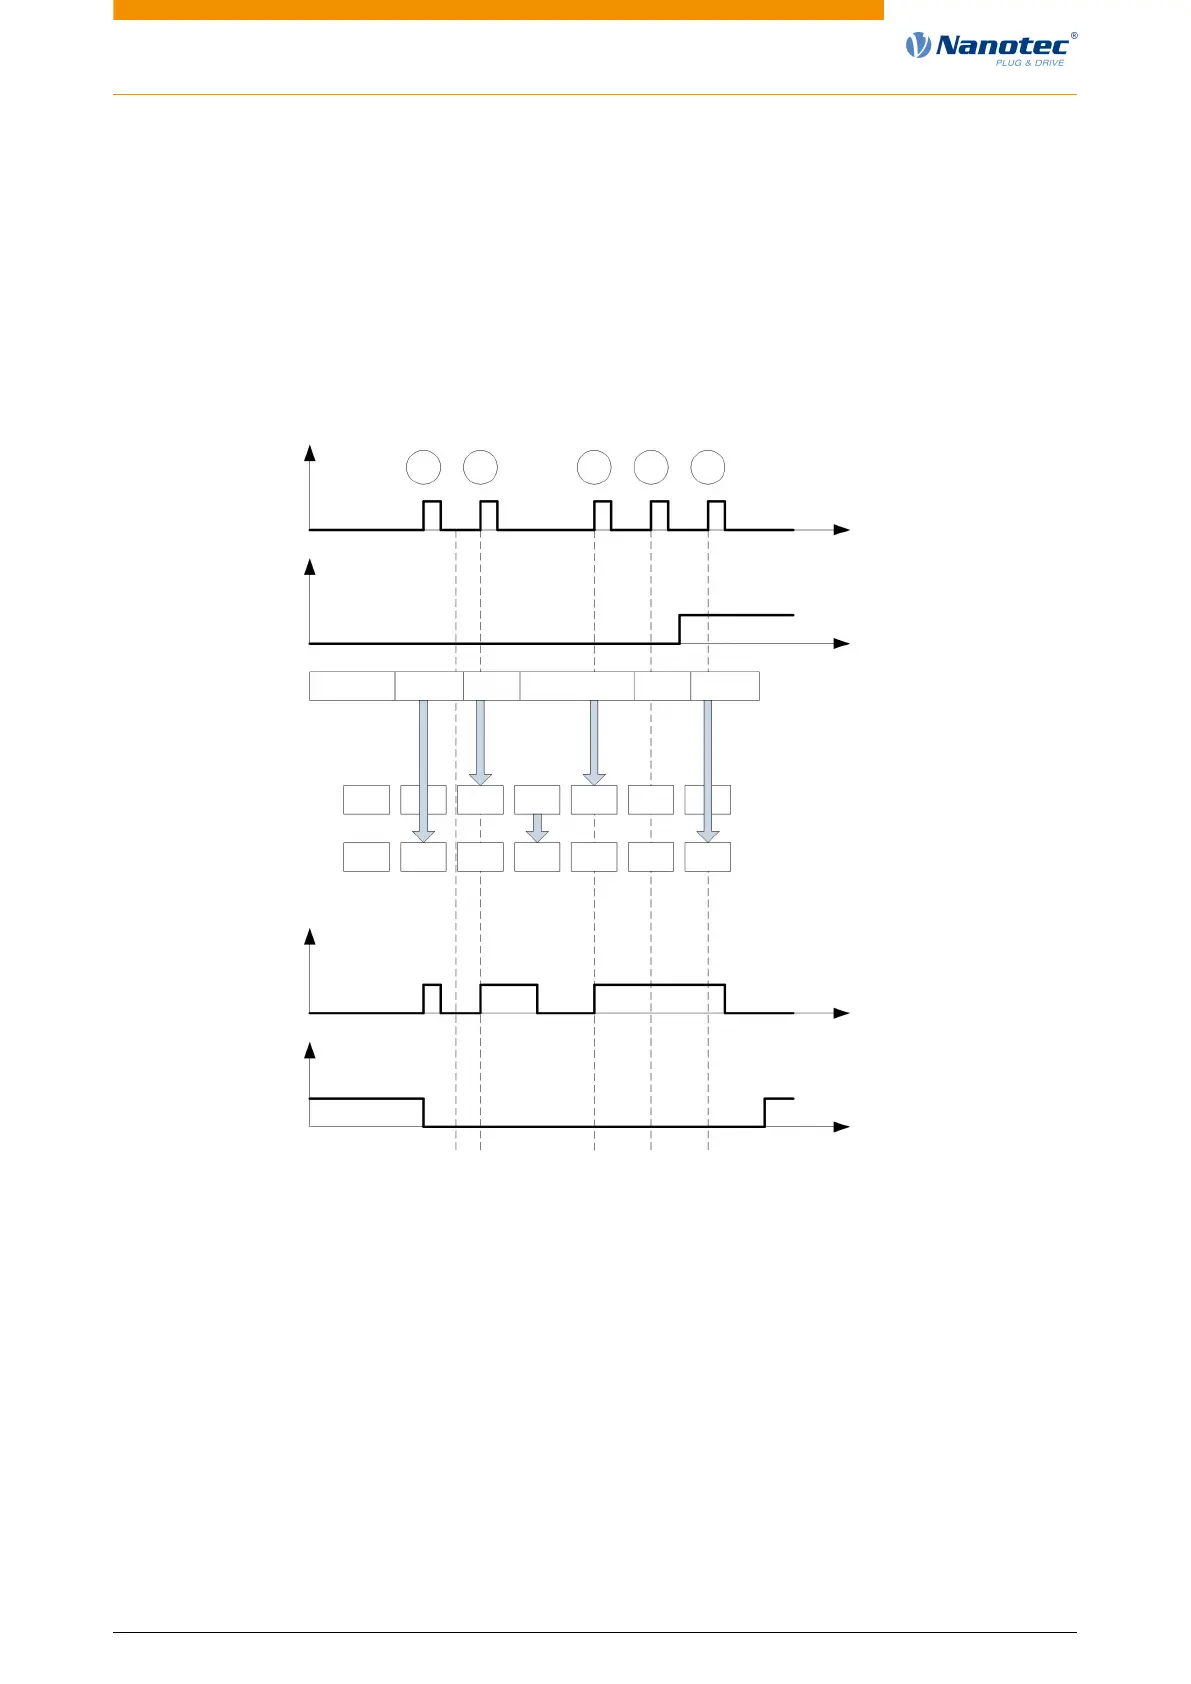
Bit 12 in object 6041
h
(statusword, set-point acknowledge) changes to "0" if another travel command
can be buffered (see time 1 in the following figure). As long as a target position is being moved to, a
second target position can be passed to the controller in preparation. All parameters – such as speed,
acceleration, braking deceleration, etc. – can thereby be reset (time 2). If the buffer is empty, the next
time can be queued up (time 3).
If the buffer is already full, a new set point is ignored (time 4). If bit 5 in object 6040
h
(controlword,
bit: "Change Set-Point Immediately") is set, the controller operates without the buffer; new travel
commands are implemented directly (time 5).
Times
Destination point
confirmation
(6041
h
, Bit 12)
Destination point
Saved
Destination point
Destination point
Apply changes
immediately
(6040
h
, Bit 5)
New
Destination point
(6040
h
, Bit 4)
1 2 3 4 5
A
A A B B B E
B
B --
-
-
C C
C D E
Destination point
reached
(6041
h
, Bit 10)
t
t
t
t
(607A
h
)
Transition procedure for second target position
The following graphic shows the transition procedure for the second target position while moving to the
first target position. In this figure, bit 5 of object 6040
h
(controlword) is set to "1"; the new target value
is, thus, taken over immediately.
Version: 2.0.1 / FIR-v1650 57


 To Next Page