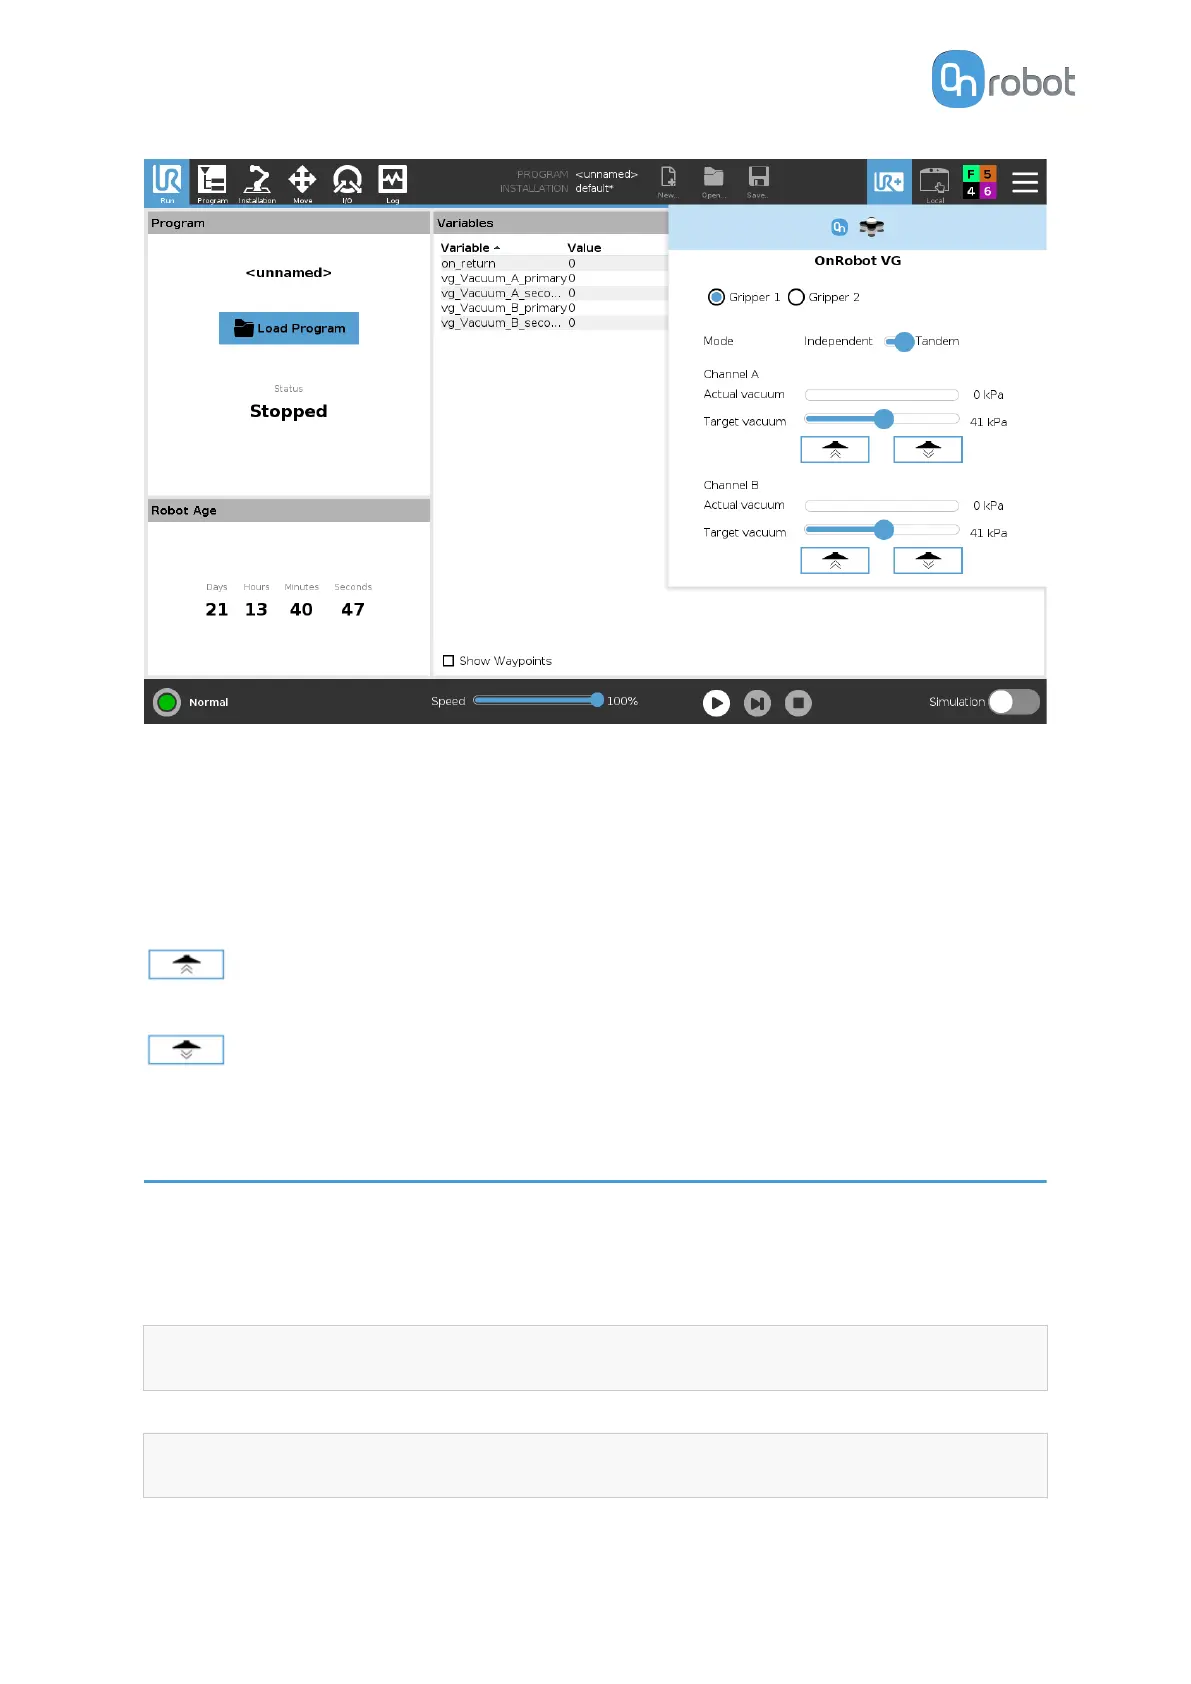
Gripper 1 and Gripper 2: In case of using 2 VG grippers you can select which one performs
the action.
Mode: Select Independent (actuate a channel individually) or Tandem (actuate both channels
together).
Actual vacuum: shows the current vacuum in each channel.
Target vacuum:
defines target vacuum in each channel.
(Grip button): when pressed, the pump will start to generate vacuum at the selected
level on the selected channel(s).
(Release button): when pressed, the test-grip will terminate and release any
workpieces that may be held by the selected channel.
5.3. URScript Commands
URScript commands can be used alongside other scripts.
5.3.1. Eyes
When the OnRobot URCap is enabled, there will be defined script functions for Eyes:
•
get_eyes_workp_pose()
This function will retrieve the pose of the last detected workpiece from the Eye Box.
•
get_eyes_workp_type()
This function will retrieve the type of the last detected workpiece from the Eye Box.
OPERATION
138


 To Next Page