Maintenance 8. Trouble Shooting
RC180 Rev.17
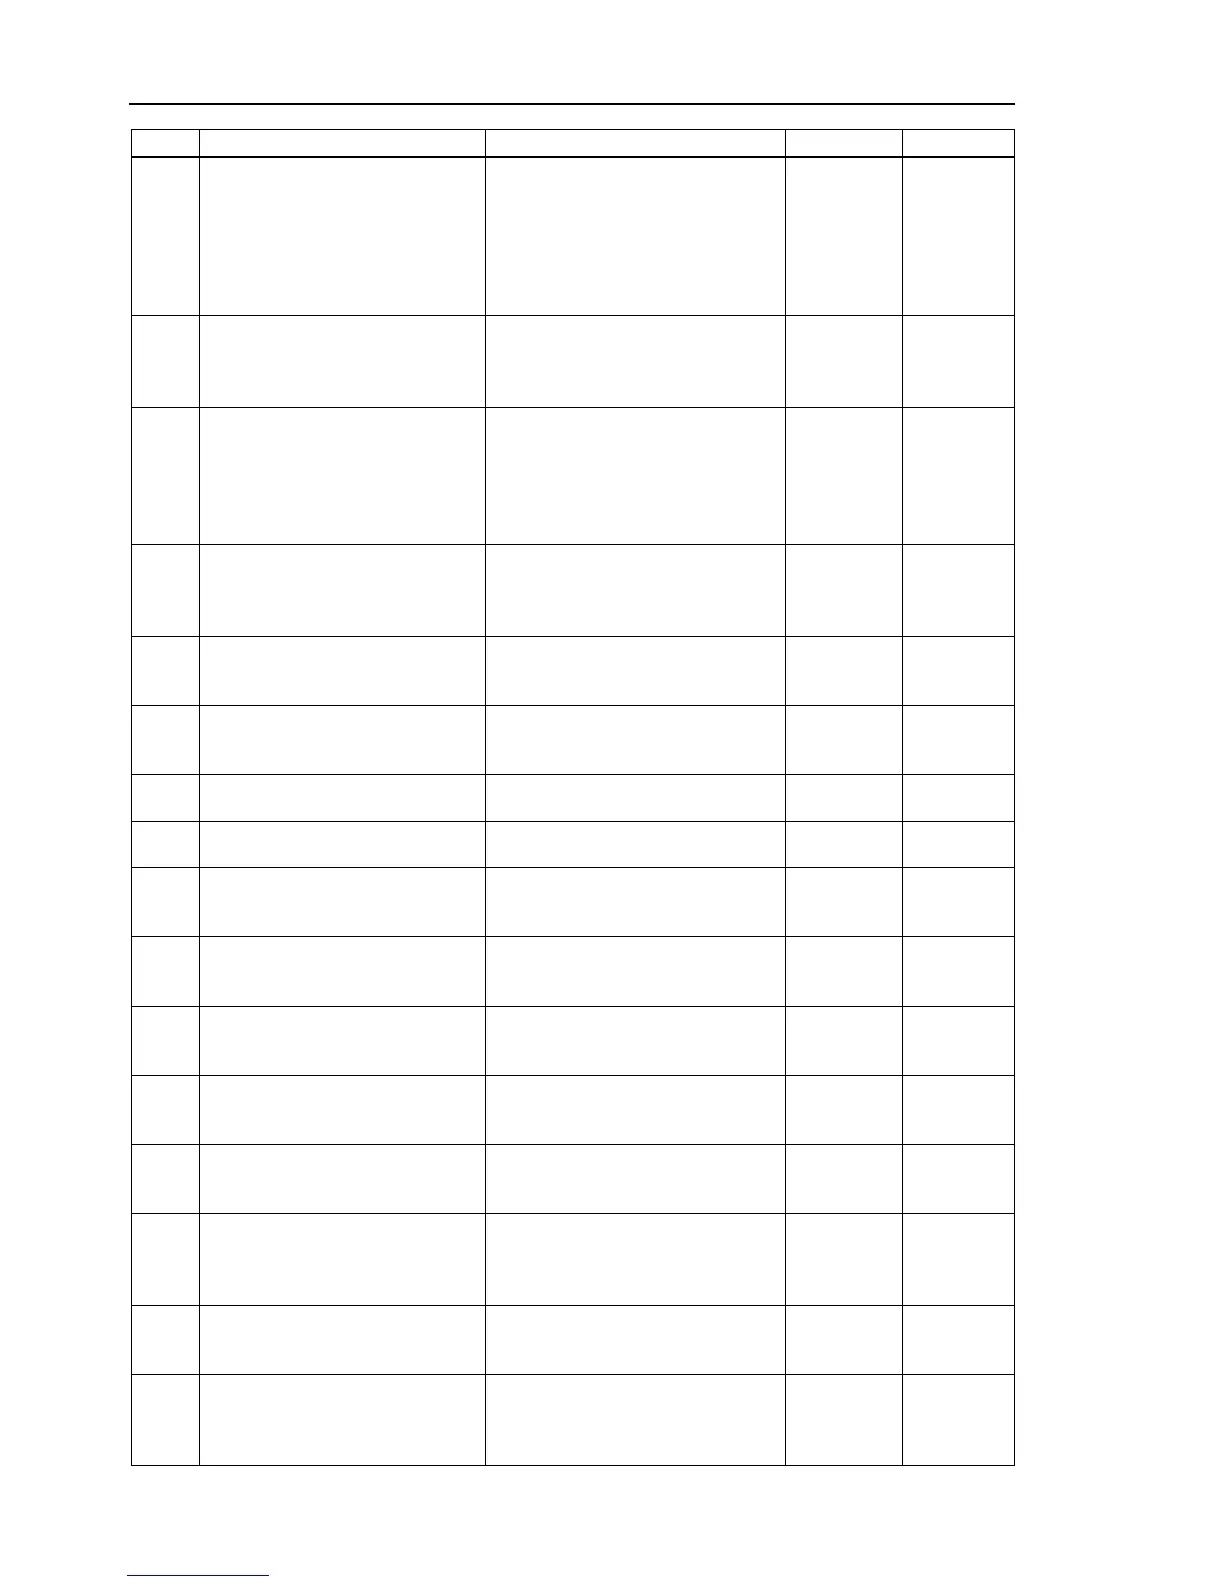
No. Message Remedy Note 1 Note 2
4151
Redundant input signal failure of the
safeguard.
The input status of the redundant
emergency stop input continuously
differs for more than two seconds.
Check whether no disconnection, earth
fault, or short-circuit of the emergency
stop input signal exits. Then reboot the
Relay welding error of the main
circuit.
A relay welding error was detected due
to power system over current.
Replace the controller.
Redundant input signal failure of the
The input status of the redundant enable
signal differs continuously for more than
two seconds.
Check the TP connector connection.
Replace the TP.
4154
Temperature of regeneration resistor
was higher than the specified
Robot’s Duty is too high. Lengthen the
waiting time or reduce the Accel value.
If the error occurs although Duty was
lowered, replace the DPB.
Manipulator initialization failure.
Specified manipulator was is not
found.
Configure the manipulator.
4181
Manipulator initialization failure.
Specified manipulator was in use by
another task.
configured since it is already configured.
4182
Manipulator initialization failure.
Manipulator name is too long.
Shorten the manipulator name.
4183
Manipulator initialization failure.
Manipulator data version error.
Reconfigure the manipulator.
4187
Manipulator initialization failure.
Communication error with the
module : VSRCMNPK.
Reboot the controller.
Initialize the controller firmware.
4188
Manipulator initialization failure. Joint
angle interference matrix is invalid.
Reboot the controller.
Initialize the controller firmware.
Manipulator initialization failure.
Communication error with the
module : VSRCMC.
Initialize the controller firmware.
Manipulator initialization failure.
logical pulse transformation
matrix is invalid.
Initialize the controller firmware.
Manipulator initialization failure.
Communication error with the servo
module.
Reboot the controller.
Initialize the controller firmware.
4210
RAS circuit detected the servo system
malfunction. Reboot the controller.
Measure the noise. Replace the
controller.
Reboot the controller, take the measure
against noise, or replace the DMB.
4211
Servo CPU internal RAM failure.
Reboot the controller. Measure the
Reboot the controller, take the measure
against noise, or replace the DMB.
4212
RAM for the main and servo CPU
communication failure. Reboot the
controller. Measure the noise. Replace
Reboot the controller, take the measure
against noise, or replace the DMB.


 To Next Page