Maintenance 8. Trouble Shooting
RC180 Rev.17
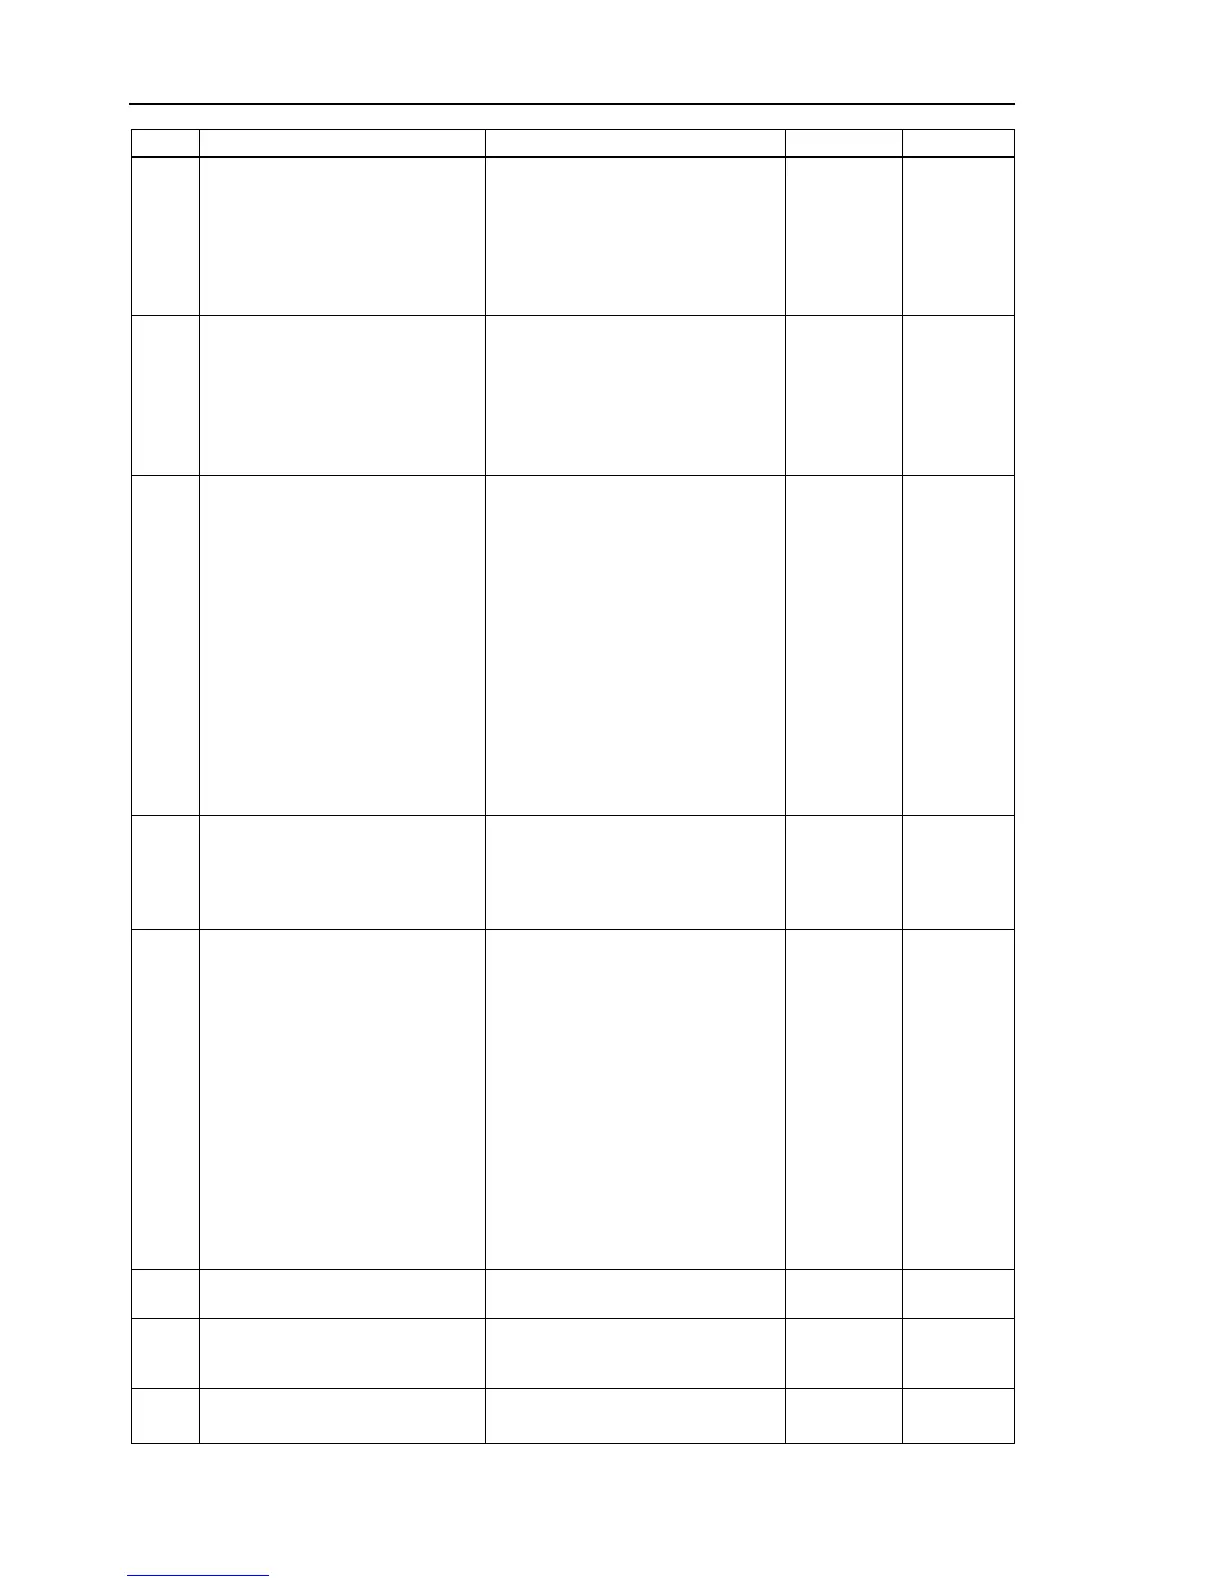
No. Message Remedy Note 1 Note 2
4233
Servo real time status failure.
Communication error with the servo
CPU.
A communication error was detected in
the controller.
Check the short-
circuit and improper
connection of the peripheral equipment
Expansion I/O connectors)
Irregular motion control interruption
was detected.
Interruption duplicate.
A
interruption error was detected in the
controller.
Check the short-
circuit and improper
connection of the peripheral equipment
Expansion I/O connectors)
Over speed during low power mode
The robot over speed was detected
Check the robot mechanism.
(Smoothness, backlash, non-smooth
motion, loose belt tension, brake)
Check whether the robot does not
interfere with peripheral equipment.
(Collision, contact)
Replace the motor driver.
Replace the motor. (Motor and encoder
failure)
Check the short-
circuit and improper
connection of the peripheral equipment
I/O, and
Expansion I/O connectors)
4242
Improper acceleration reference was
generated.
You attempted to operate the robot with
the acceleration reference exceeding the
specified value.
For a CP motion, decrease the AccelS
4243
Improper speed reference is generated
in the high power mode.
The robot over
Check the robot mechanism.
(Smoothness, backlash, non-smooth
motion, loose belt tension, brake)
Check whether the robot does not
interfere with peripheral equipment.
(Collision, contact)
Replace the motor driver.
Replace the motor. (Motor and encoder
failure)
Check the short-
circuit and improper
connection of the peripheral equipment
I/O, and
Expansion I/O connectors)
4250
Arm reached the limit of motion range
Check whether a CP motion trajectory is
4251
Arm reached the limit of XY motion
range specified by XYLim during the
operation.
Check the XYLim setting.
4252
Coordinate conversion error occurred
during the operation.
Check whether a CP motion trajectory is
within the motion range.


 To Next Page