EasyManua.ls Logo

Astraada SRV-64 - Page 107

Astraada SRV-64
325 pages
Print Icon
To Next Page IconTo Next Page
To Previous Page IconTo Previous Page
Loading...
AS64 series AC servo drive Function codes
-101-
P0.61
Torque command
direction setting
Setting range
Defaul
t
Unit
Applicable
mode
0–1
0
-
T
This parameter specifies the method for specifying the direction in a torque command.
Setting
Meaning
[0]
The input sign of the torque command specifies the direction.
For example, Torque command input [+] indicates forward,
while [-] indicates reverse.
1
The torque command sign [0x00F] of the digital input function
is used to specify the direction.
1: forward
0: reverse
Note: 0x00F is valid when the input is a low electrical level, while 0x10F is valid when the input is
a high electrical level.
P0.61
Data size
16bit
Data format
DEC
Modbus address
1122, 1123
CANopen address
0x203D, 0x00
P0.62
Gain of AI 2
Setting range
Defaul
t
Unit
Applicable
mode
0–2000
100
[P3.27 unit]/V
P
S
T
This parameter specifies the gain of analog input 2. The gain unit is associated with P3.27.
Note:
Analog input 2 indicates the signal input from the analog speed/speed limit terminals (AD2 and
GND, corresponding to pin 20 and pin 19) of the CN1 plug.
Application example:
1. The function of analog input 2 is torque command.
2. The voltage of analog input 2 corresponds to the conversion gain of the motor torque
command.
3. This parameter is valid only when P0.60 is 1.
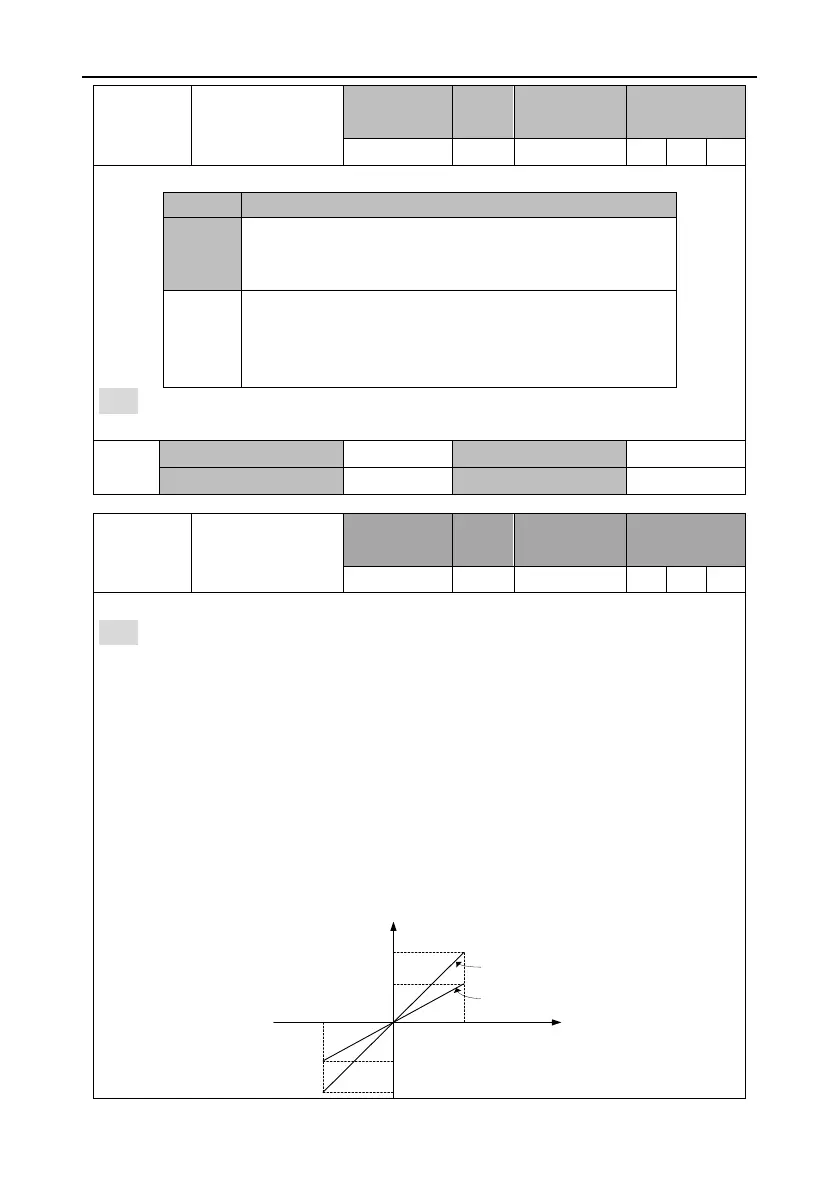
4. The relationship between the voltage of analog input 2 and torque command is as follows:
The torque corresponding to every 1V voltage is 10% of the rated torque by default.
Actual torque command = Analog input voltage x P0.62
-10.0V
100
-100
AD2 input voltage(V)
P
0.62=10%/V
P
0.62
=5%/V
50
-50
10.0V
Rated torque(%)

Table of Contents