Maintenance 8. Trouble Shooting
RC180 Rev.17
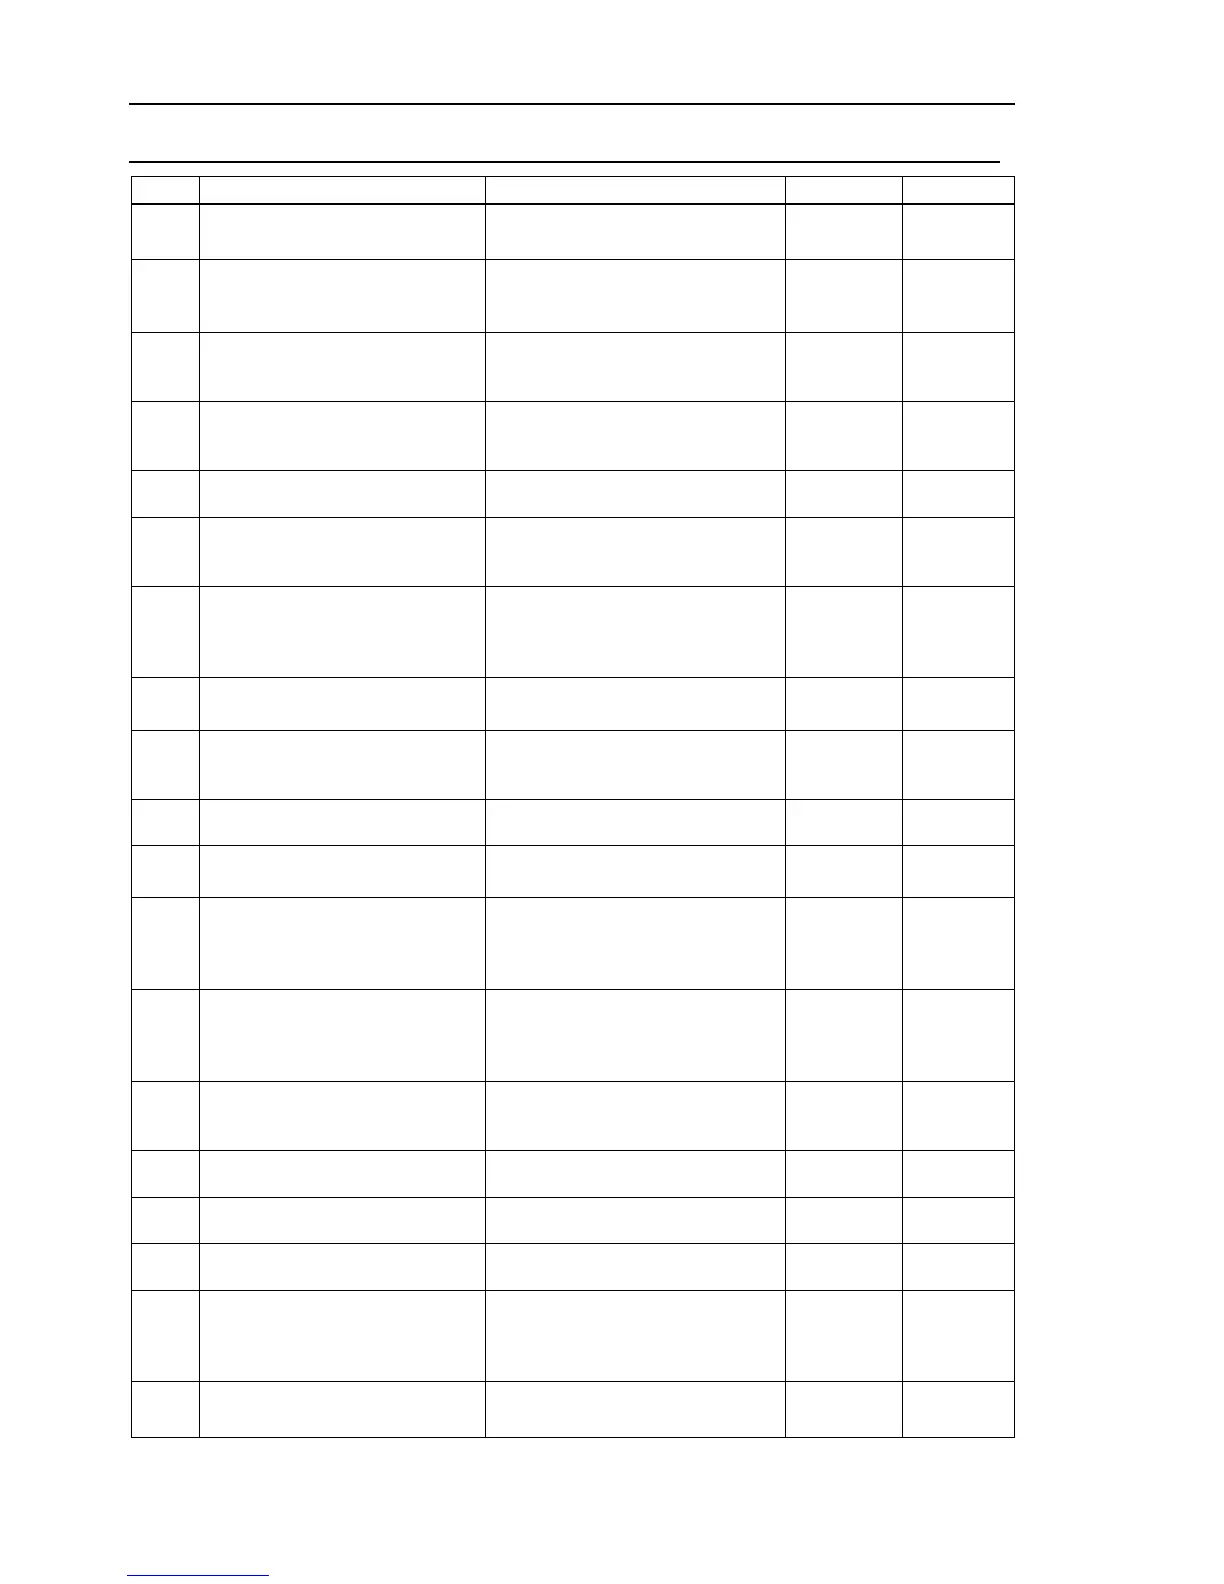
Arm reached the limit of motion
Check the point to move, current point,
Specified value is out of allowable
range.
Review the setting parameters.
The parameter
Motion device driver failure.
Communication error within the
motion control module.
Initialize the controller firmware.
4004
Motion device driver failure.
Event waiting error within the motion
Reboot the controller.
Initialize the controller firmware.
Current point position is above the
specified LimZ value.
Lower the Z axis. Increase the
specified LimZ value.
Target point position is above the
Lower the Z coordinate position of the
target point. Increase the specified
LimZ value.
Coordinates conversion error.
The end/mid point is out of the motion
area. Jogging to the out of the motion
area.
Check whether the coordinate out of the
motion range is not specified.
4008
Current point position or specified
LimZ value is out of motion range.
Change the specified LimZ value.
4009
Motion device driver failure. Timeout
error within motion control module.
Reboot the controller.
Initialize the controller firmware.
Specified Local coordinate was not
defined.
Define the Local coordinate system. Local number
4011
Arm reached the limit of XY motion
range specified by XYLim statement.
Check the area limited by the XYLim
statement.
4013
Motion control module internal
calculation error.
Calculation of the timing of Arch motion
failed. Perform either of the following:
- Check and modify Arch parameter
SFree statement was attempted for
Due to robot mechanistic limitation,
setting some joint(s) to servo free status
is prohibited. Check the robot
specifications.
Communication error within the
Initialize the controller firmware.
Point positions used to define the
Local are too close.
Set the distance between points more
than 1μm.
Point coordinate data used to define
the Local is invalid.
Match the coordinate data for the points
to be specified.
4023
Cannot execute when the motor is in
Turn the motor power ON and then
execute.
Cannot complete the arm positioning
using the current Fine specification.
Check whether the robot does not
generate vibration or all parts and screws
are secured firmly. Increase
4025
Cannot execute a motion command
during emergency stop condition.
Clear the emergency stop condition and
execute the motion command.


 To Next Page